Engineering Background
Currently Ongoing: Autonomous Dog Waste Cleaning Robot
Elite Robotics & Mechatronics Studio

Robots.
Developed.
Deployed.

Struggling to validate your concept?
We provide prototyping support to early stage startups and inventors
Helping team avoid costly mistakes in their early R&D stages.

Vetted & Trusted Credentials
Toptal Vetted Top 3%
Upwork Top Rated Plus
Top 20 AUS University
CAD & DFM
PCB & CIRCUITS
ROS2 AUTONOMY
50+ porjects compleated
Toptal Vetted Top 3%
100% Job Success Score
5 TURNKEY PROJECTS
Our Domain Expertise

WHAT WE DEVELOP

We provide comprehensive physical and digital mechatronics services, covering the full spectrum of automation.

01 / ROBOTICS

Concept Development and Idea Validation

Turning ideas into actionable goals through brainstorming, requirement analysis, and validation.

02 / HARDWARE

Design Exploration

Exploring and validating early concepts using hand sketches and detailed engineering drawings.

03 / SOFTWARE

3D Modeling and Simulation

Building 3D models and simulating designs to validate functionality and performance.

04 / INTEGRATION

Hardware Design and Prototyping

Designing electronics and developing prototypes to validate hardware feasibility and integration.

05 / AGRI

Manufacturing and Fabrication

Refining and validating designs for efficient manufacturing and precise 3D fabrication.

06 / CONSULT

Software and Visualization

Simulating robot behavior and visualizing concepts for software validation and presentation.

Featured Case Studies

FEATURED PROJECTS

Exploring our three core dynamic mechatronics assemblies, exactly from blueprint to physical field deploy.

MILITARY ROBOTICS

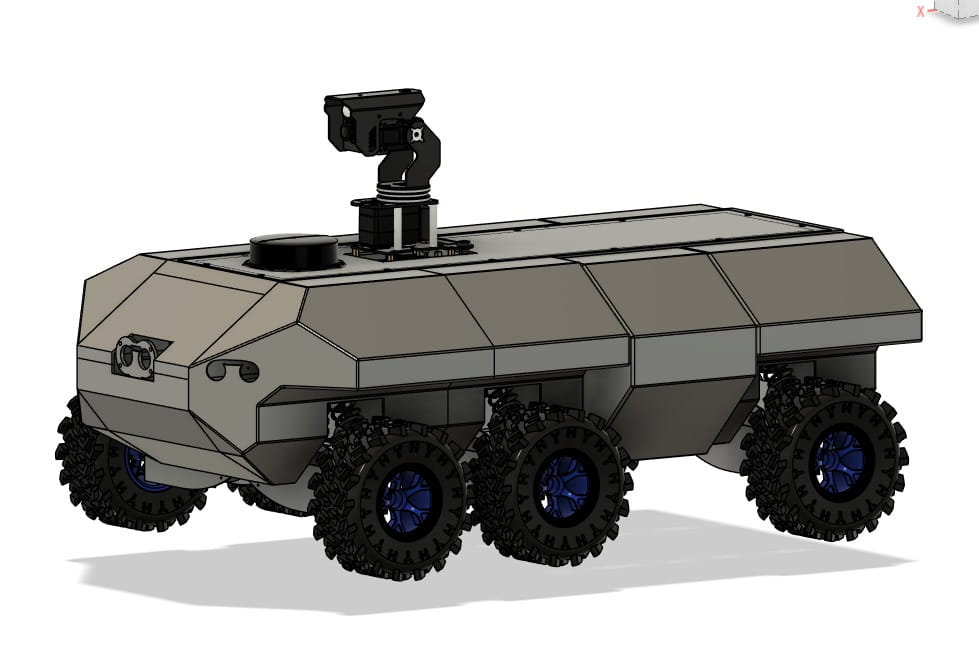
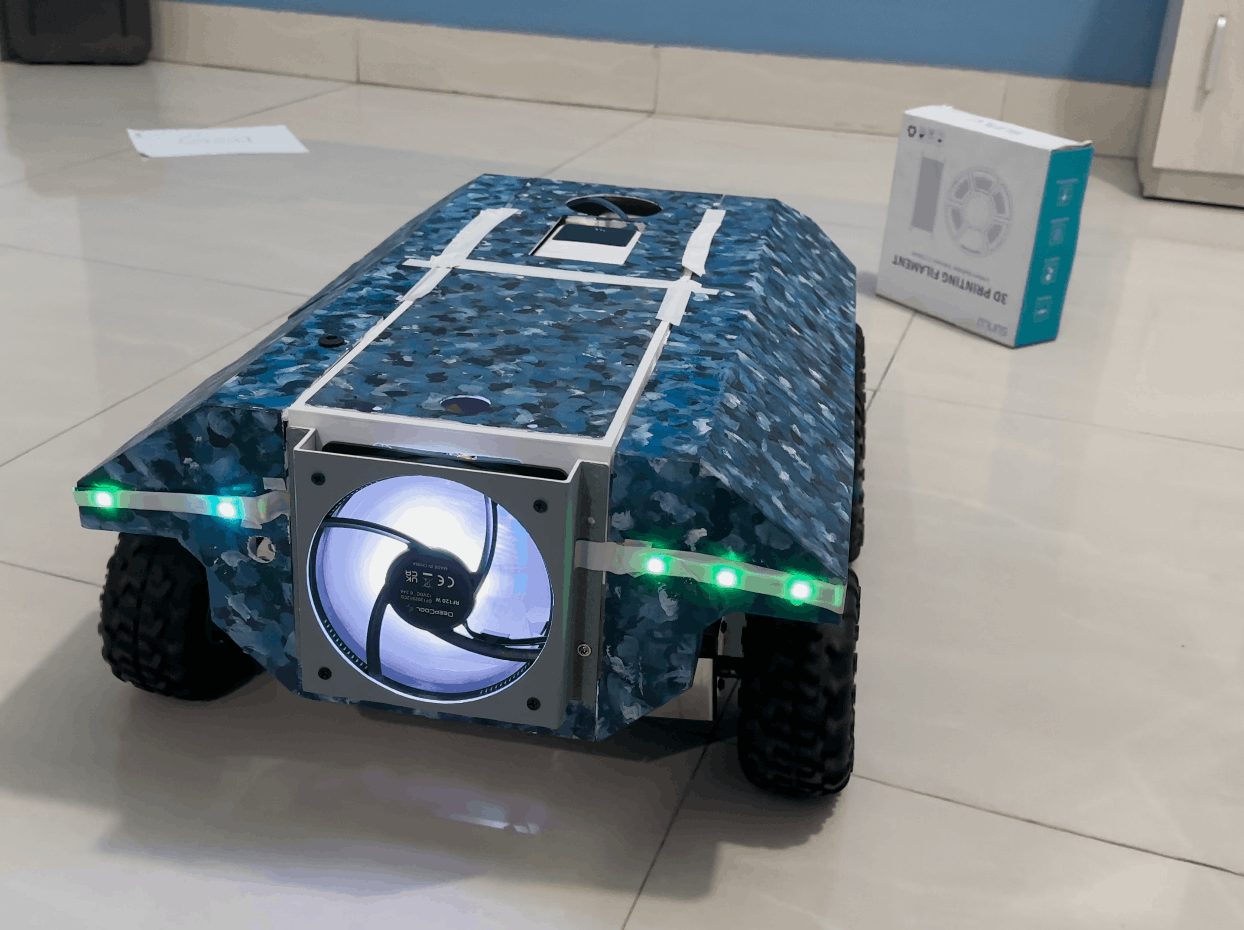
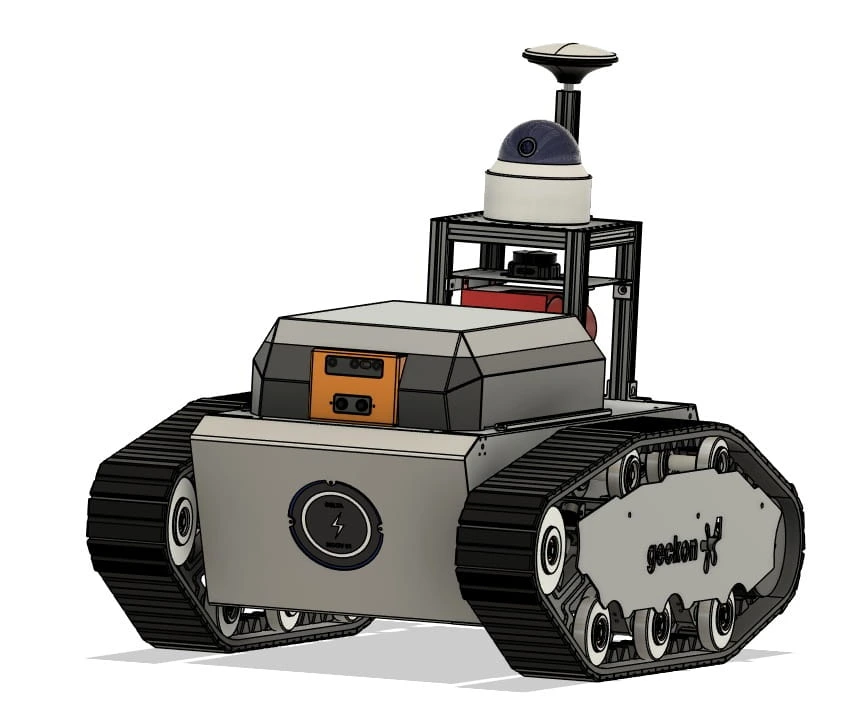
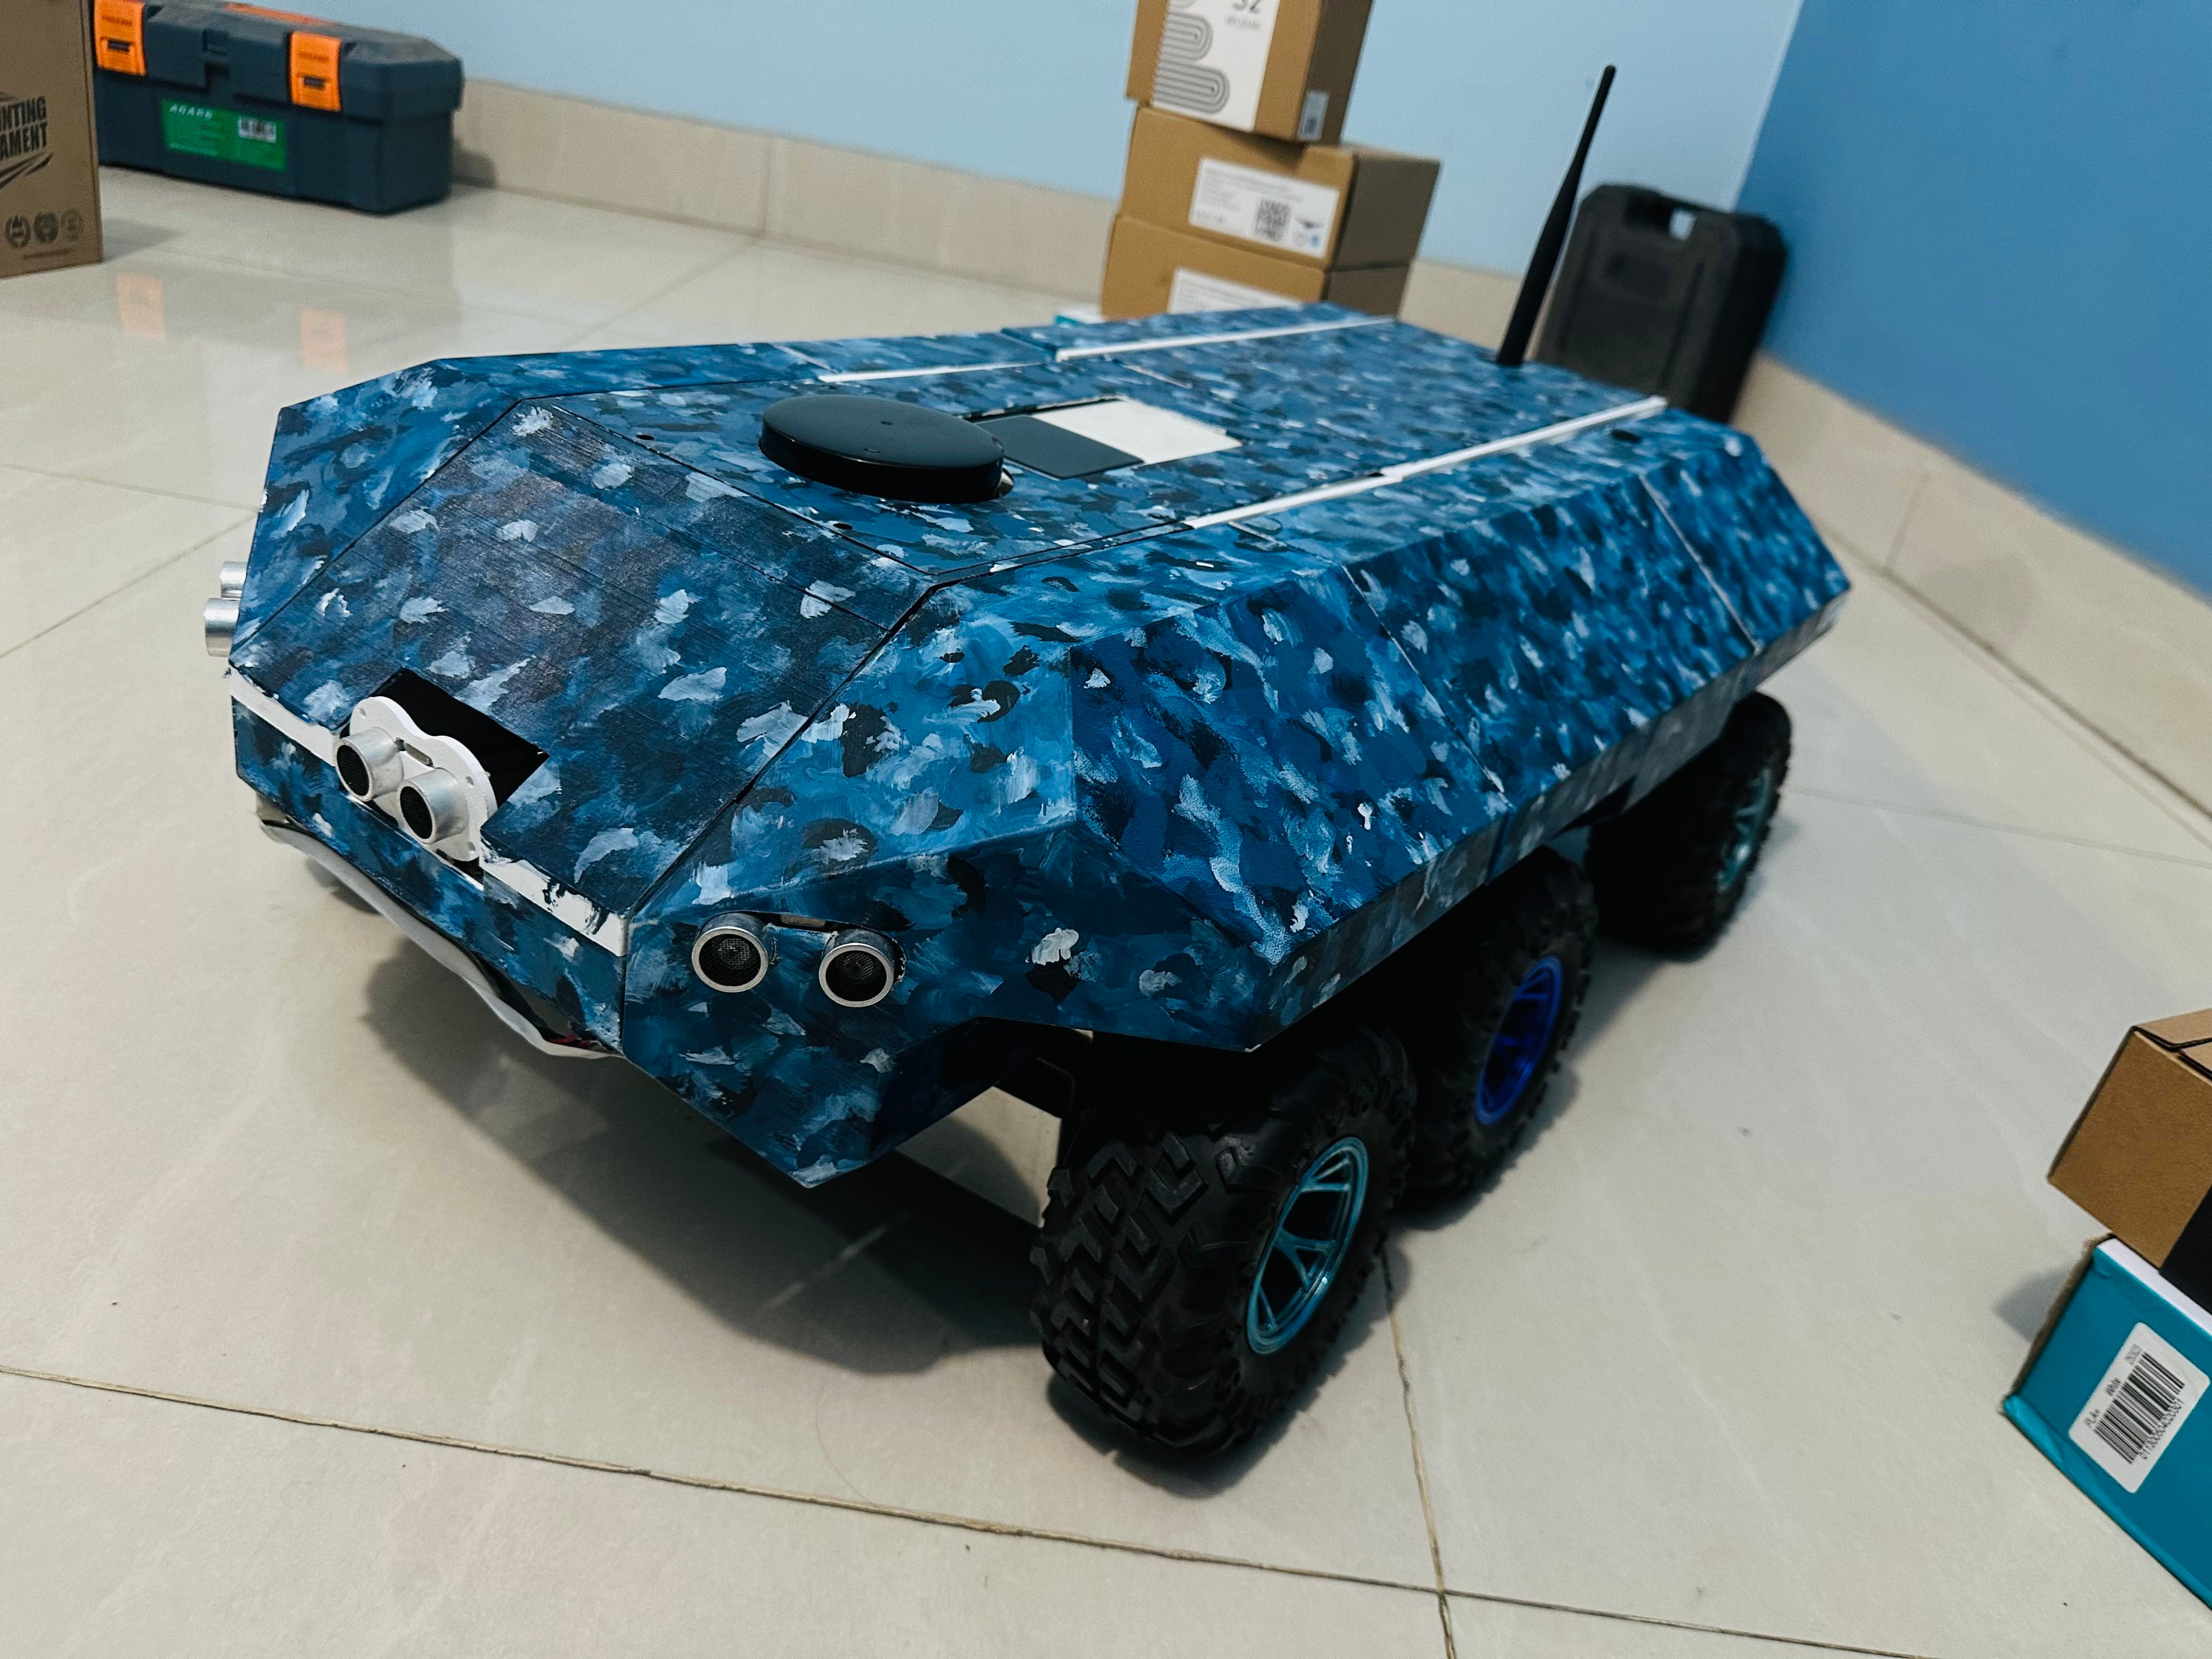
Wheel Tank Robot

OVERVIEW

An advanced autonomous ground robot designed for battlefield operations and surveillance, capable of remote operation from anywhere in the world.

PROJECT BRIEF

The system integrates ROS2, RTK GPS, LiDAR, 3D cameras, and IMU sensors to enable real-time mapping, navigation, and situational awareness. It supports both indoor and outdoor SLAM for autonomous mobility across complex terrains.

ROLE

Lead Mechatronics Engineer, Robotics Programmer

METHOD

From mechanical design and prototyping to software development and testing, we handled the entire development cycle. The robot features a modular structure with AI-driven perception, reliable communication, and robust performance across challenging military terrains.

ROS2 SLAM & Navigation Computer Vision & AI Embedded Systems & IOT
SOLAR ROBOTICS

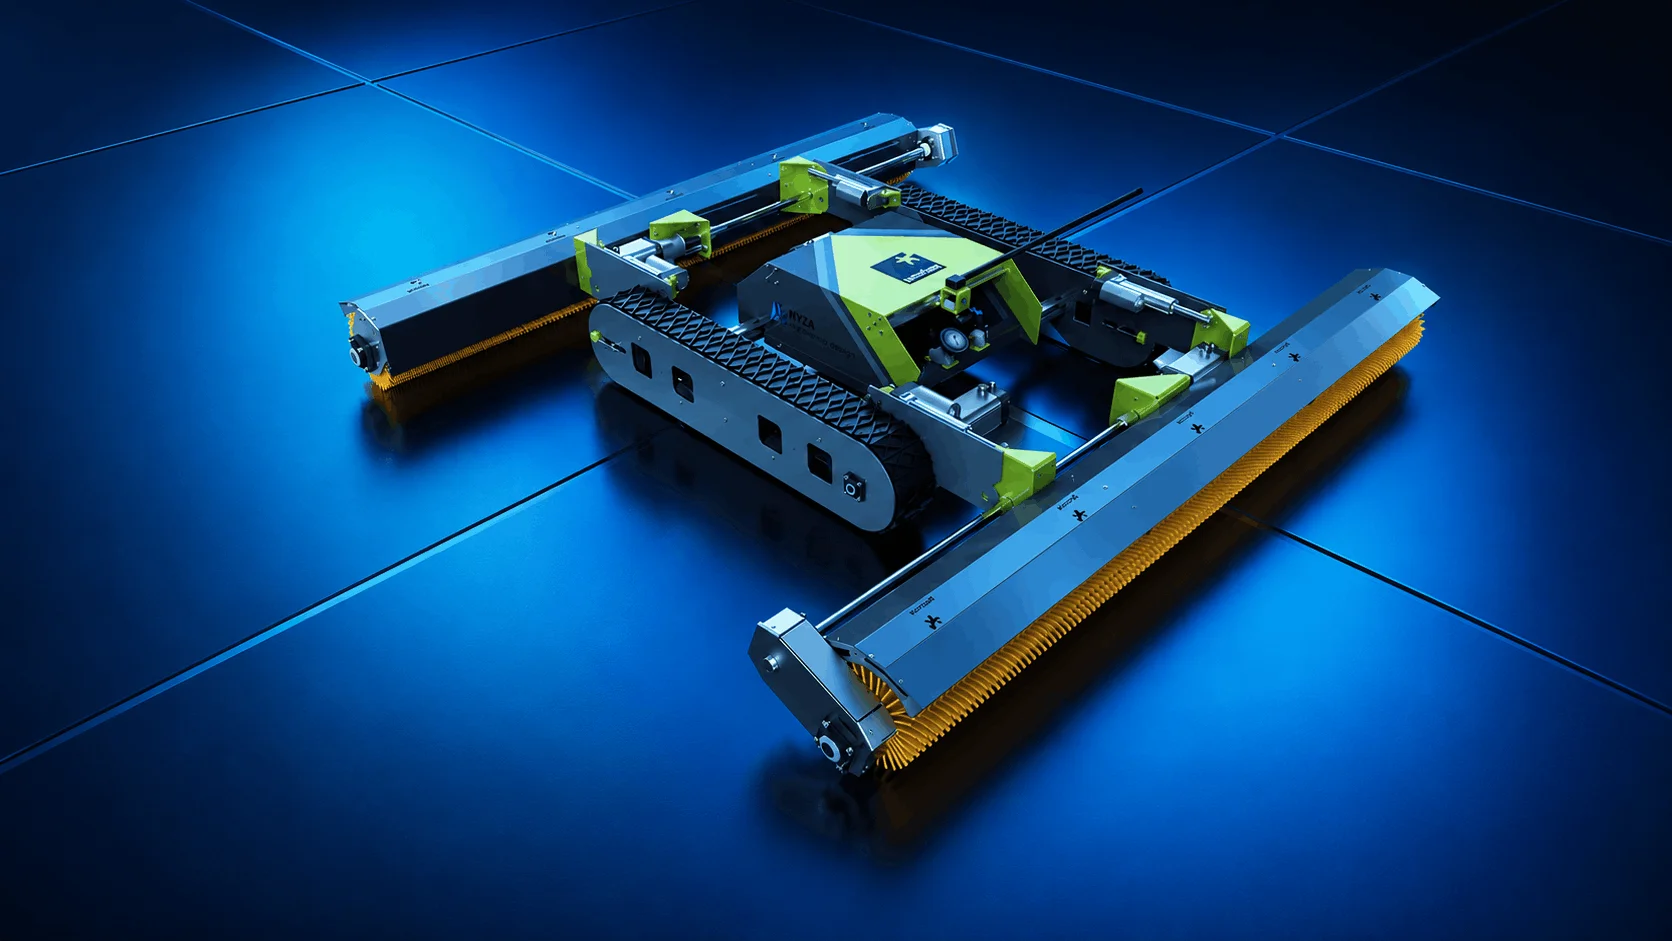
Compact PV Cleaning Robot

OVERVIEW

An innovative solution was required to climb solar panels without hurting the cleaning brushes.

PROJECT BRIEF

Designed a mobile robot with all the requirements given by the client and made a lot of modifications based on my experience with robots. All custom parts were built with design for manufacturing considerations.

ROLE

Lead Mechatronics Engineer, Robotics Programmer

METHOD

After some intensive research, the product concept was developed, and then we tried to list down the off-the-shelf components. The parts were modeled in Fusion 360, and motors, mounts, transmissions, bearings, brackets, and fasteners were gradually selected according to the needs.

SolidWorks CAD DFM Analysis High-Current PCB Crawler Drive
Security Robotics

SURVEILLANCE ROBOT

OVERVIEW

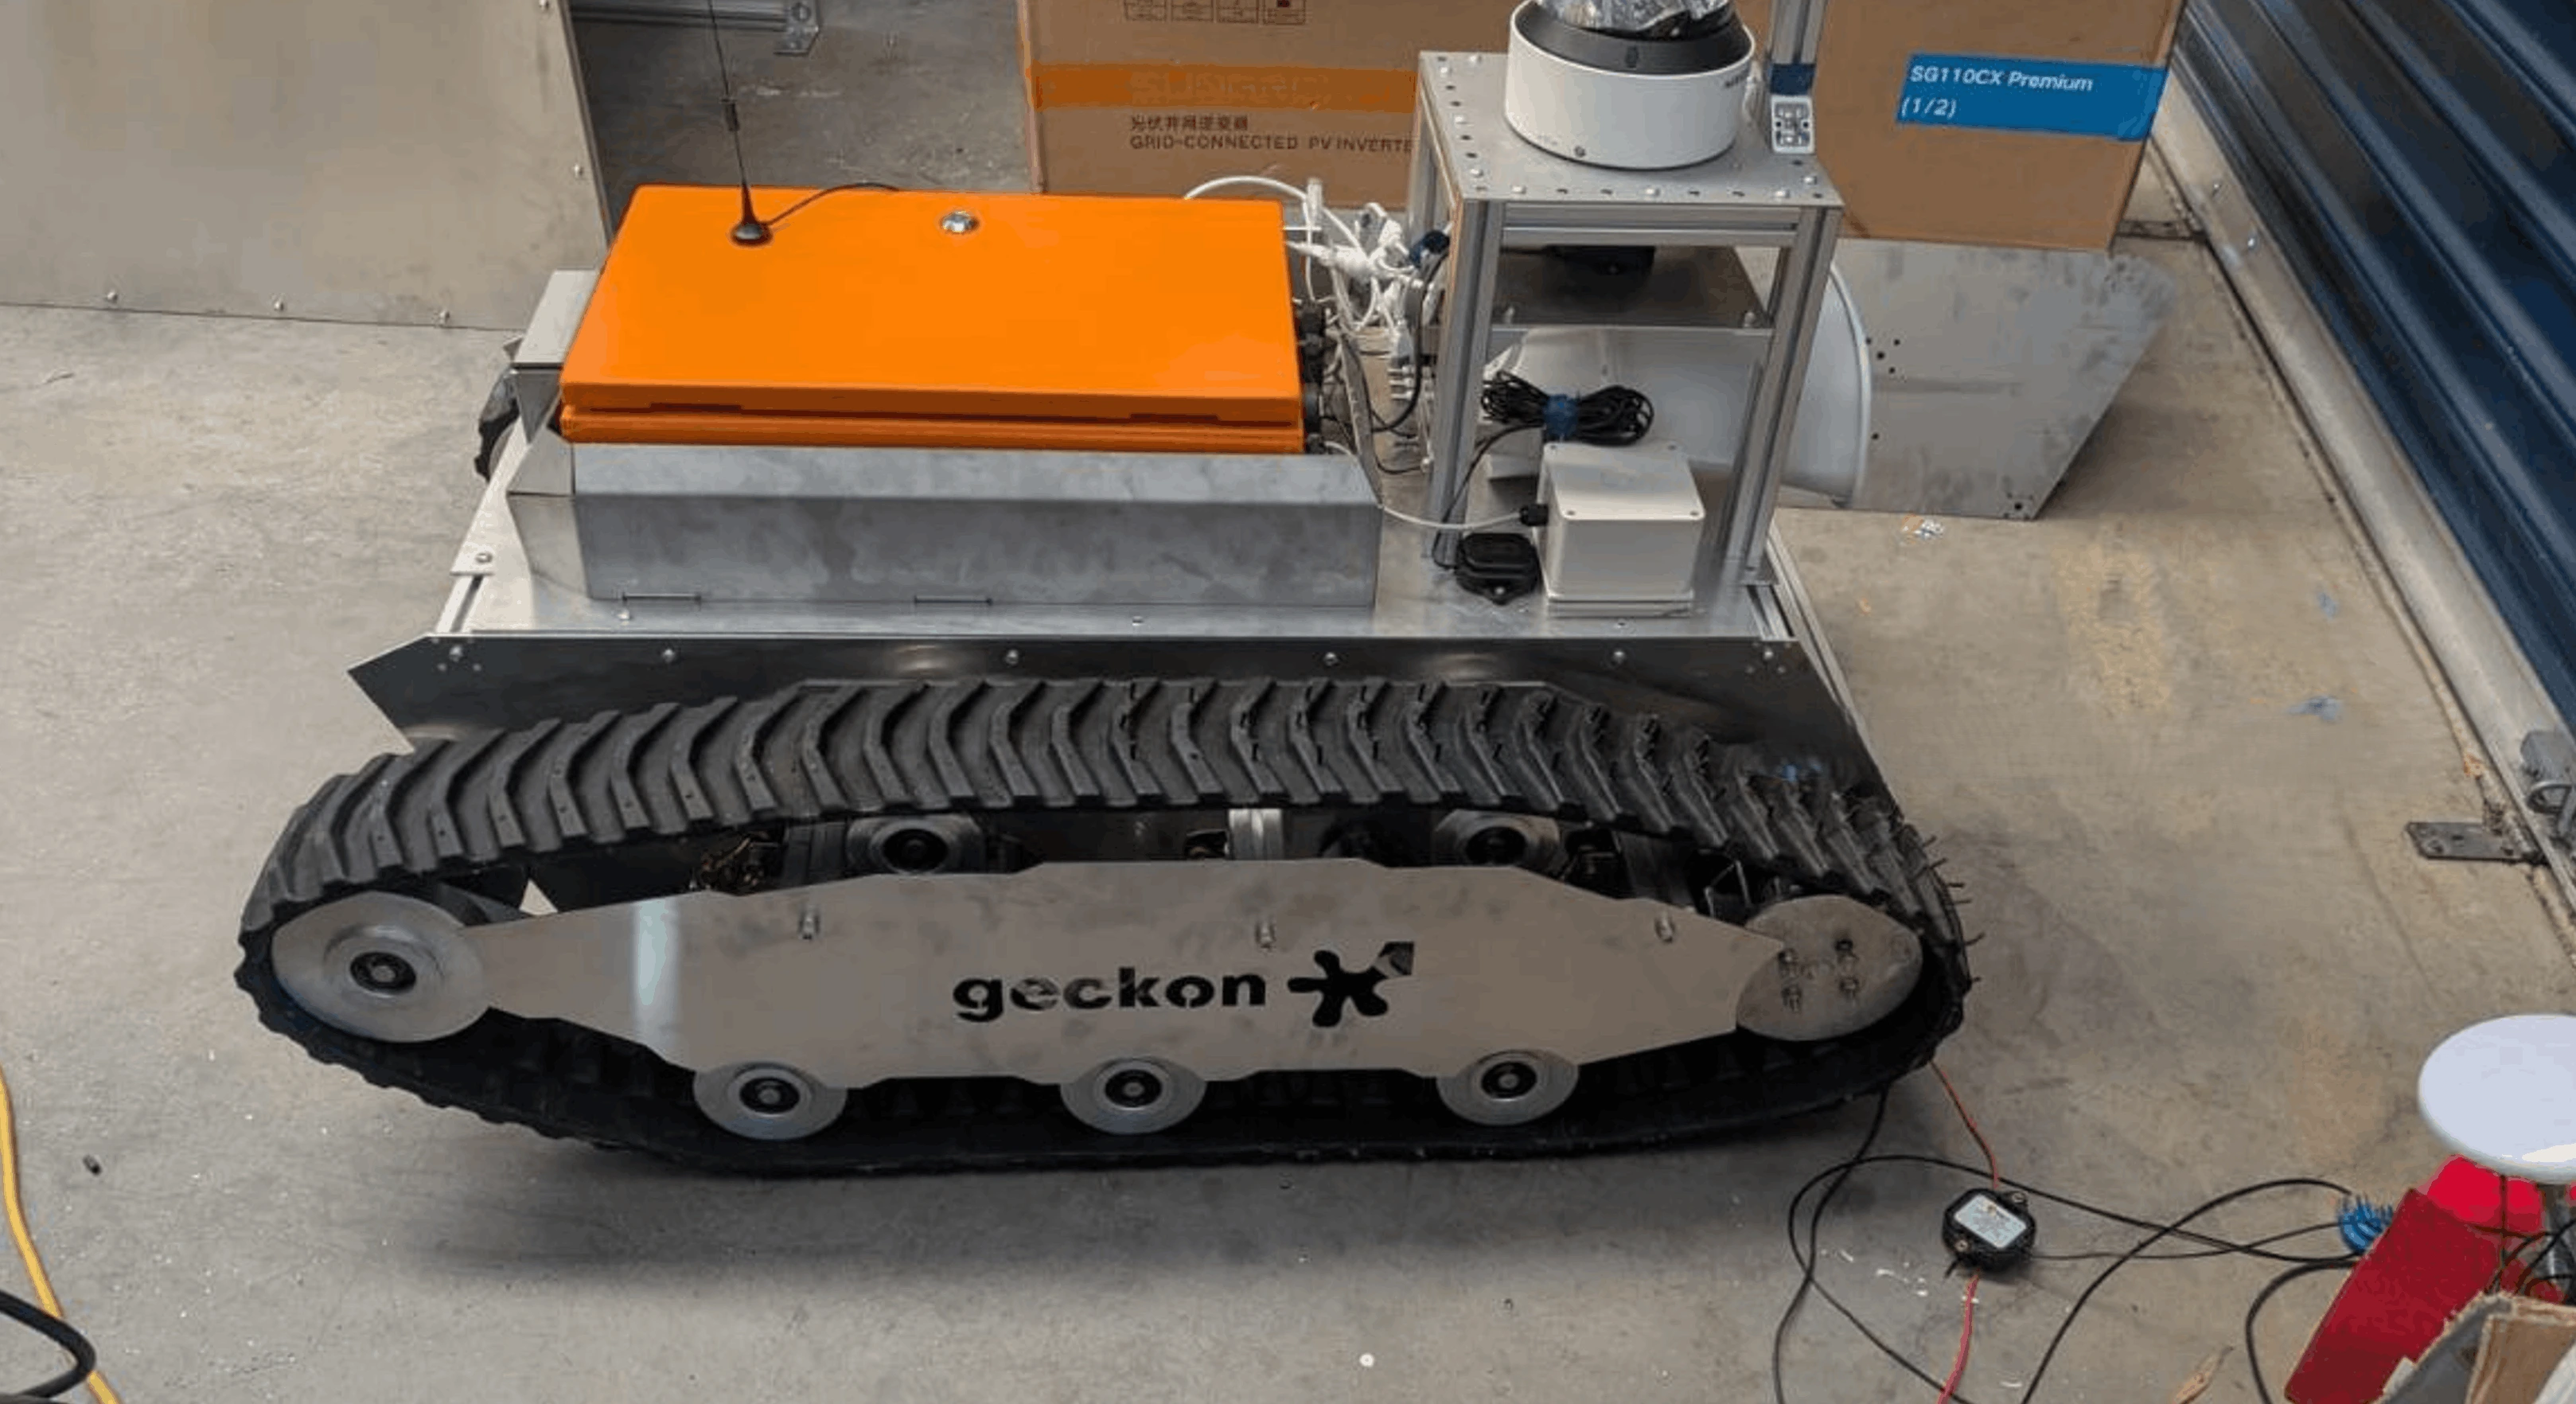
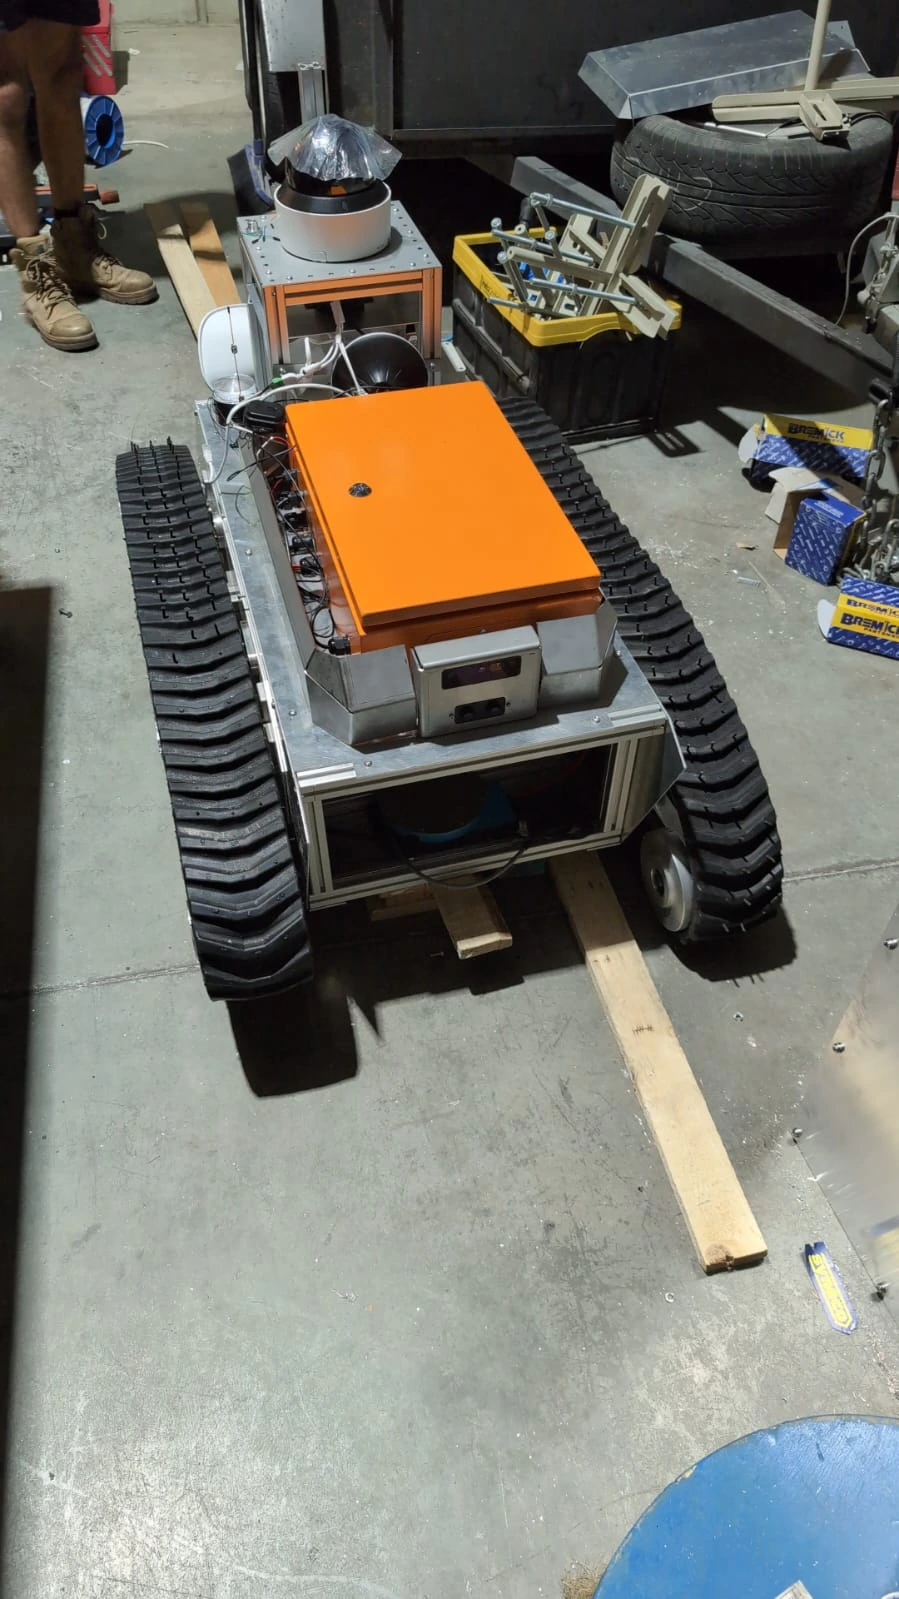
A 20 kg autonomous tracked surveillance robot built for 24/7 patrol and threat detection in harsh industrial terrains where wheeled platforms and human guards struggle.

PROJECT BRIEF

The system integrates ROS 2 Nav2, 360° LiDAR, single depth cameras, RTK GPS, and a 25x optical zoom PTZ camera for real-time mapping, intruder detection, and centimeter-level navigation. It also supports automated RTK docking and secure remote operation through Zenoh and Tailscale.

ROLE

Lead Mechatronics Engineer, Robotics Programmer

METHOD

The project started with concept sketching and 40+ track design iterations, followed by FEA-based structural validation and CNC machining and 3D printing of the chassis. We then integrated the 48V electrical system, sensors, and ROS 2 software stack, and validated everything through a 72-hour burn-in and field testing across four climate zones.

Fusion360 Mechanical Design Embedded Systems Robotics
Our Methodology

HOW WE BUILD IT

We follow a structured mechatronics development cycle to convert digital models into robust hardware.

1
Phase 01

Discovery & Concept

We begin by understanding your specific mechanical constraints, payloads, operating environments, and R&D vision through in-depth engineering discovery sessions.

2
Phase 02

3D Modeling & CAD

Creating high-precision geometric assemblies in SolidWorks and Fusion 360. We simulate kinematic movements, check clearance tolerances, and run stress analysis (FEA).

3
Phase 03

Prototyping & Assembly

Bringing the digital concept to physical reality. We utilize CNC milling, laser cutting, 3D printing (SLA/FDM), and custom double-layer PCB assembly to manufacture early iterations.

4
Phase 04

Optimization & Deployment

We load firmware and test structural behaviors under static/dynamic loads. Motors, PID parameters, and sensor arrays are calibrated until systems operate at 100% capacity.

What Our Clients Say

Read verified reviews from engineering directors, CTOs, and global innovators who trust Nyza.

Play Video Review
VERIFIED B2B CLIENT REVIEWS
Stats

NYZA BY THE NUMBERS

A quick snapshot of who we are, what we've built, and how far we've come.

50+ Projects Completed
5 Turnkey Projects
$ Private Funding
2022 Founded In
14+ Team Size
32+ Years Cumulative Experience in Robotics Industry