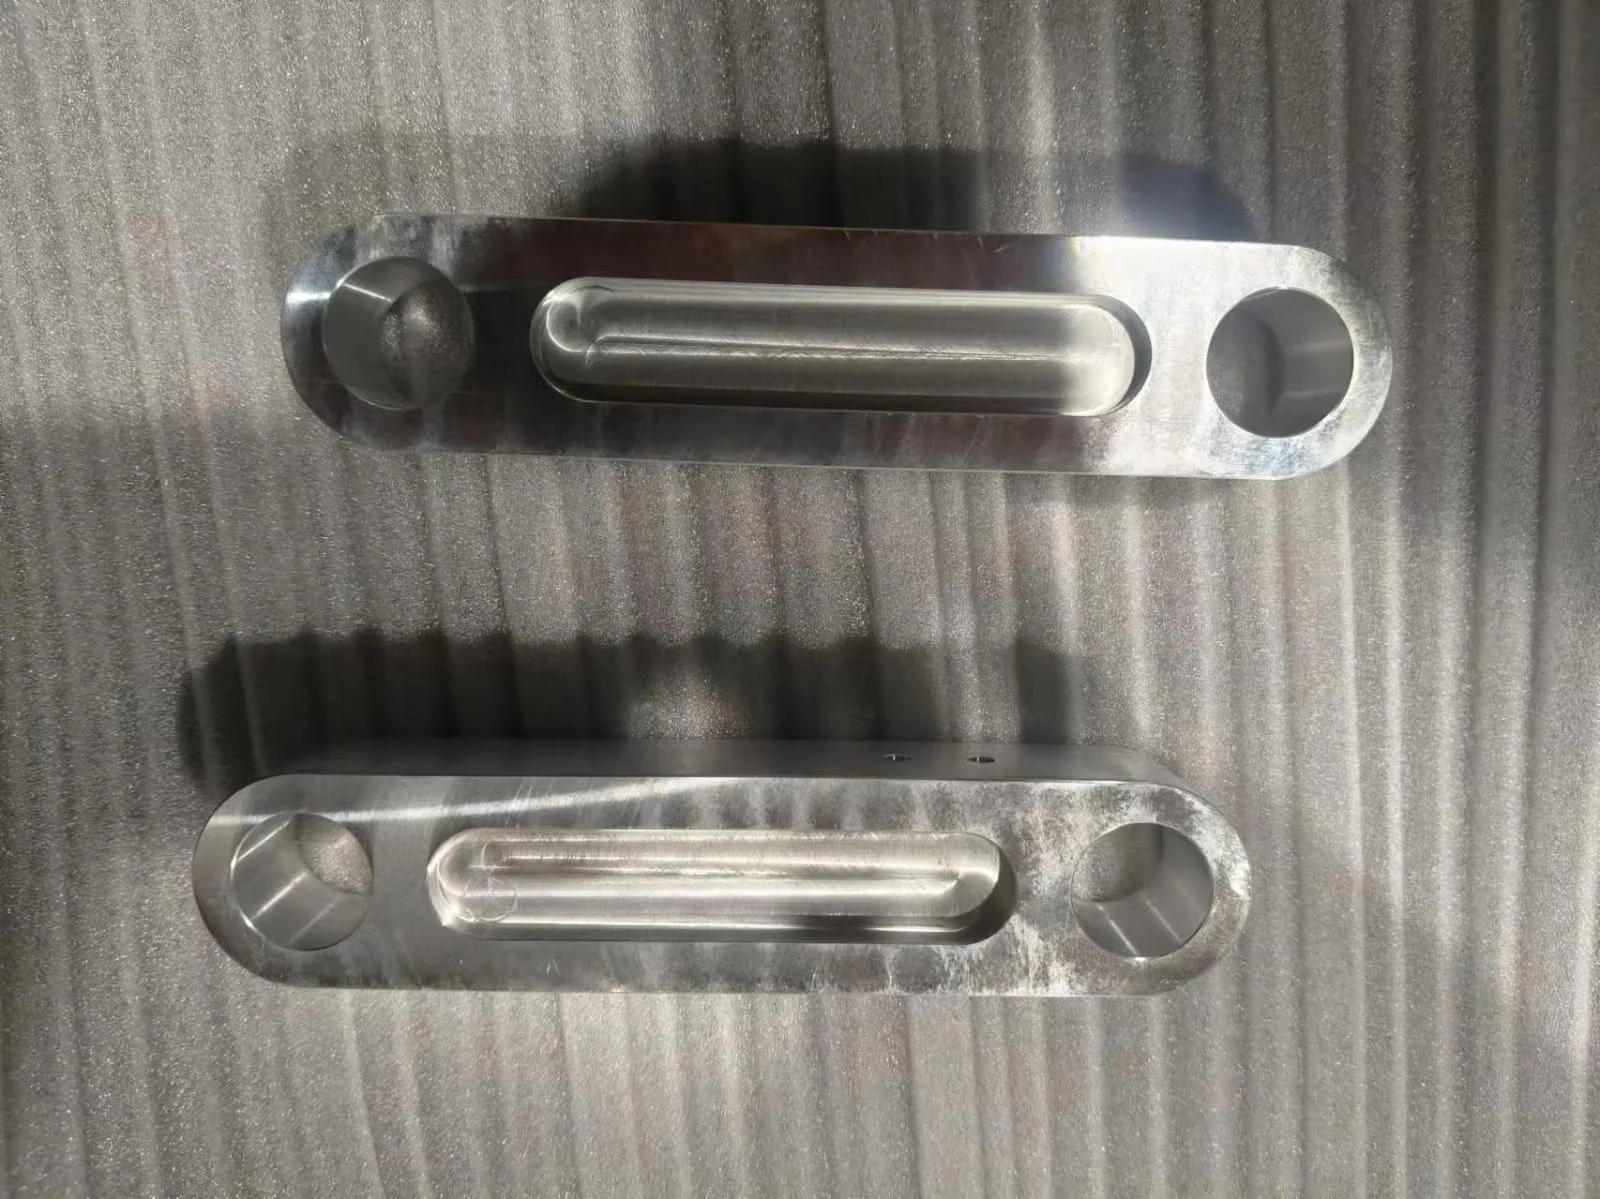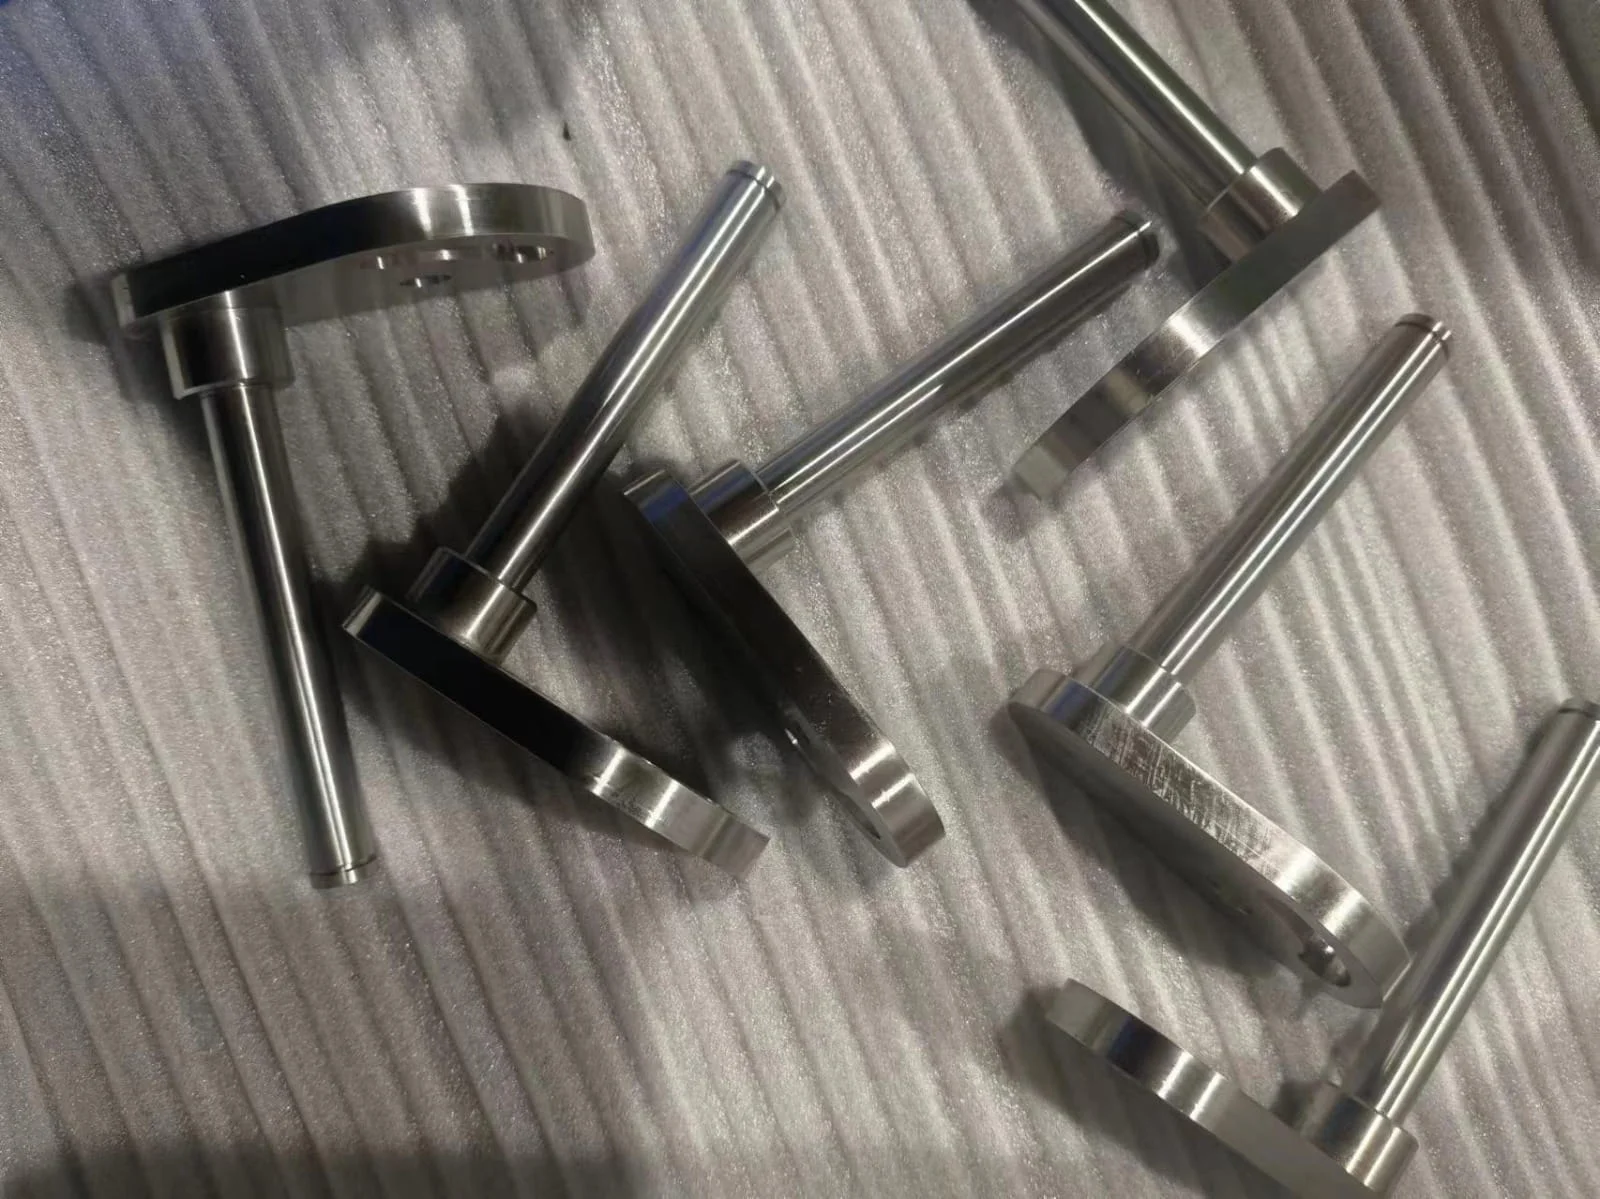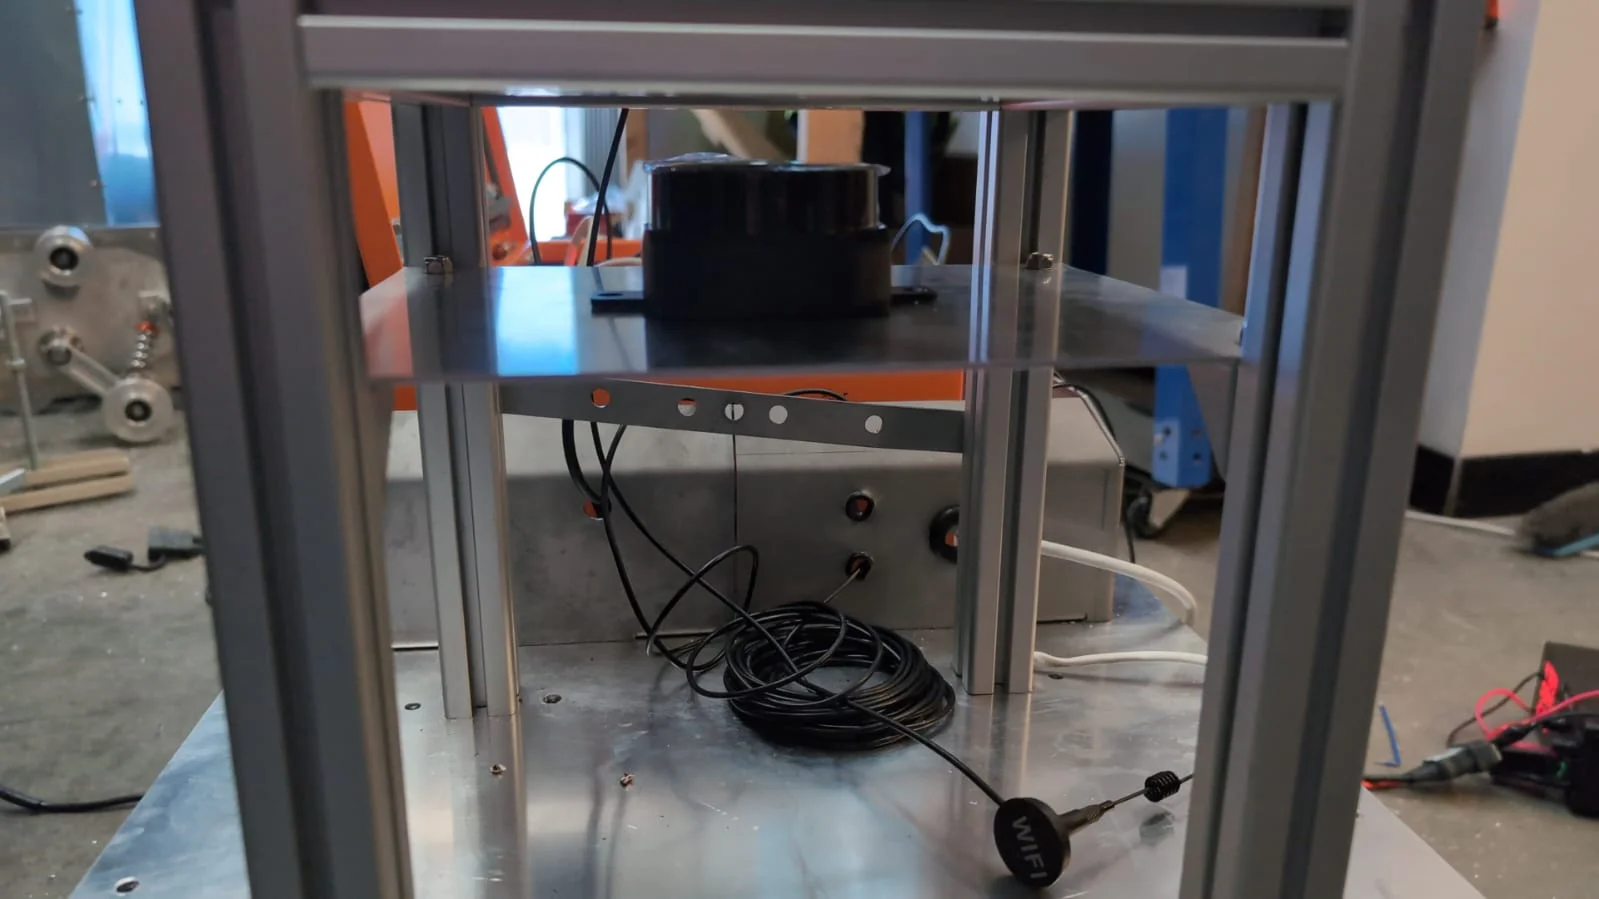
Hero Shot

BEYOND
GROUND

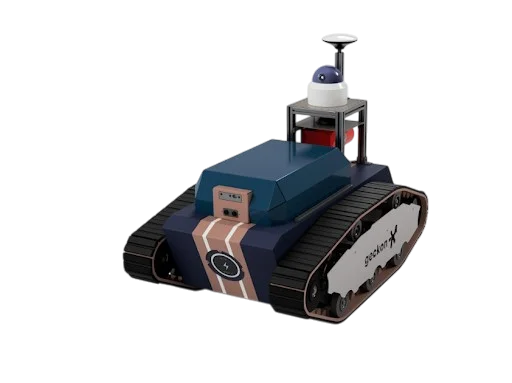
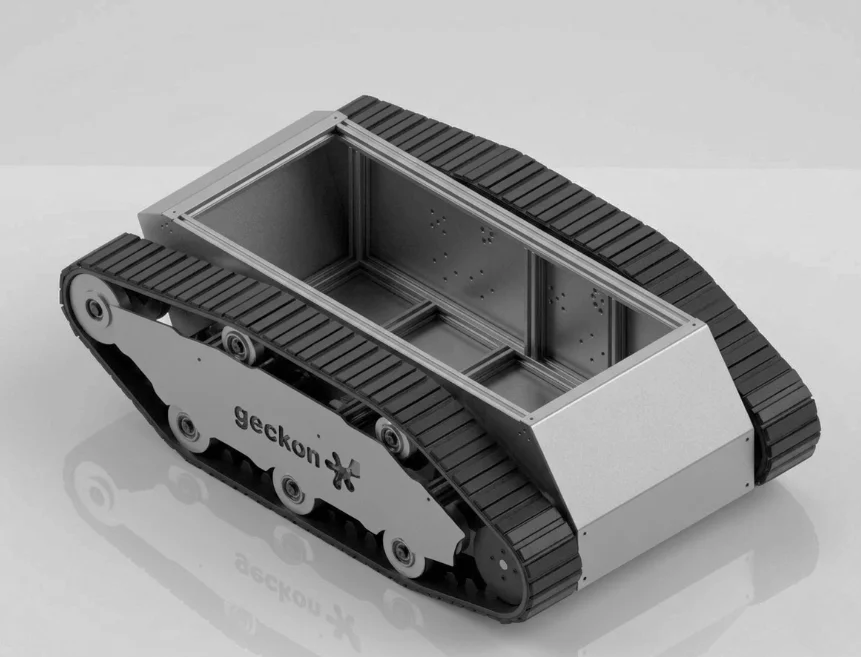
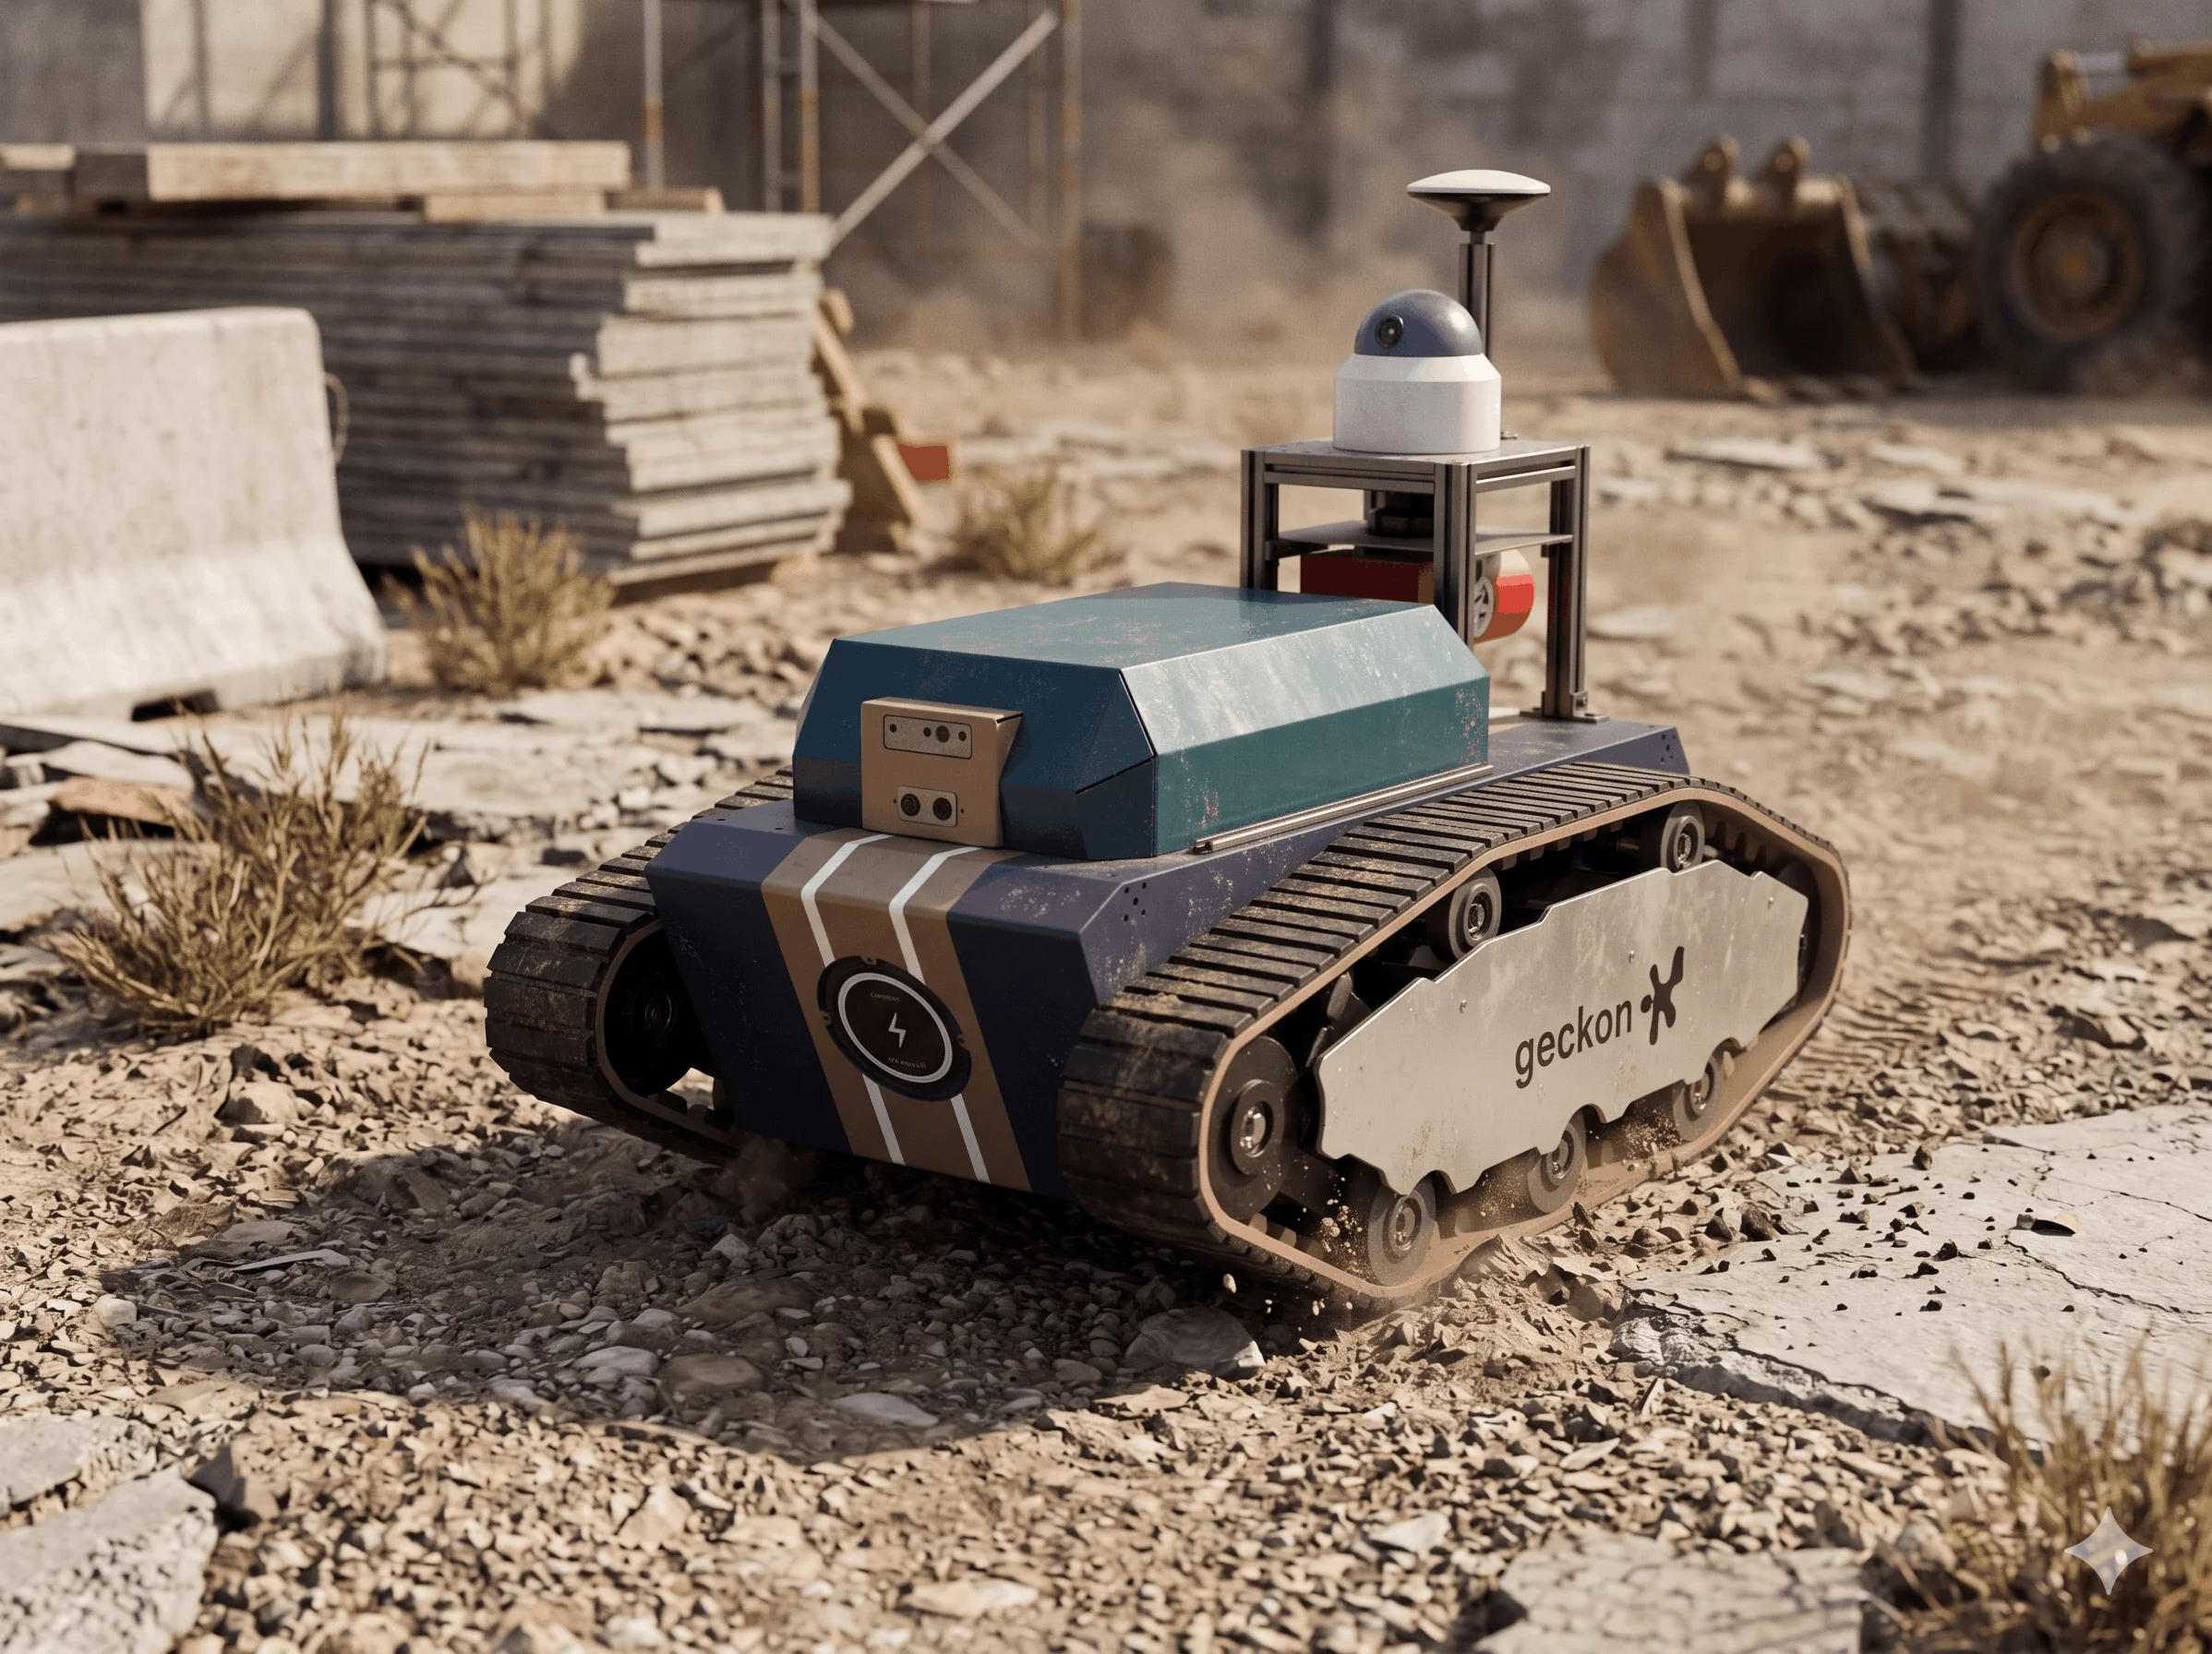
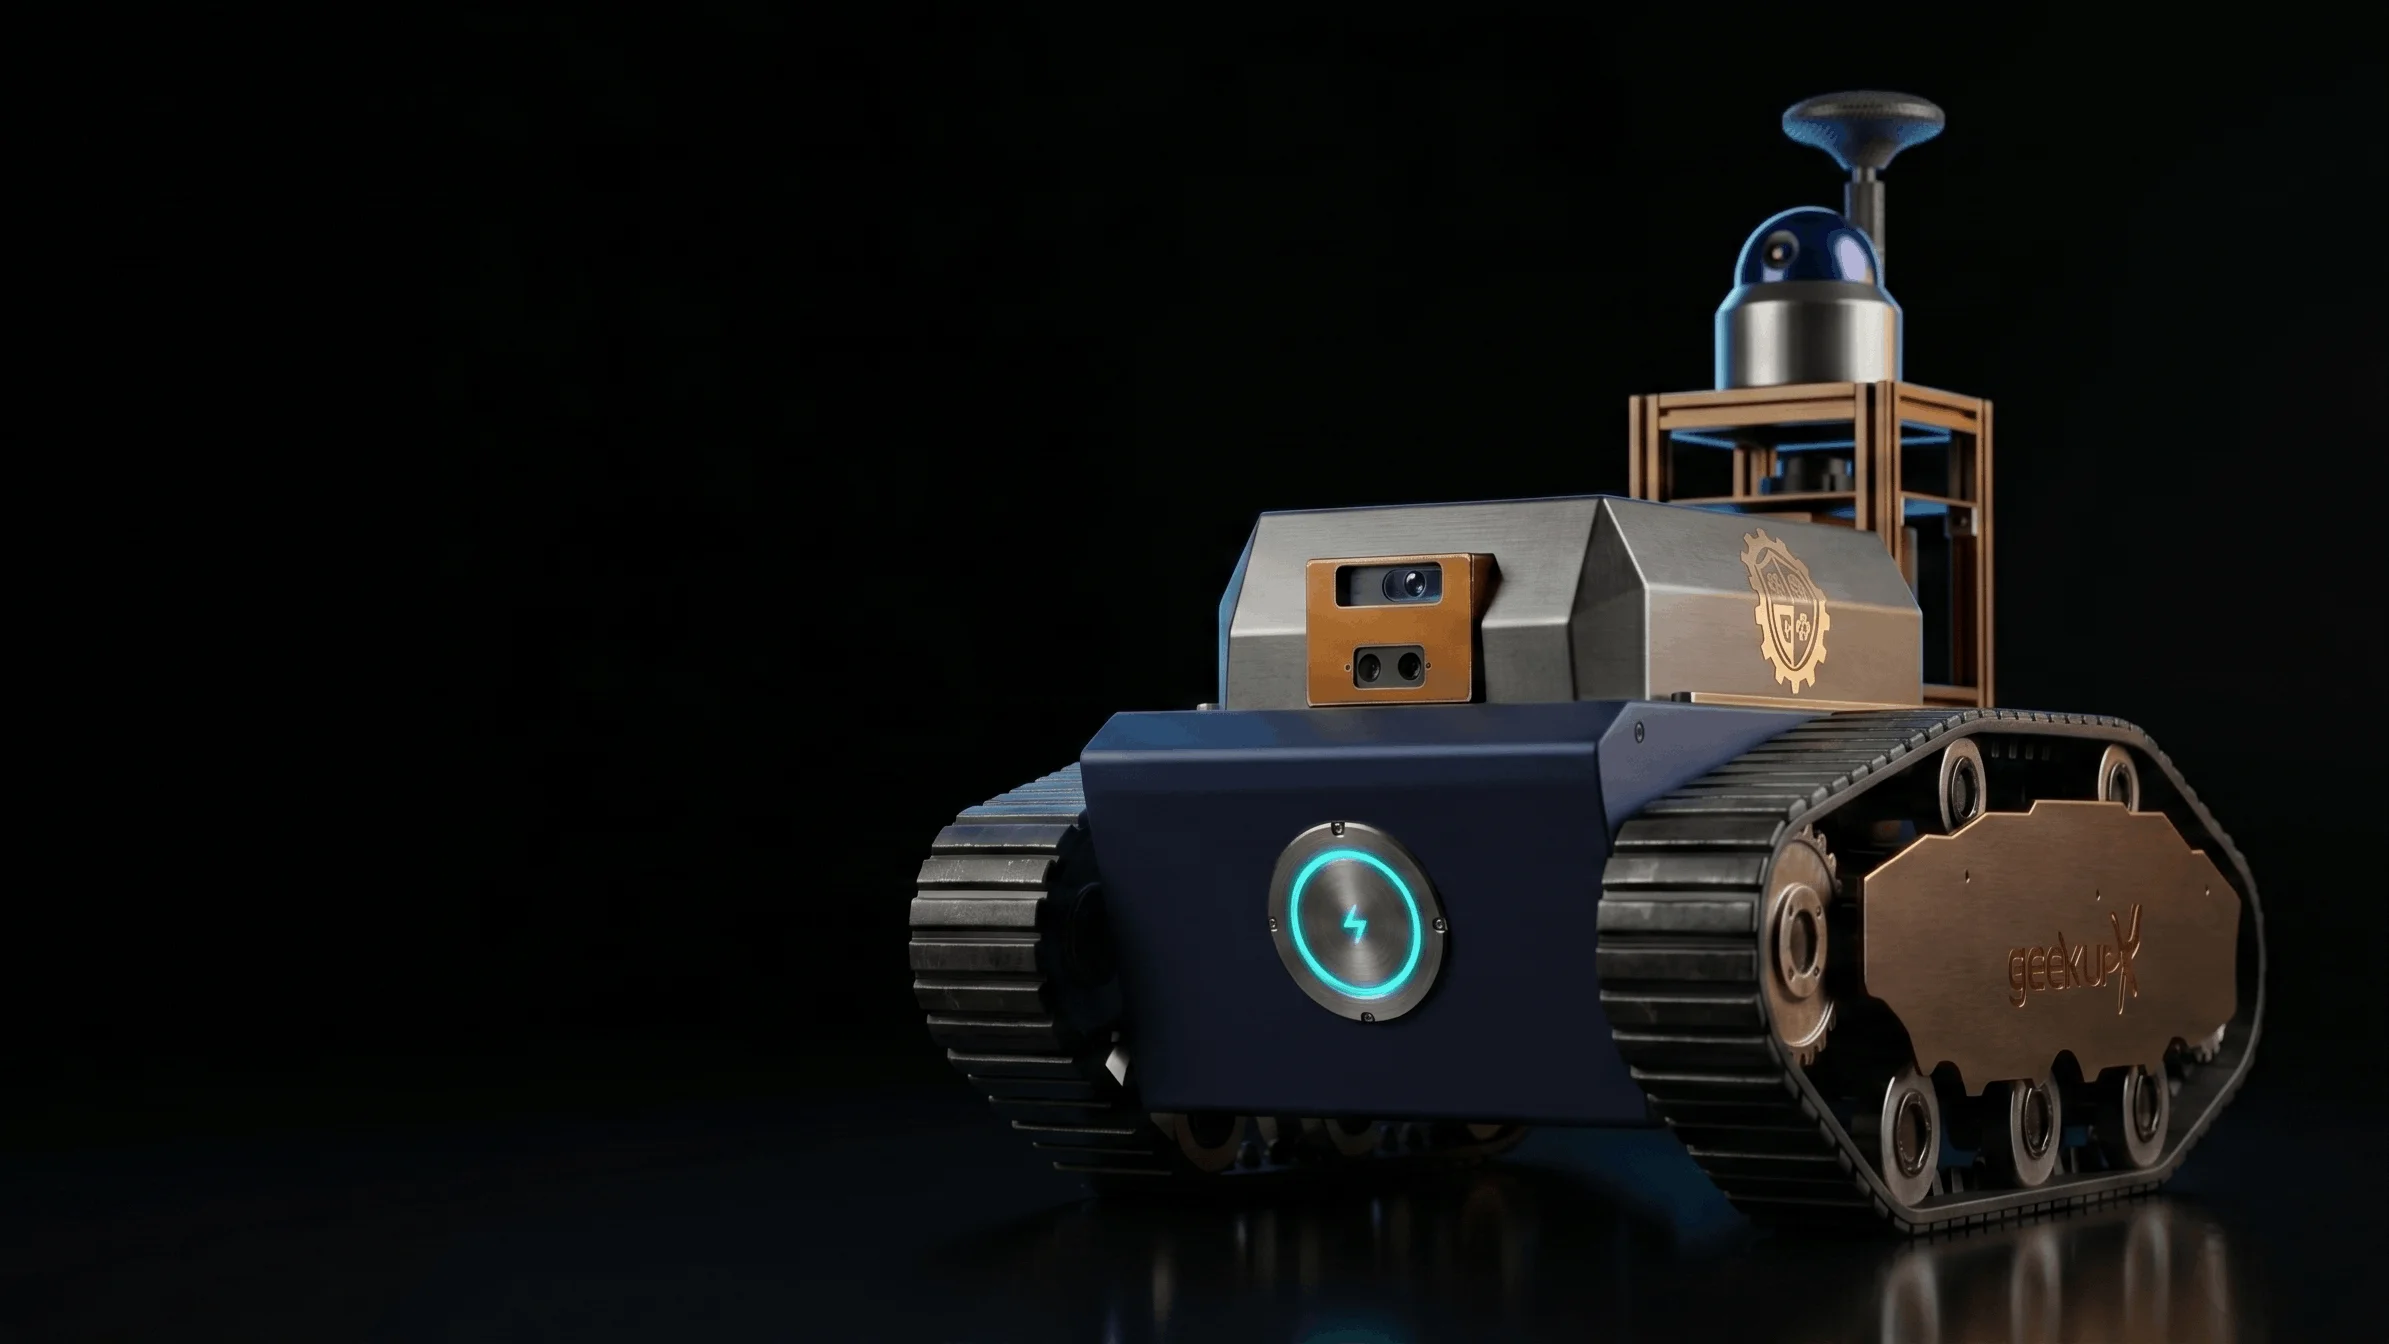
Developing a 45KG autonomous tracked titan capable of navigating the harshest industrial terrains. From silicon to steel.

45kg Payload
2.5m/s Velocity
24h Runtime
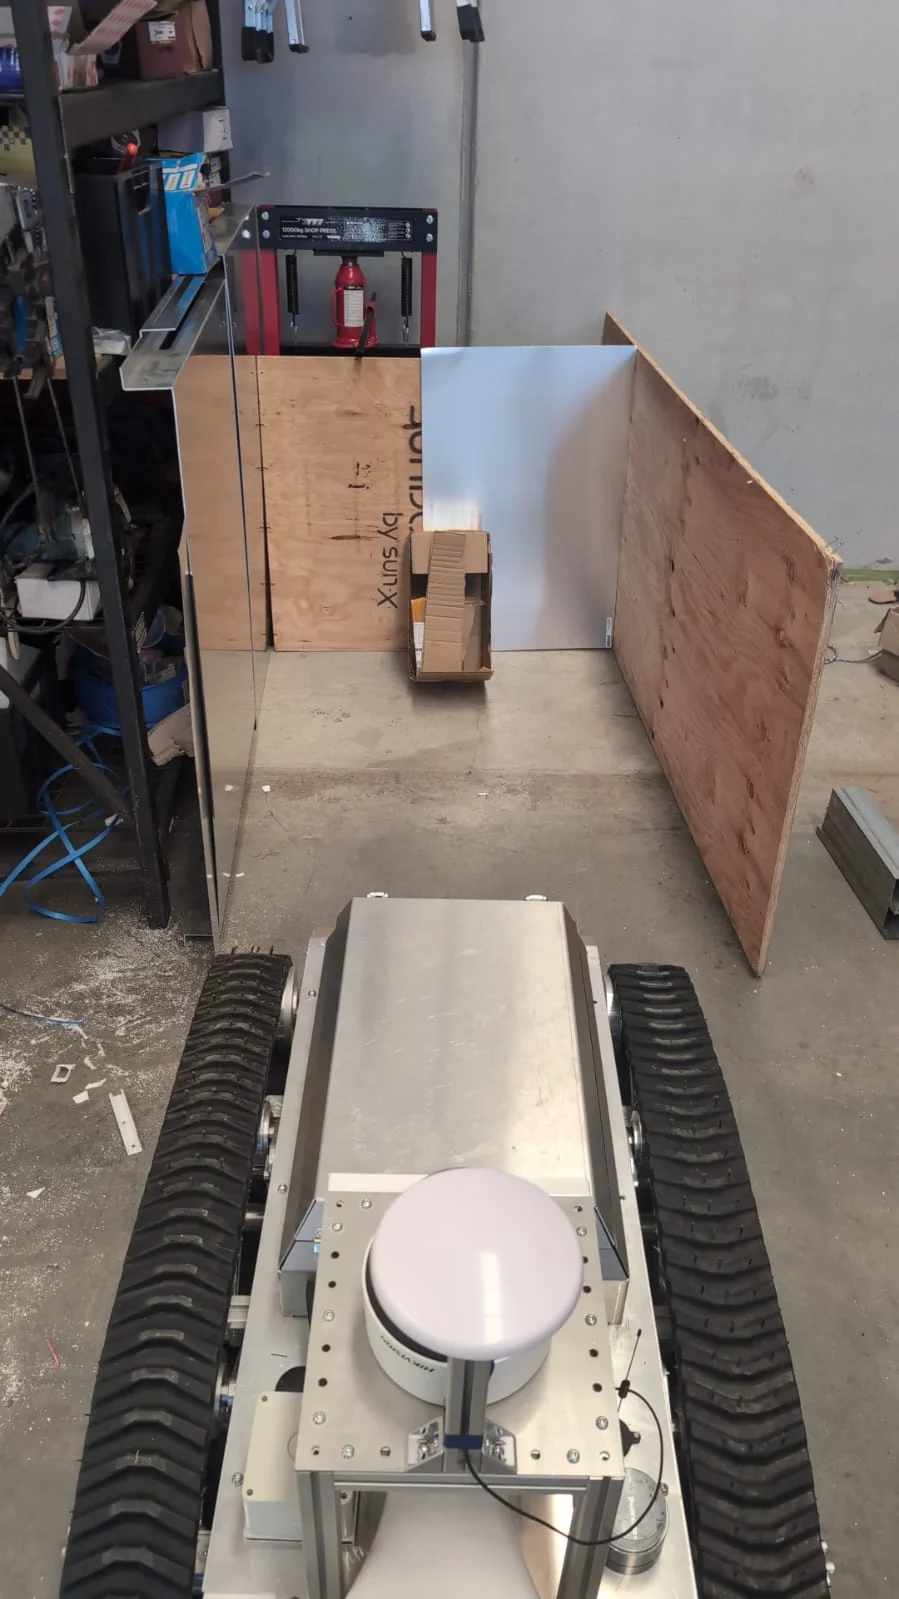
WORKSHOP_MOMENT
WORKSHOP_MOMENT
FIRST_FIELD_TEST
THE GENESIS

BORN FROM
NECESSITY.

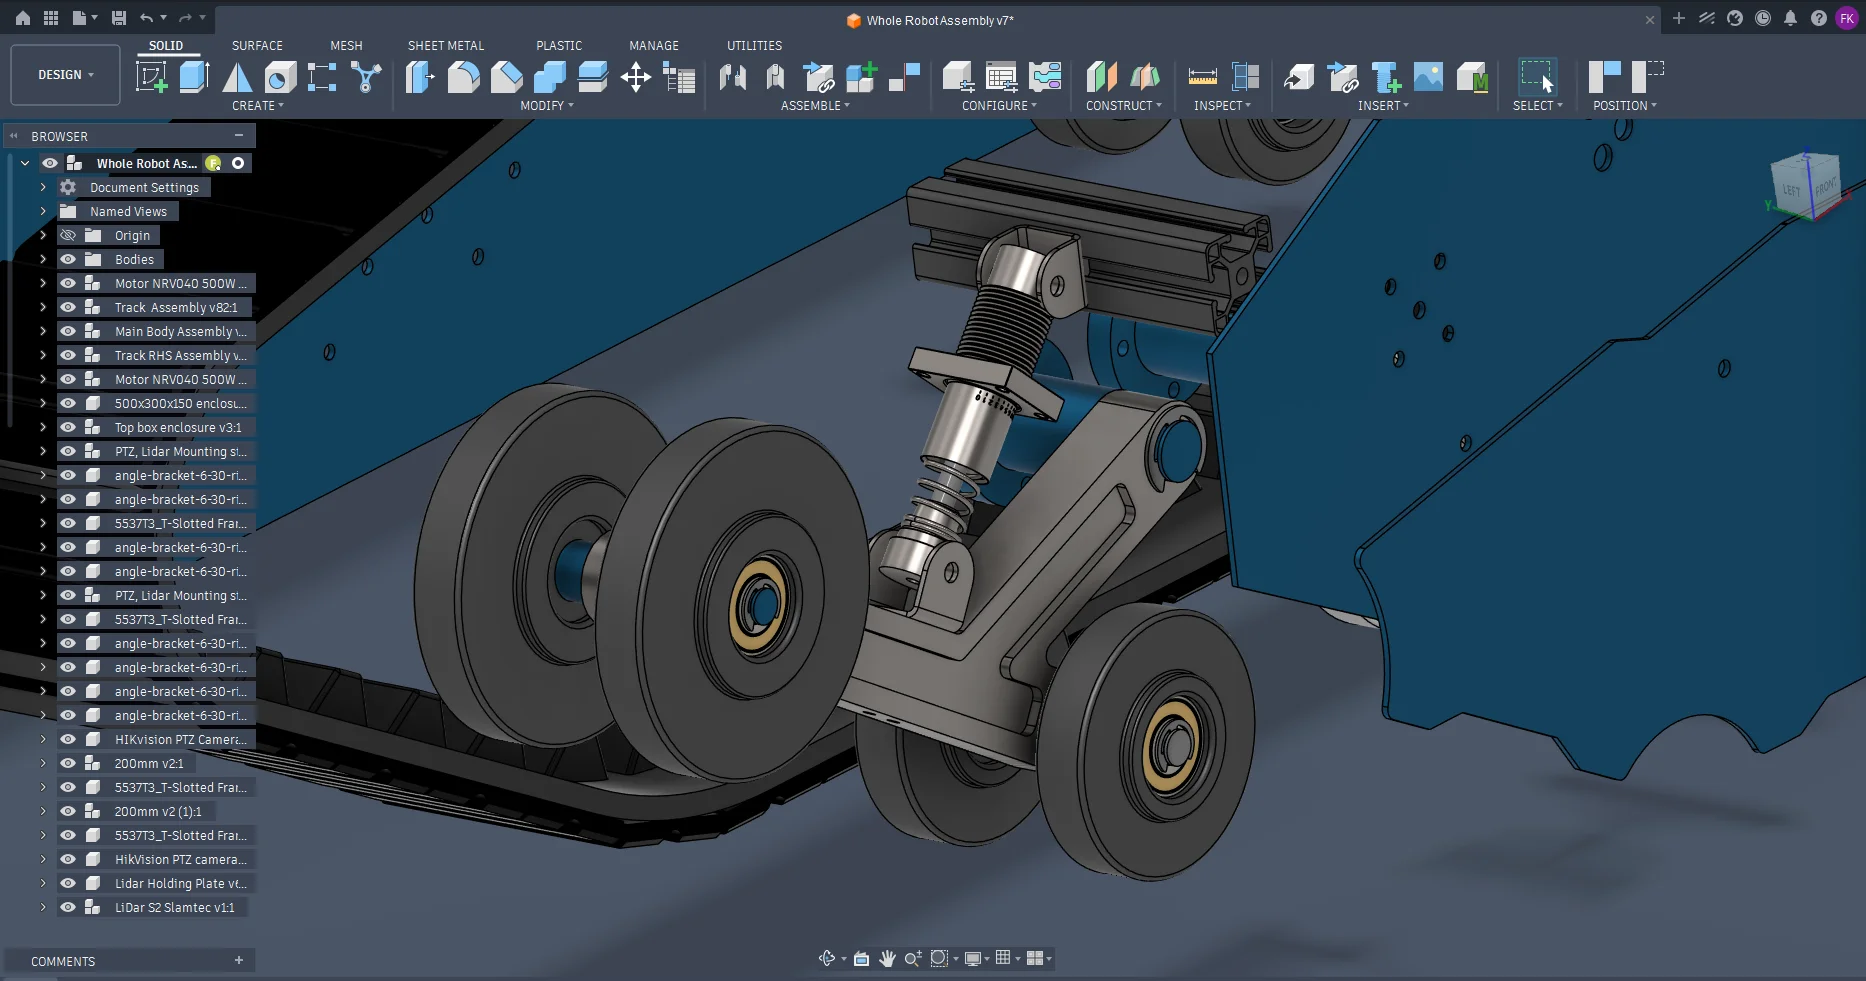
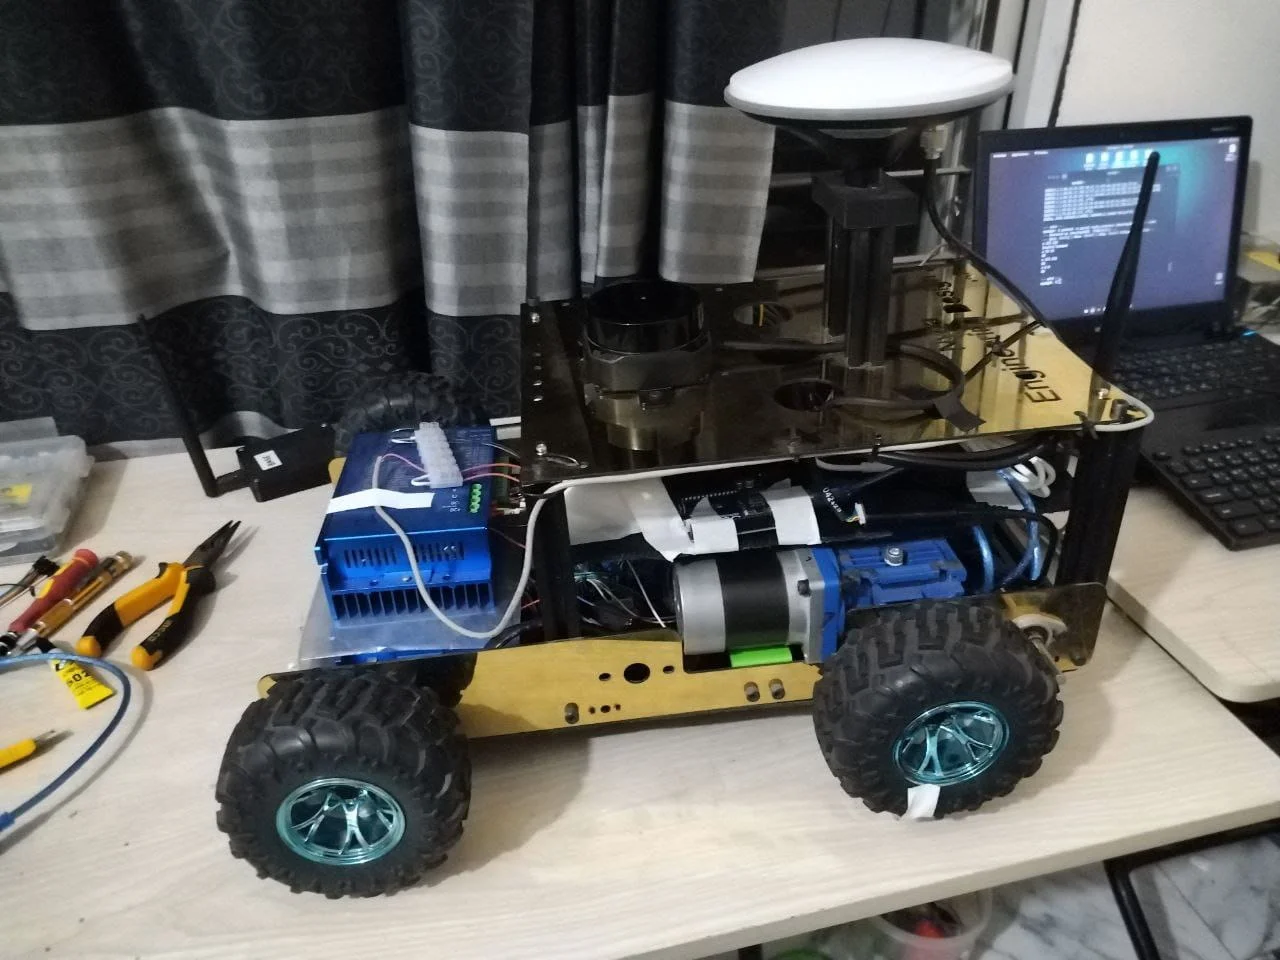
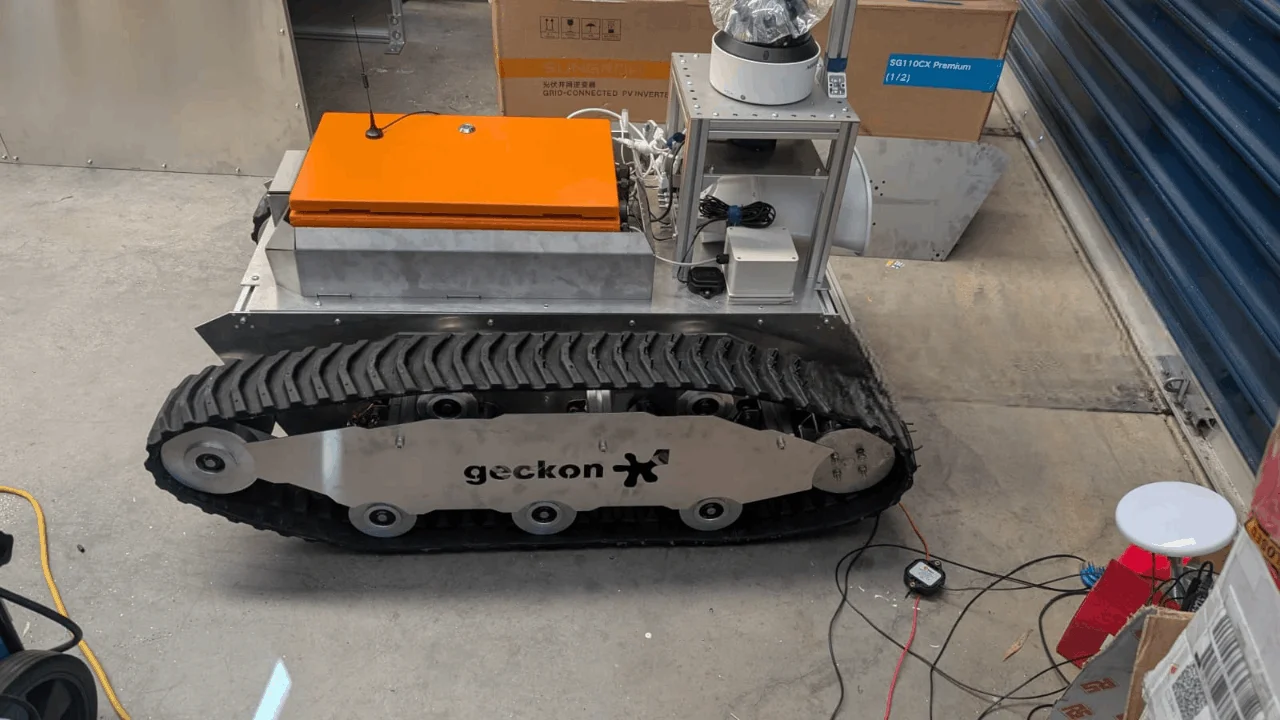
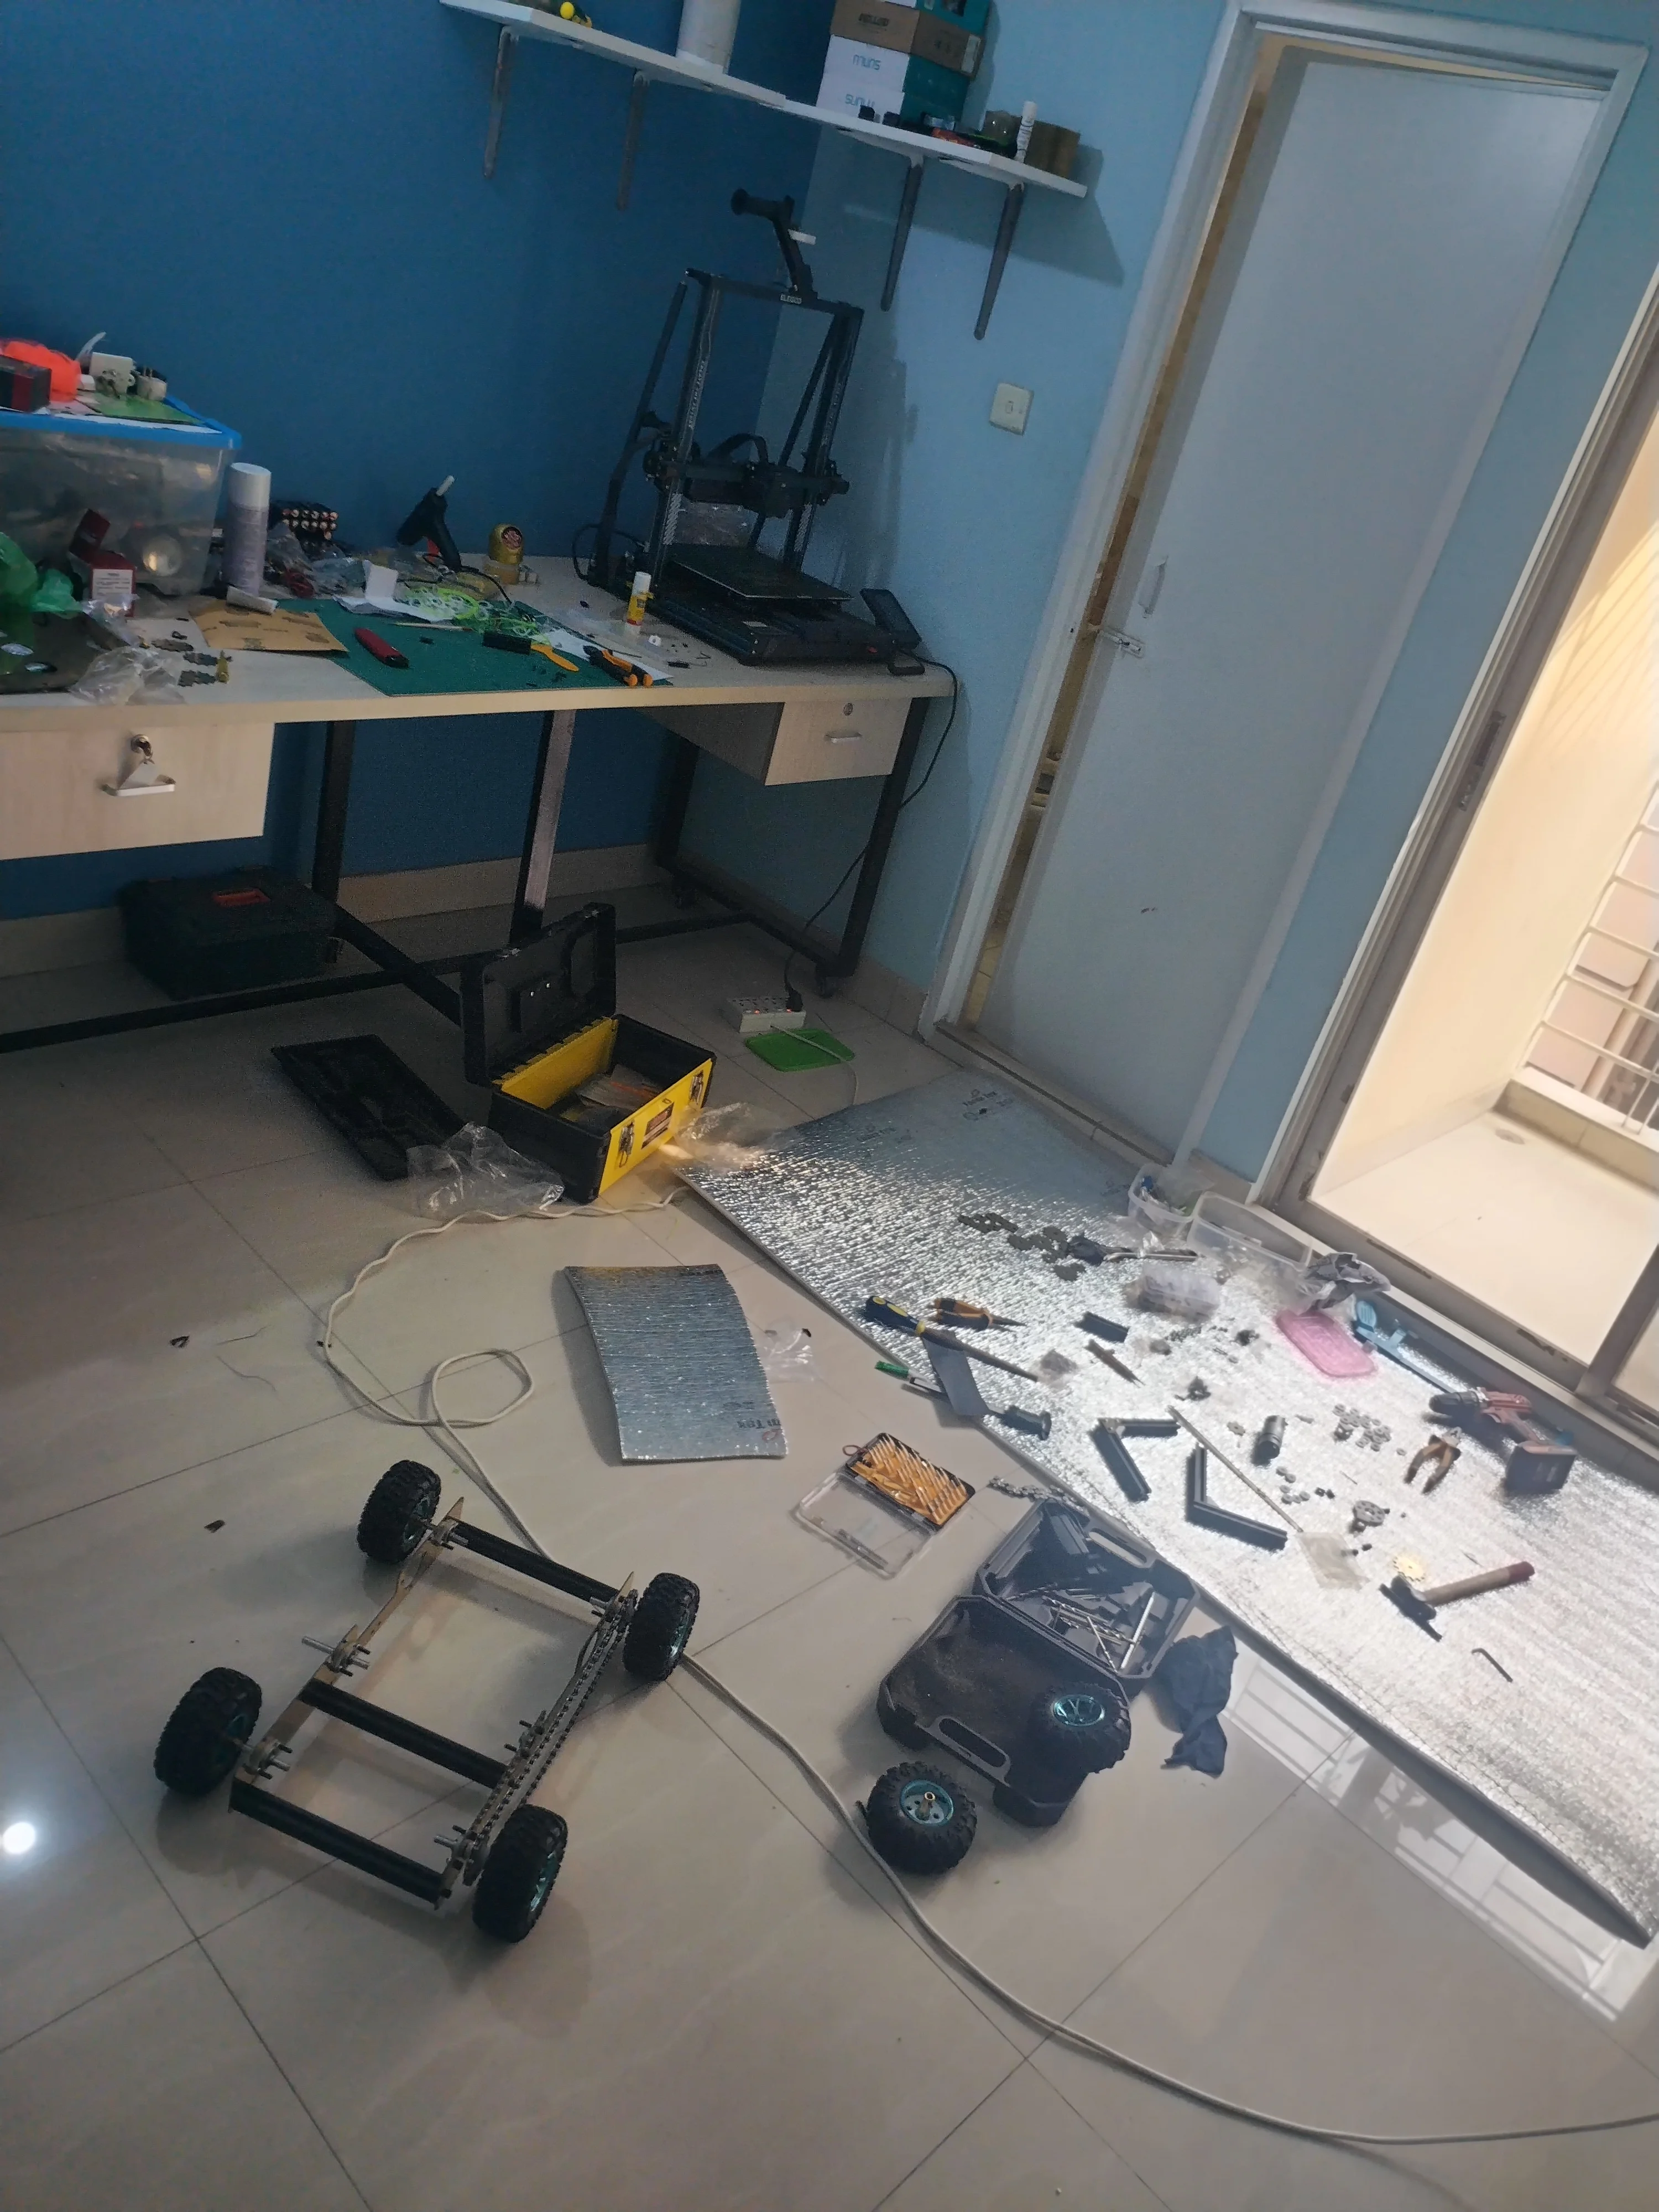
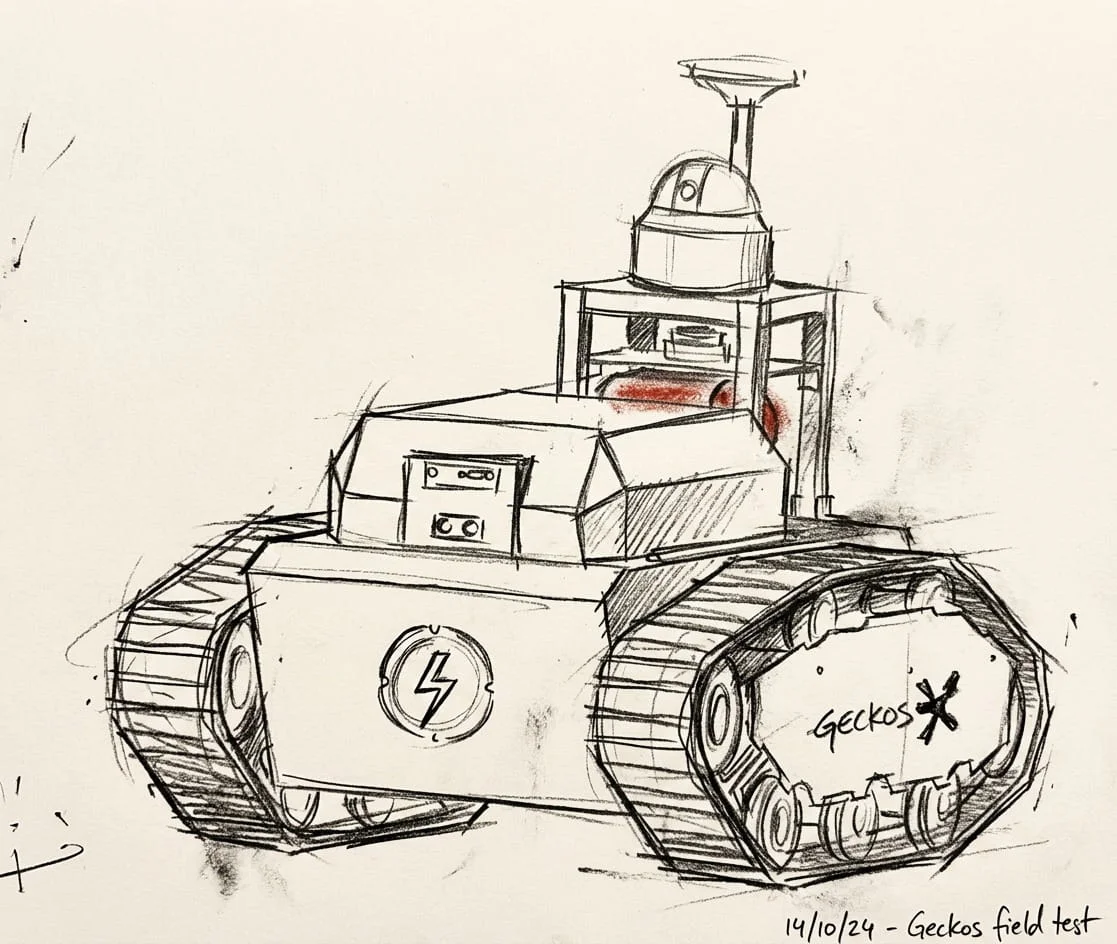
The Titan Drive was born on a rain-soaked construction site where traditional robotics failed. We watched expensive equipment sink into the mud, unable to navigate the very terrain it was built to monitor. That failure became our blueprint. For eighteen months, our team bridged the gap between CAD models and field tests, refining a tread system that turned a 45KG chassis into an unstoppable force. We didn't just build a robot; we engineered a solution for the unreachable.
01

The Challenge

Most robots fail when they meet the real world. Mud, debris, and unpredictable obstacles cripple wheeled platforms. We needed a machine that didn't just move, but dominated the surface.

"The goal was simple: 100% autonomy in environments where humans can't safely tread."

WORKSHOP_MOMENT
PROTOTYPE_V1
3D_MODEL_02

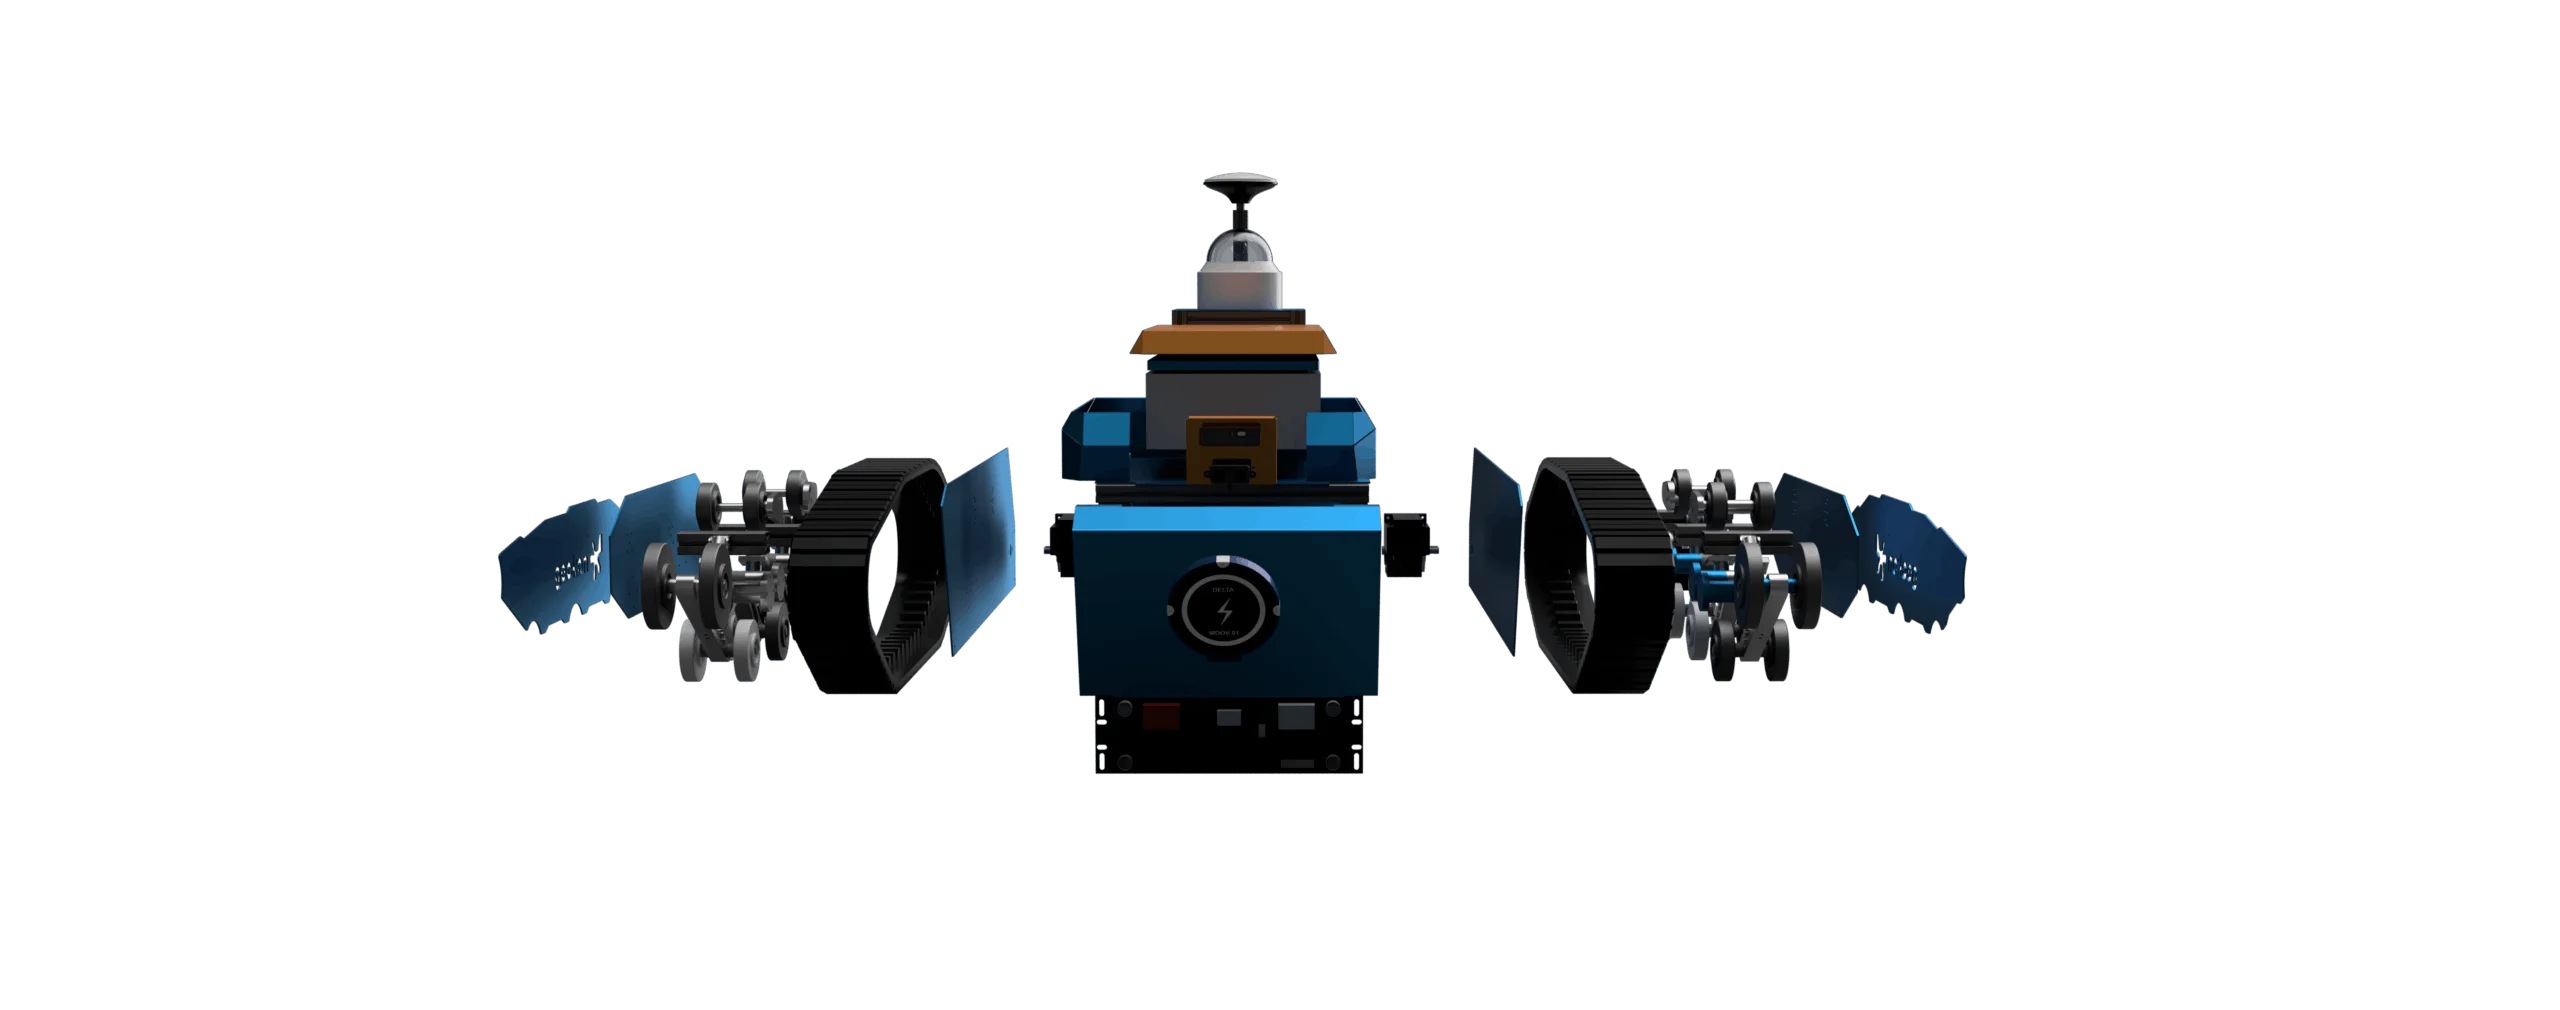
ENGINEERING ANATOMY

01
The Ideation

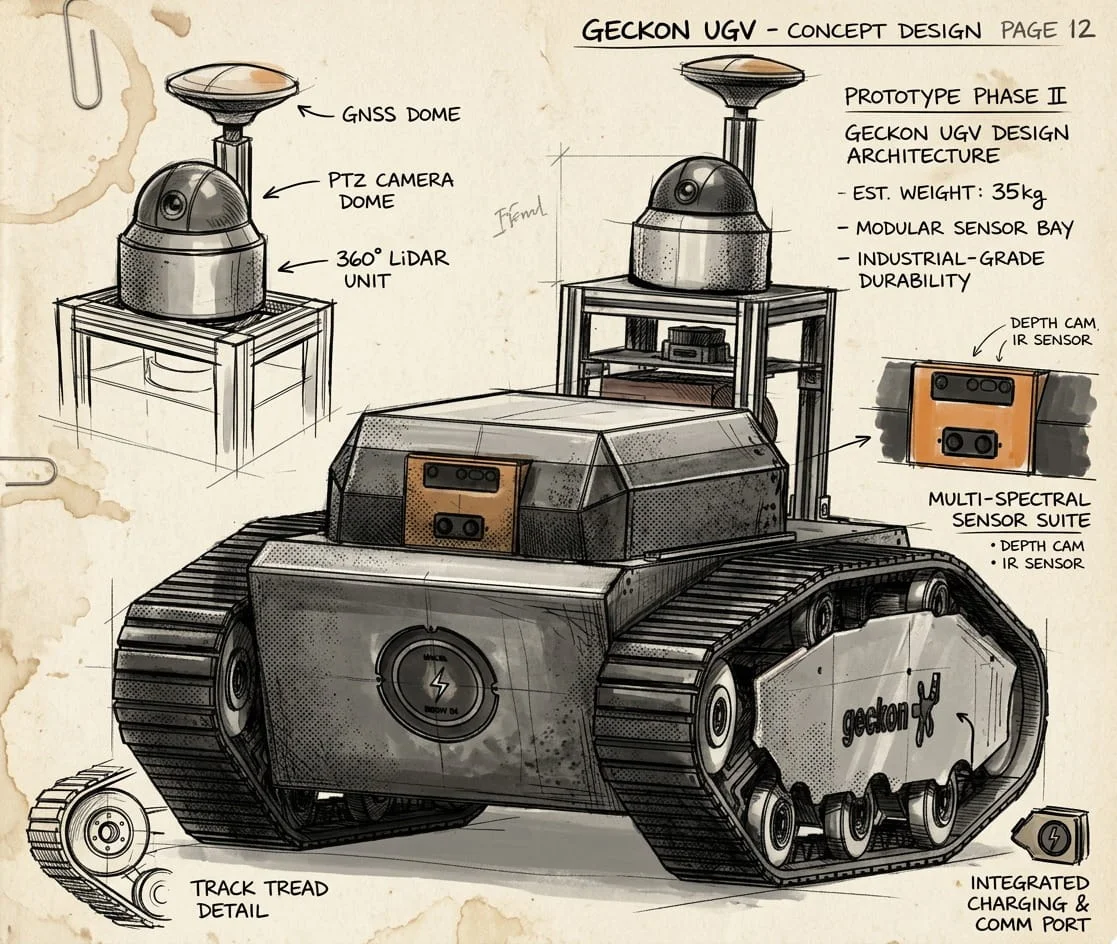
CONCEPT
SKETCHING

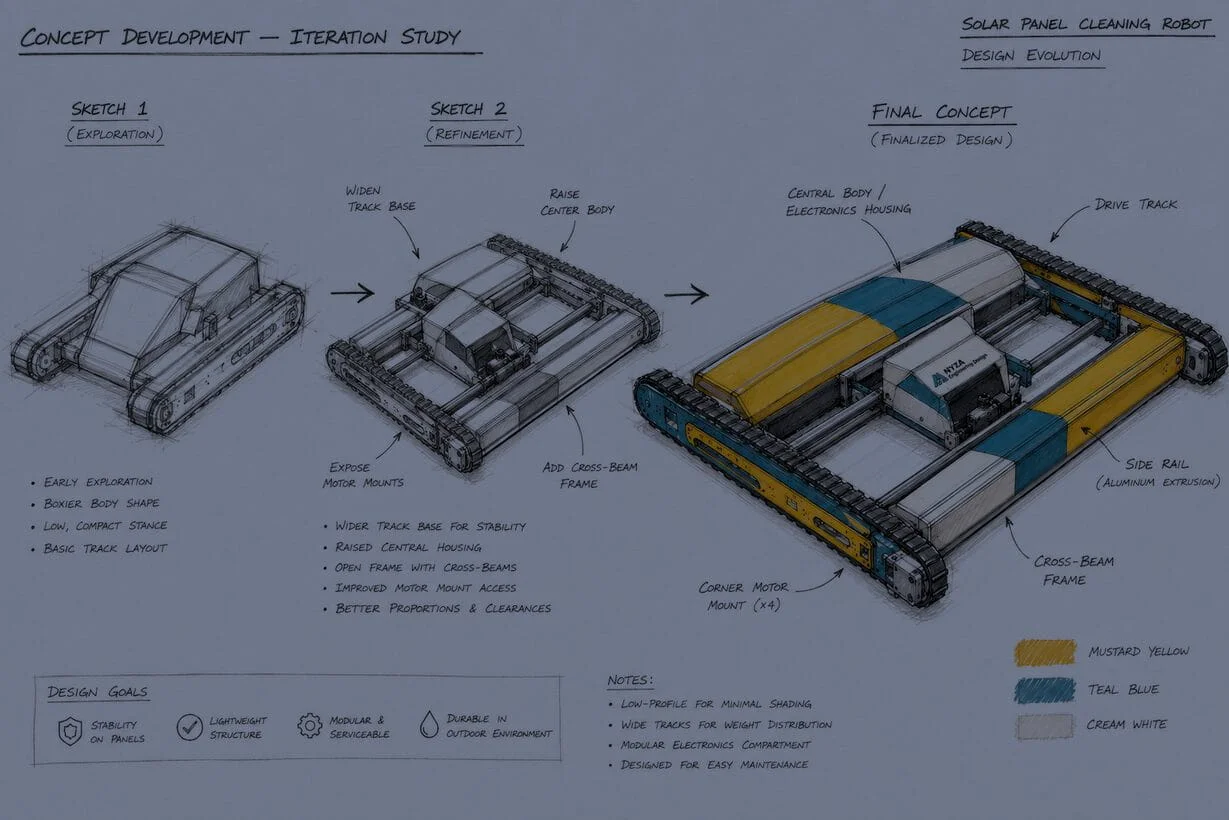
Translating abstract requirements into tangible geometry. We iterated through 40+ track designs to achieve the perfect 45° approach angle for vertical obstacles.

WORKSHOP_MOMENT
WORKSHOP_MOMENT
WORKSHOP_MOMENT
WORKSHOP_MOMENT
WORKSHOP_MOMENT
WORKSHOP_MOMENT
WORKSHOP_MOMENT
The Proof

DESIGN
VALIDATION

Simulating extreme environments. Using FEA, we optimized structural ribbing to withstand 5x impact loads while shedding 15% unnecessary weight.

WORKSHOP_MOMENT
03
The Materialization

FABRICATION
& ASSEMBLY

WORKSHOP_MOMENT
WORKSHOP_MOMENT
WORKSHOP_MOMENT
WORKSHOP_MOMENT
WORKSHOP_MOMENT
WORKSHOP_MOMENT
WORKSHOP_MOMENT
WORKSHOP_MOMENT
Drivetrain

High-Torque Belts

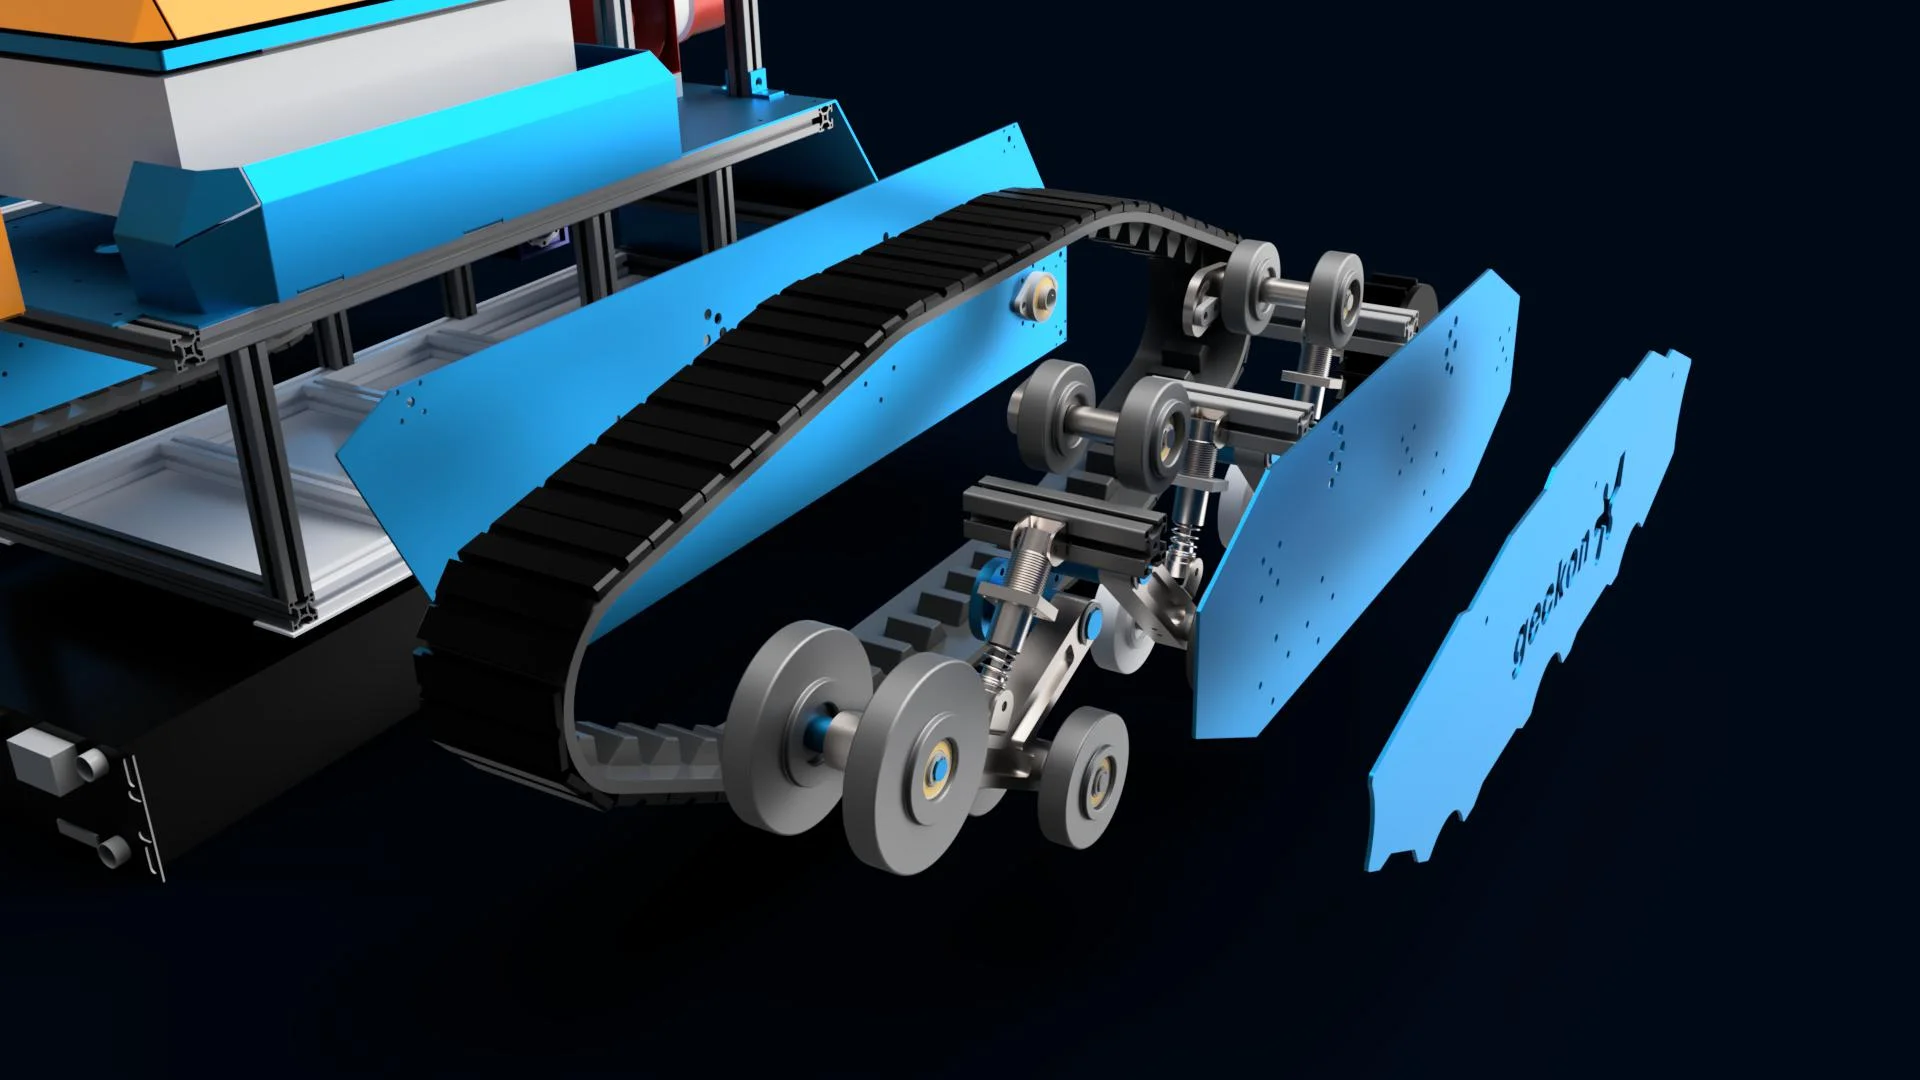
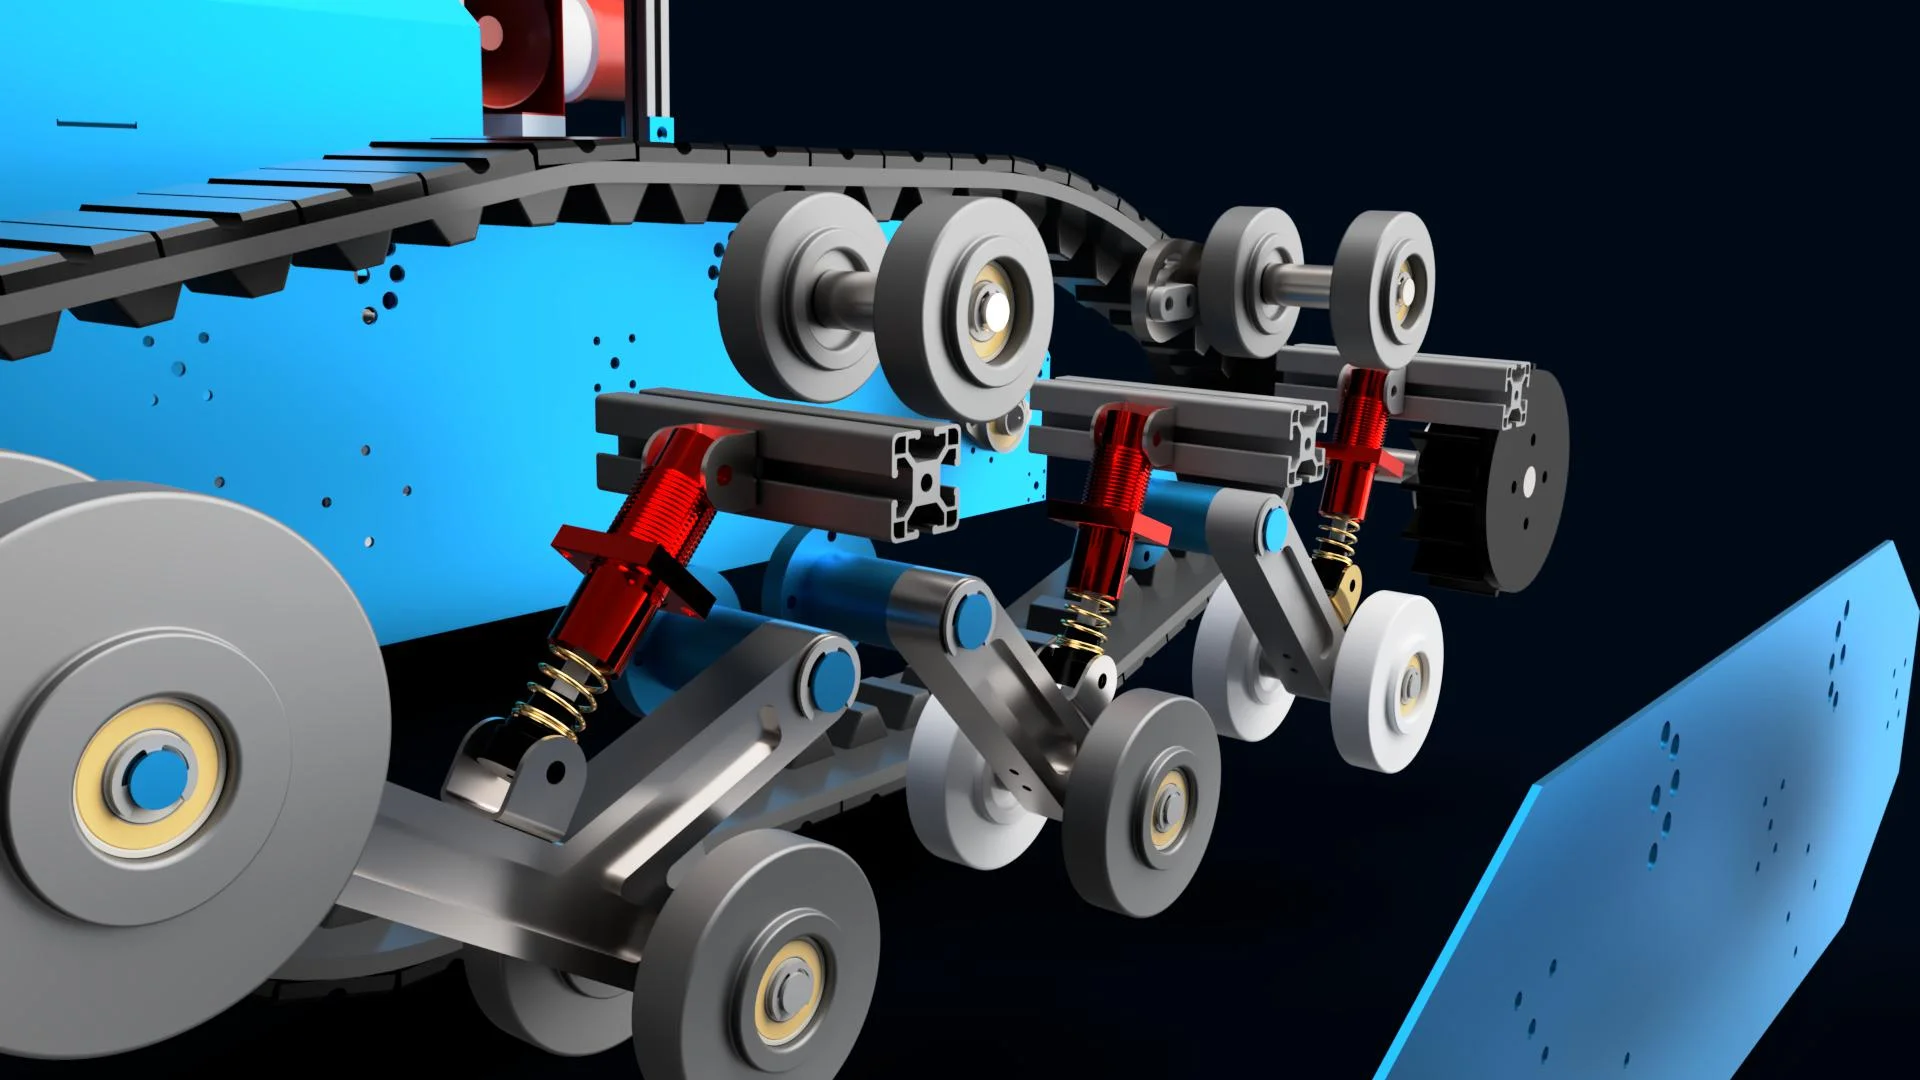
Carbon-fiber reinforced track system designed for 450N of pulling force.

Housing

Aesthetic Enclosure

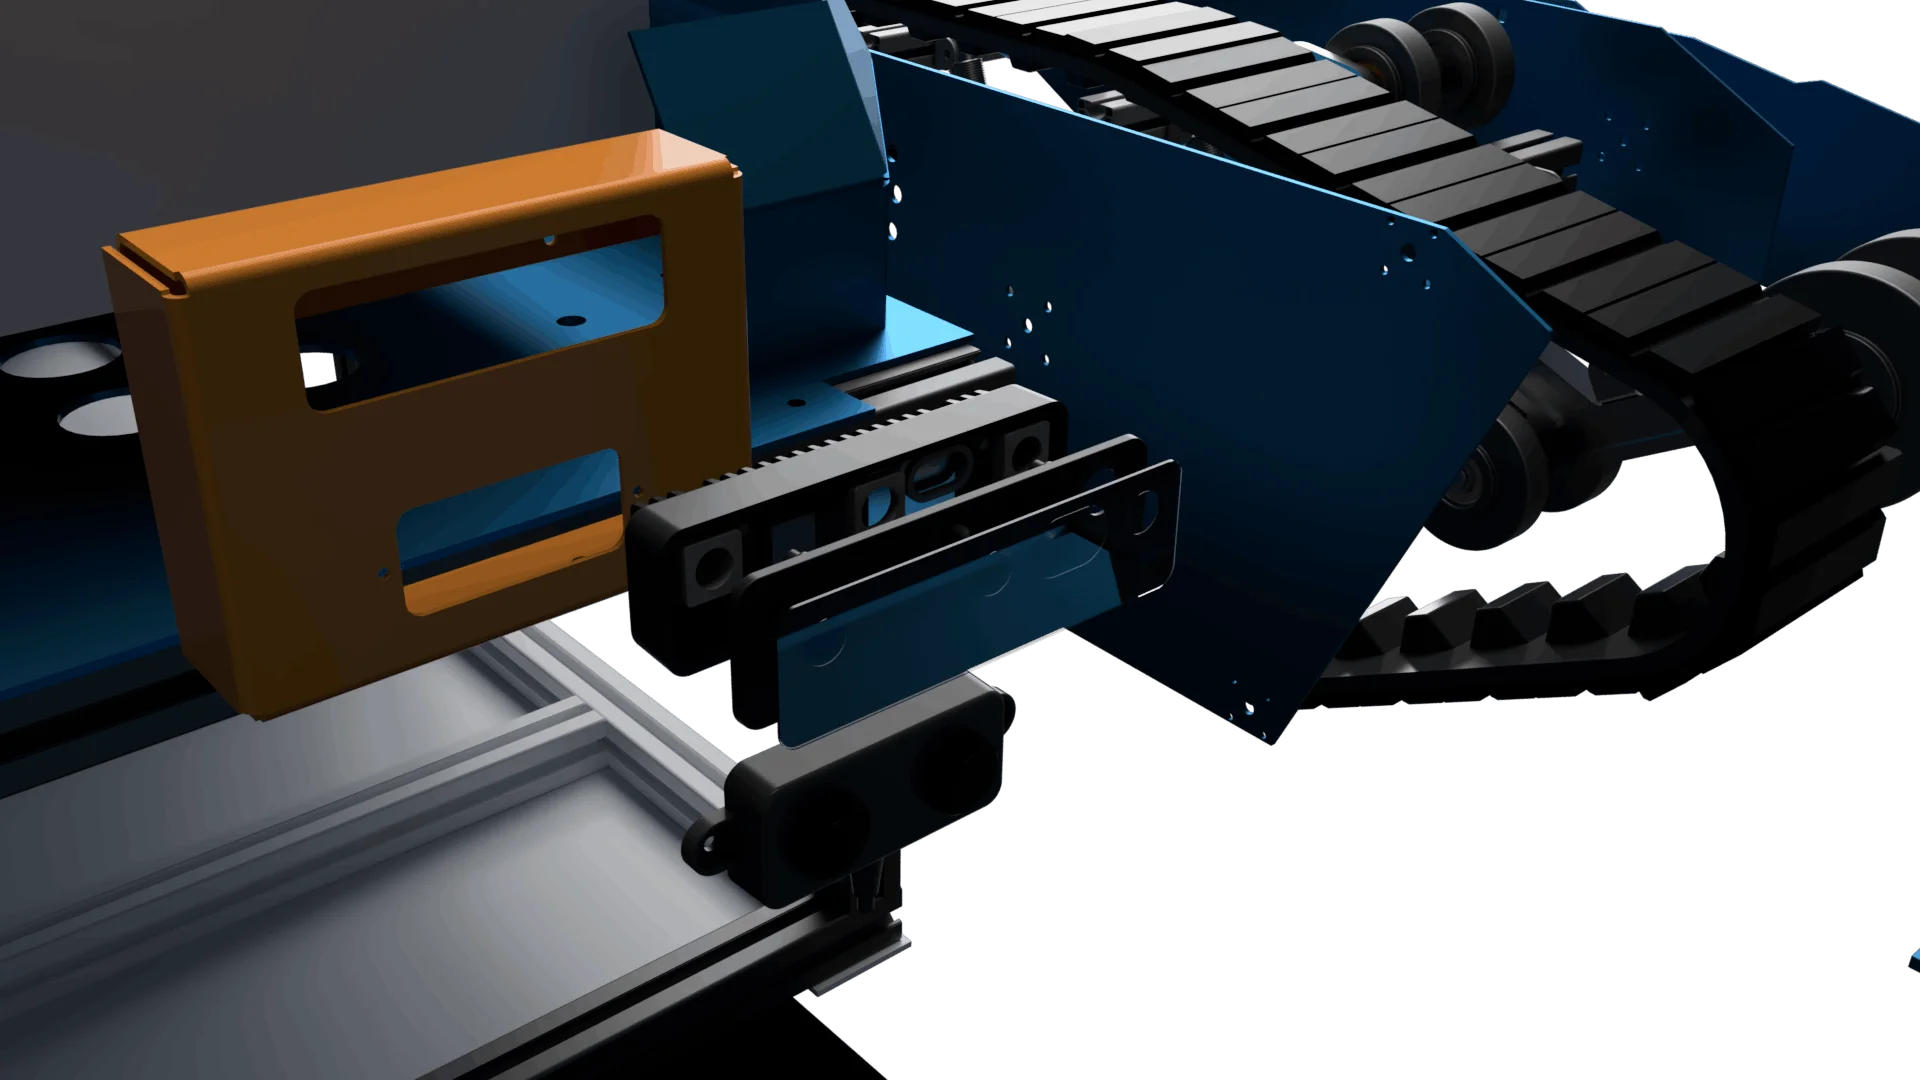
3D-printed impact-resistant polymer with integrated cooling vents and sensor mounts.

WORKSHOP_MOMENT
01_CHASSIS
WORKSHOP_MOMENT
02_TRANSMISSION
WORKSHOP_MOMENT
03_VISION
WORKSHOP_MOMENT
04_SUSPENSION
The Nervous System

SYSTEM INTEGRATION

04

HARDWARE
& SENSORS

The Titan's perception layer is a symphony of high-precision instruments. From the 360° Lidar to dual-depth cameras, every component is ruggedized for industrial vibration.

"The sensor suite provides a 20m safety radius with sub-centimeter obstacle detection."

WORKSHOP_MOMENT
DEPTH_CAMERA_ARRAY
IMU_STABILIZATION_MODULE
DEPTH_CAMERA_ARRAY
WORKSHOP_MOMENT
Power_Bus_Integration
05
The Architecture

ASSEMBLY
& CIRCUITS

Mapping the electrical nervous system. We designed high-current bus bars and logic routing to minimize EMI and maximize power efficiency across the 48V rail.

ACTUATION
TESTING

Validating the motor-drive synergy under maximum load.

MOTOR_DYNO_FEED
01_TORQUE_CURVE
THERMAL_SCOPE_IMG
02_THERMAL_PROFILING
BATTERY_STRESS_IMG
03_VOLTAGE_DROP
OSCILLOSCOPE_PHASE_A
04_PWM_STABILITY

FINAL VALIDATION

A rigorous 72-hour burn-in phase. Every motor controller and sensor node is validated before software handoff.

0.1ms Bus Latency
PASS Load Test
42°C Thermal Peak
100% Node Sync

// Initializing Nav2 Stack...

lifecycle_manager_navigation: Creating node

Success: Global Costmap Loaded

target_pose: [45.2, -12.4, 0.0]

_

RVIZ_POINTCLOUD_FEED

THE AUTONOMOUS BRAIN

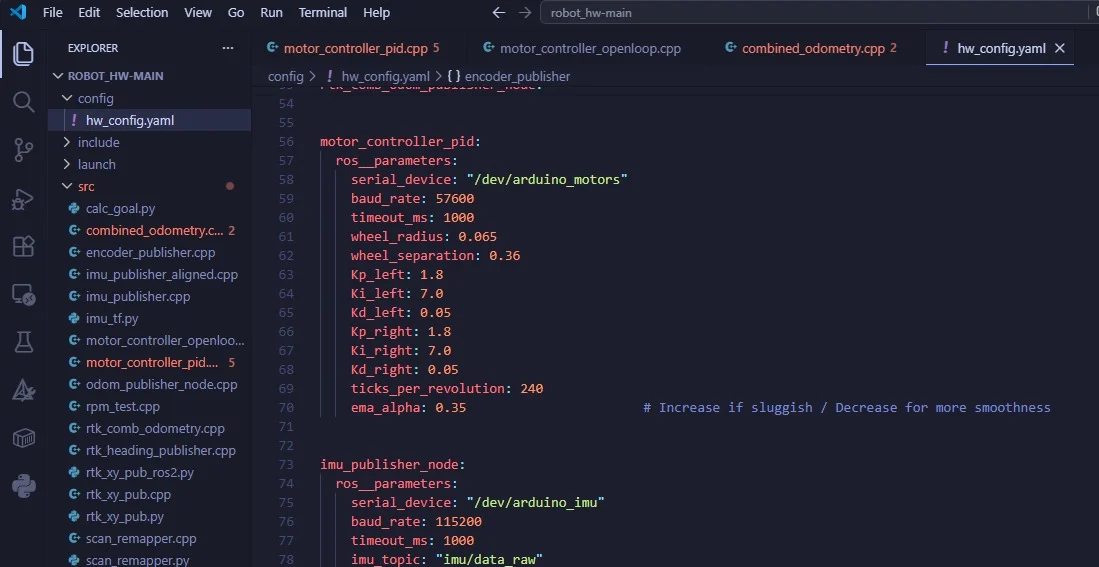
ROS 2 Orchestration

Real-time node communication ensuring zero latency between perception and action.

AI Depth Perception

Utilizing stereo-vision and depth-sensing arrays to identify obstacles and terrain textures in real-time.

PTZ Intruder Detection

Integrated 25x optical zoom with automated computer vision for threat identification and tracking.

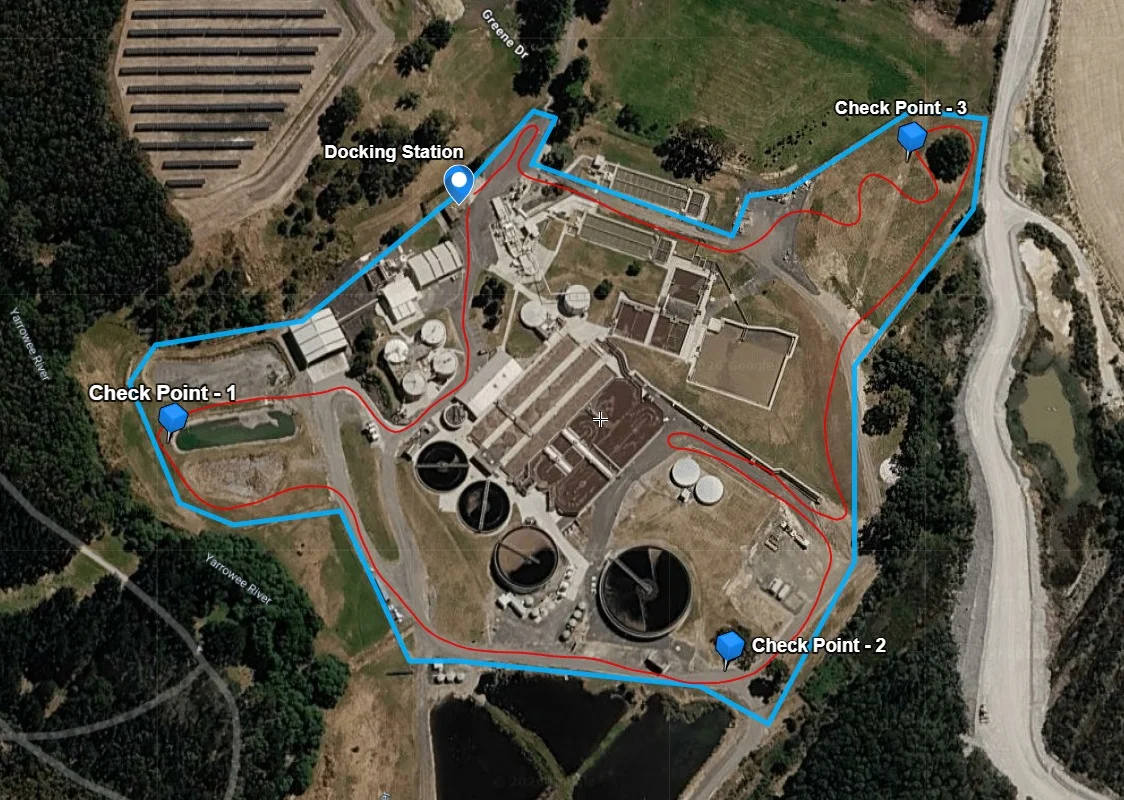
RTK Precision Docking

Centimeter-level accuracy using Real-Time Kinematics for seamless automated charging and deployment.

Human-Free Endurance

Designed for 24/7 autonomous operation with self-diagnostic health monitoring and auto-recovery.

Global Cloud Mesh

Secure worldwide connectivity and remote development via Zenoh and Tailscale integration.

The Technical Edge

PRECISION ENGINEERING

06

SLAM
& SPATIAL MAPPING

The digital twin of reality. We generate high-fidelity spatial data using a proprietary SLAM stack optimized for complex industrial layouts.

Environmental Mapping

Creating the foundation. We utilize 360° Lidar scans fused with odometry to generate precise occupancy grids, remapping scan angles to filter out noise and industrial debris.

2D_OCCUPANCY_GRID_RAW

Path Navigation

Orchestrating the mission. Integrating the ROS 2 Nav2 stack with dynamic path planners that adapt to moving obstacles and varying floor conditions in real-time.

GLOBAL_PATH_PLANNER_VIEW

Parameter Optimization

The precision layer. We fine-tuned inflation layers and footprint clearance to ensure the 45KG Titan navigates tight industrial gaps with zero contact.

INFLATION_LAYER_CALIBRATION
07
Geo-Spatial Precision

RTK INTEGRATION

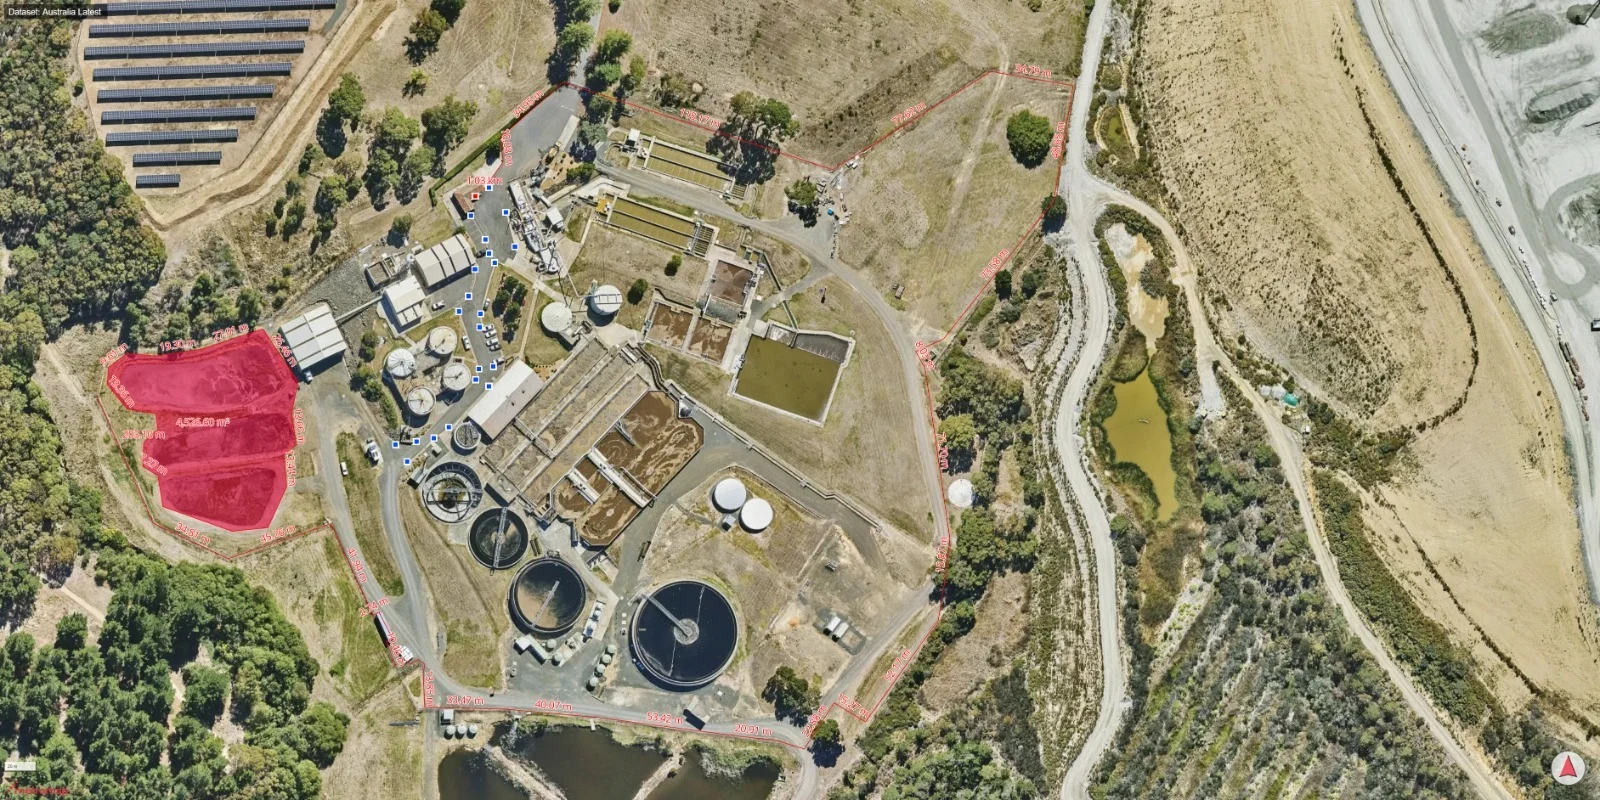
Breaking the meter barrier. By utilizing Real-Time Kinematics, we achieved centimeter-level positioning, enabling auto-docking and precise survey-grade mapping.

RTK Fixed (Centimeter)

Base Station Setup

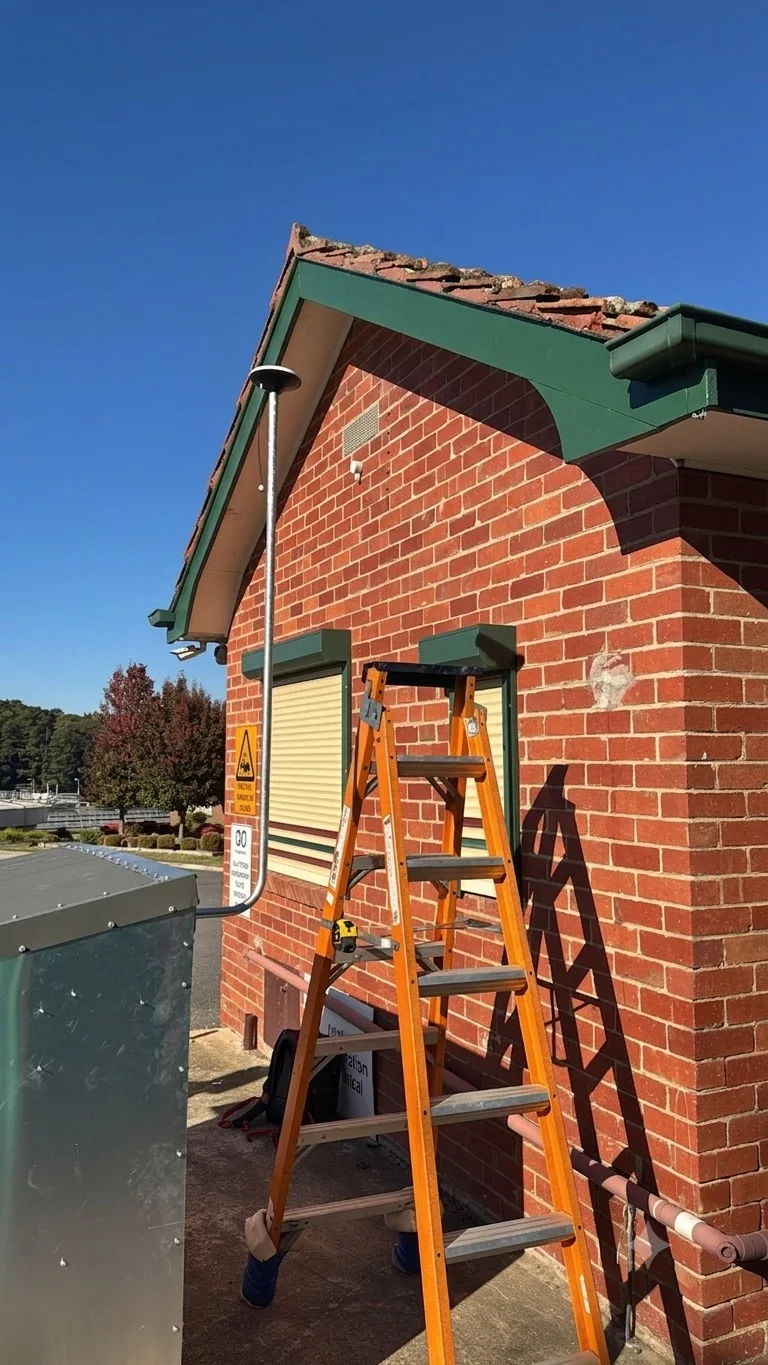
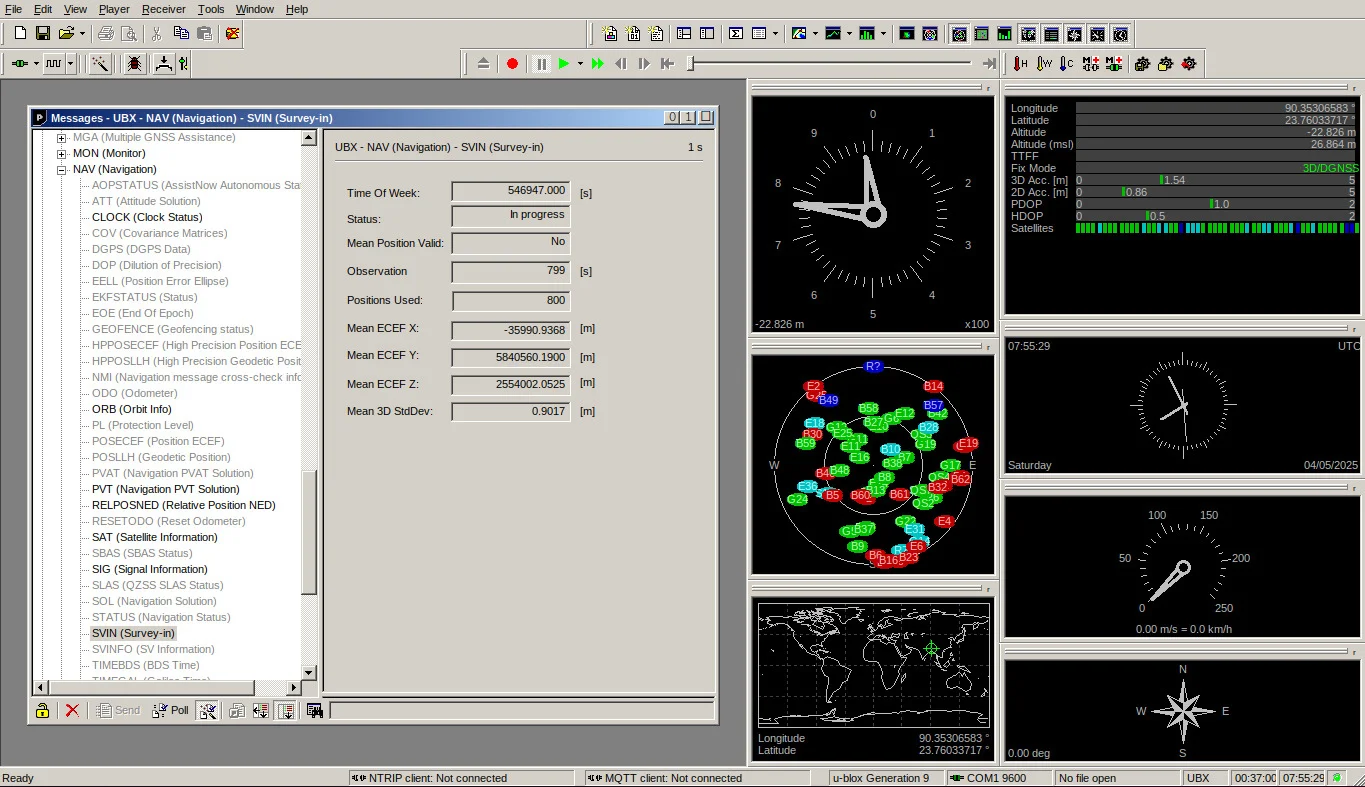
Surveying the fixed truth. We establish sub-centimeter coordinates through long-duration GNSS averaging, providing the absolute reference point for the entire local network.

RTK_BASE_SYNC_DATA

Centimeter Navigation

Dynamic Precision. By calculating real-time phase corrections, Titan achieves 1.5cm repeatability in waypoint following, enabling autonomous docking and high-speed navigation.

RTK_FIX_PATH_TRACKING
TITAN
Field Ready

AUTONOMY
IS HERE.

From initial sketch to industrial deployment. The final Titan production model is the culmination of 2,400+ hours of testing across four climate zones.

Final production hero frontFINAL_PRODUCTION_HERO_FRONT
Production detail tracksPRODUCTION_DETAIL_TRACKS
Titan in rain testTITAN_IN_RAIN_TEST
FLEET_DEPLOYMENT_SHOT
Multi-Agent

Fleet Coordination

LOW_LIGHT_OPERATION_SHOT
24/7 Ops

Midnight Patrol

98% Precision
0.5s Reaction
500km Test Range
IP67 Ingress