Custom Mobile Robotics
HOW WE BUILT A 6WD ROBOT ON A BUDGET
A custom six-wheel-drive mobile robot, developed with a practical, budget-conscious approach. Watch the build, then explore the platform and engineering focus.
Flagship build video · 6-wheel-drive mobile robot
The project
A mobile platform built around the mission
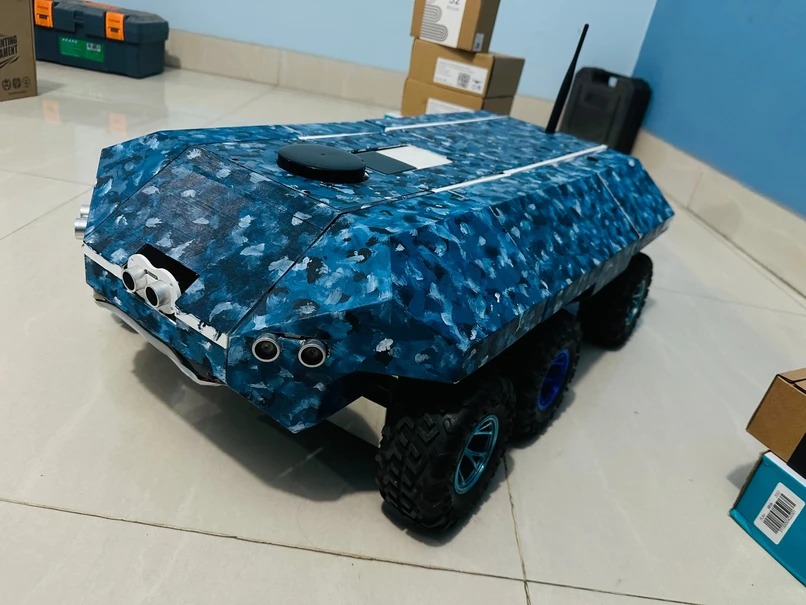
The project video documents the design and build of a custom 6WD robot, with an emphasis on creating a capable mobile platform while keeping the build budget-conscious.
The project brief describes a remotely operable ground robot integrating ROS 2, LiDAR, depth cameras, and IMU sensing. The intended autonomy work includes real-time mapping and navigation, with support for indoor and outdoor SLAM.
Rather than treating the chassis, drivetrain, electronics, and software as separate pieces, the work brings them together as one integrated robotics system.
Six-wheel drive
Budget-conscious build
Mapping & navigation
Mechanical, electrical & software
01 / Mechanical engineering
Six-wheel mobility.
The custom six-wheel-drive chassis forms the physical foundation of the robot.
The project video documents the design and build of this mobile platform with a budget-conscious approach. The chassis and drivetrain are developed as an integrated system, supporting the robot’s mobility while making room for its onboard electronics and sensing hardware.
02 / Electrical engineering
Sensing & integration.
The robot’s electronics connect its drive platform with the sensors it uses to understand its motion and surroundings.
The project brief describes an integrated sensor suite including LiDAR, depth cameras, and an IMU. These components provide environmental and motion data for the robot’s mapping and navigation systems.
03 / Software engineering
Autonomy & control.
ROS 2 provides the software foundation for coordinating the robot’s sensors and mobile behavior.
The project brief describes real-time mapping and navigation, with support for indoor and outdoor SLAM and remote operation. This software layer brings sensor inputs and the physical platform together into a mobile robotics system.
From concept to prototype
The robot, up close
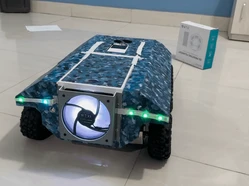
Concept rendering and prototype views from the Wheel Tank project.