SURVEILLANCE ROBOT
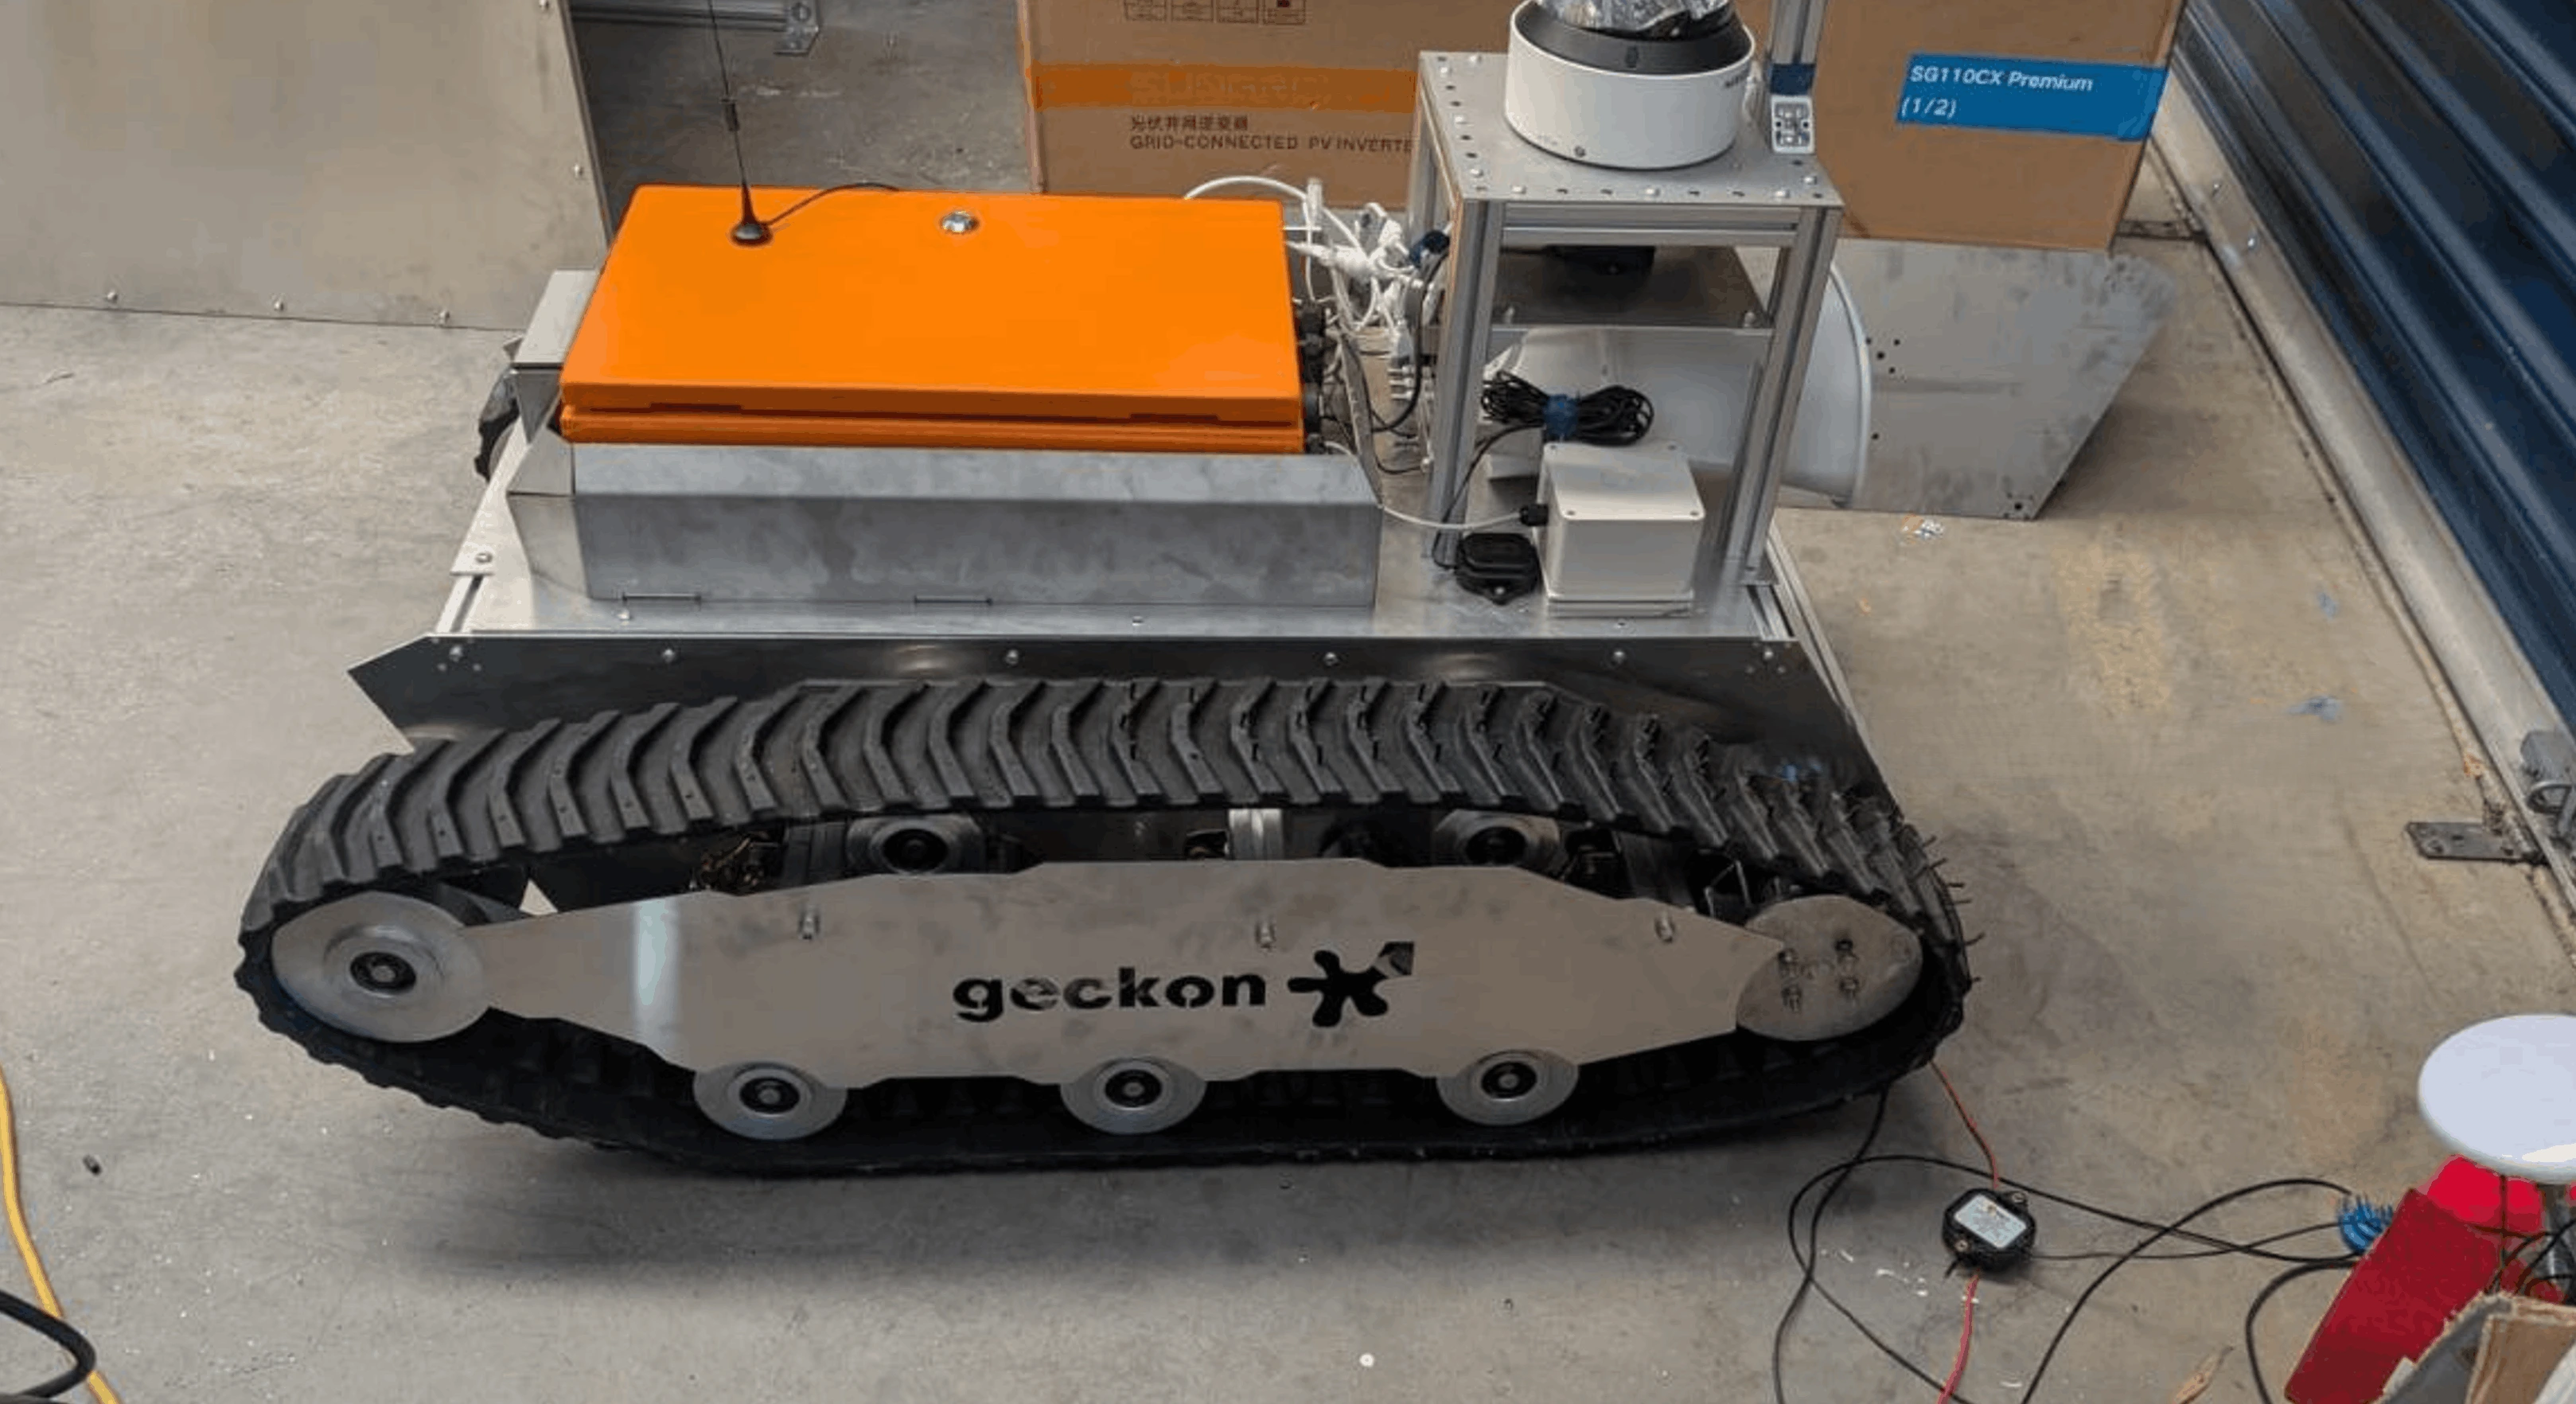
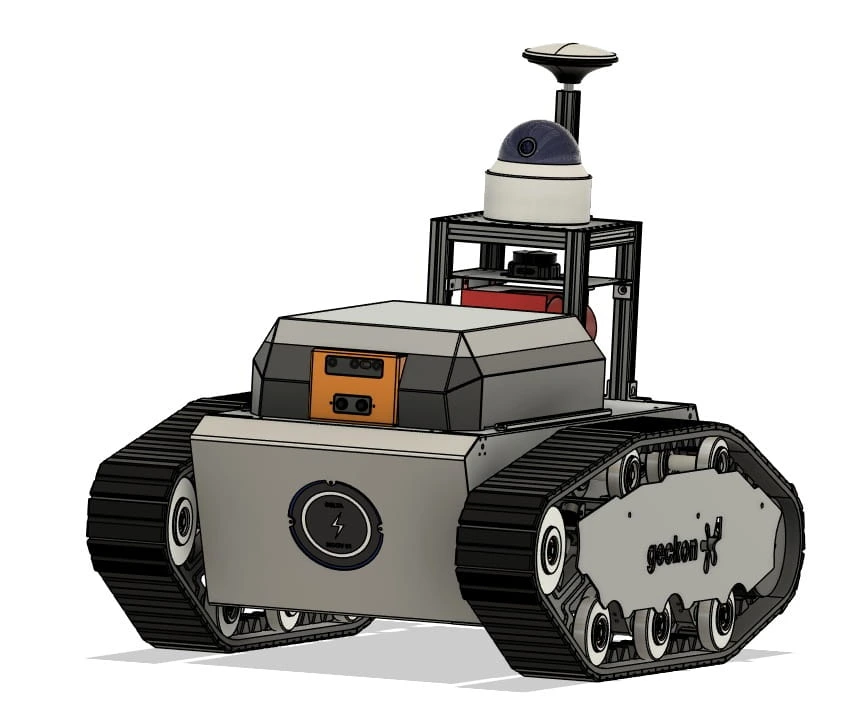
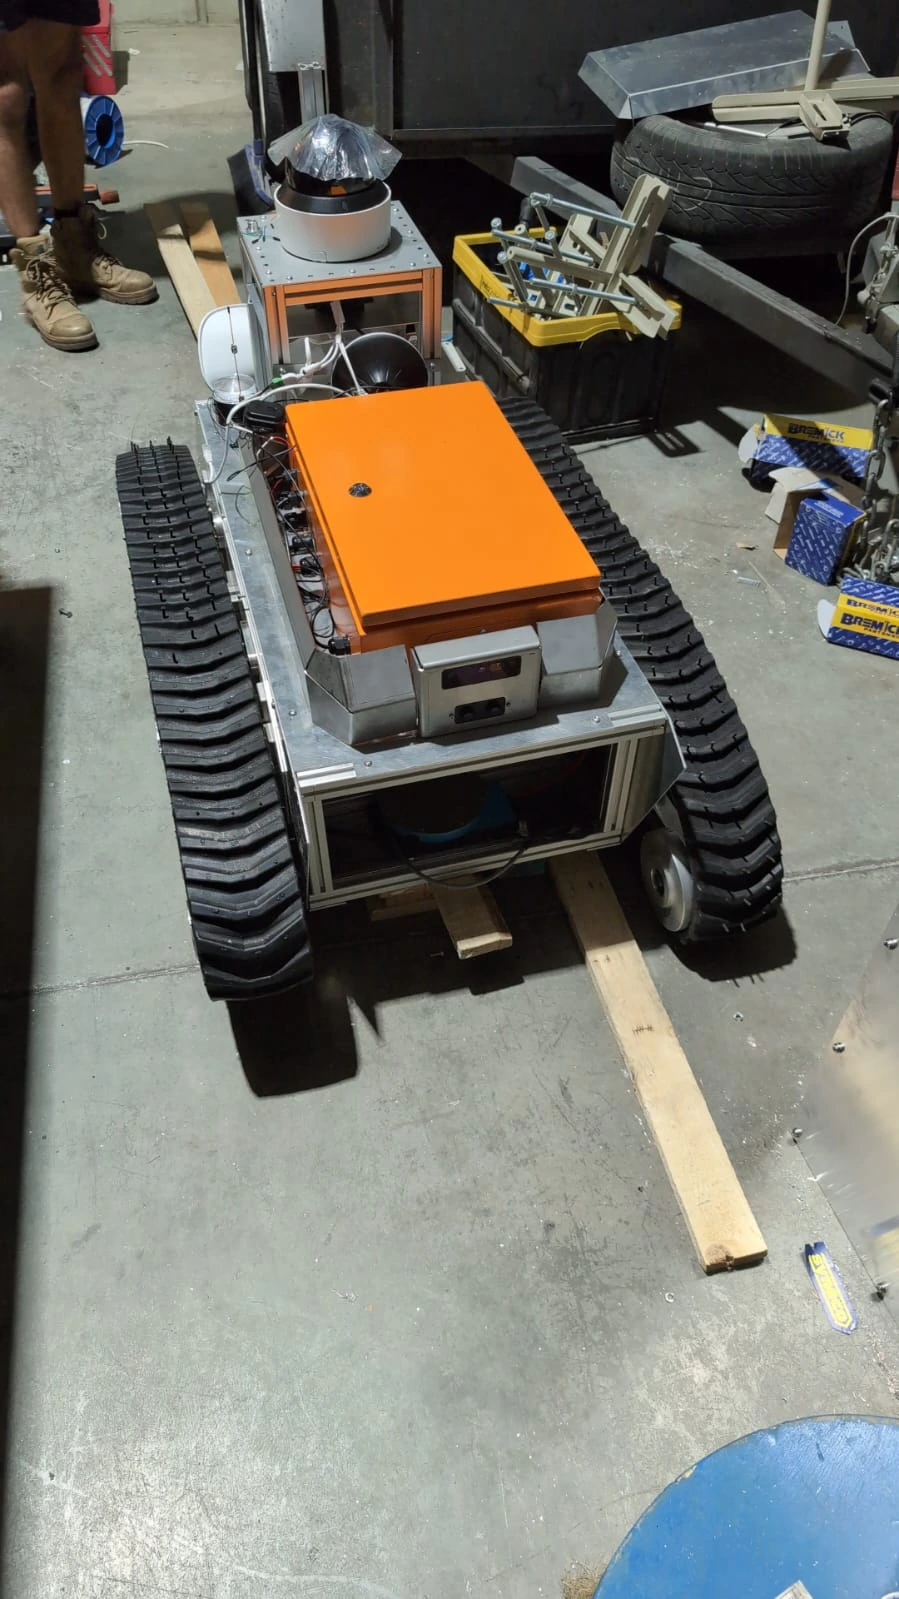
A 45KG autonomous tracked robot built for industrial patrol, using LiDAR and ROS 2 Nav2 to navigate rough terrain and detect threats around the clock.
.webp)
.webp)
BLUE SKY ROBOTIC
A compact and precise robotic arm for assisting surgeons in delicate procedures, with a focus on sterile environments.
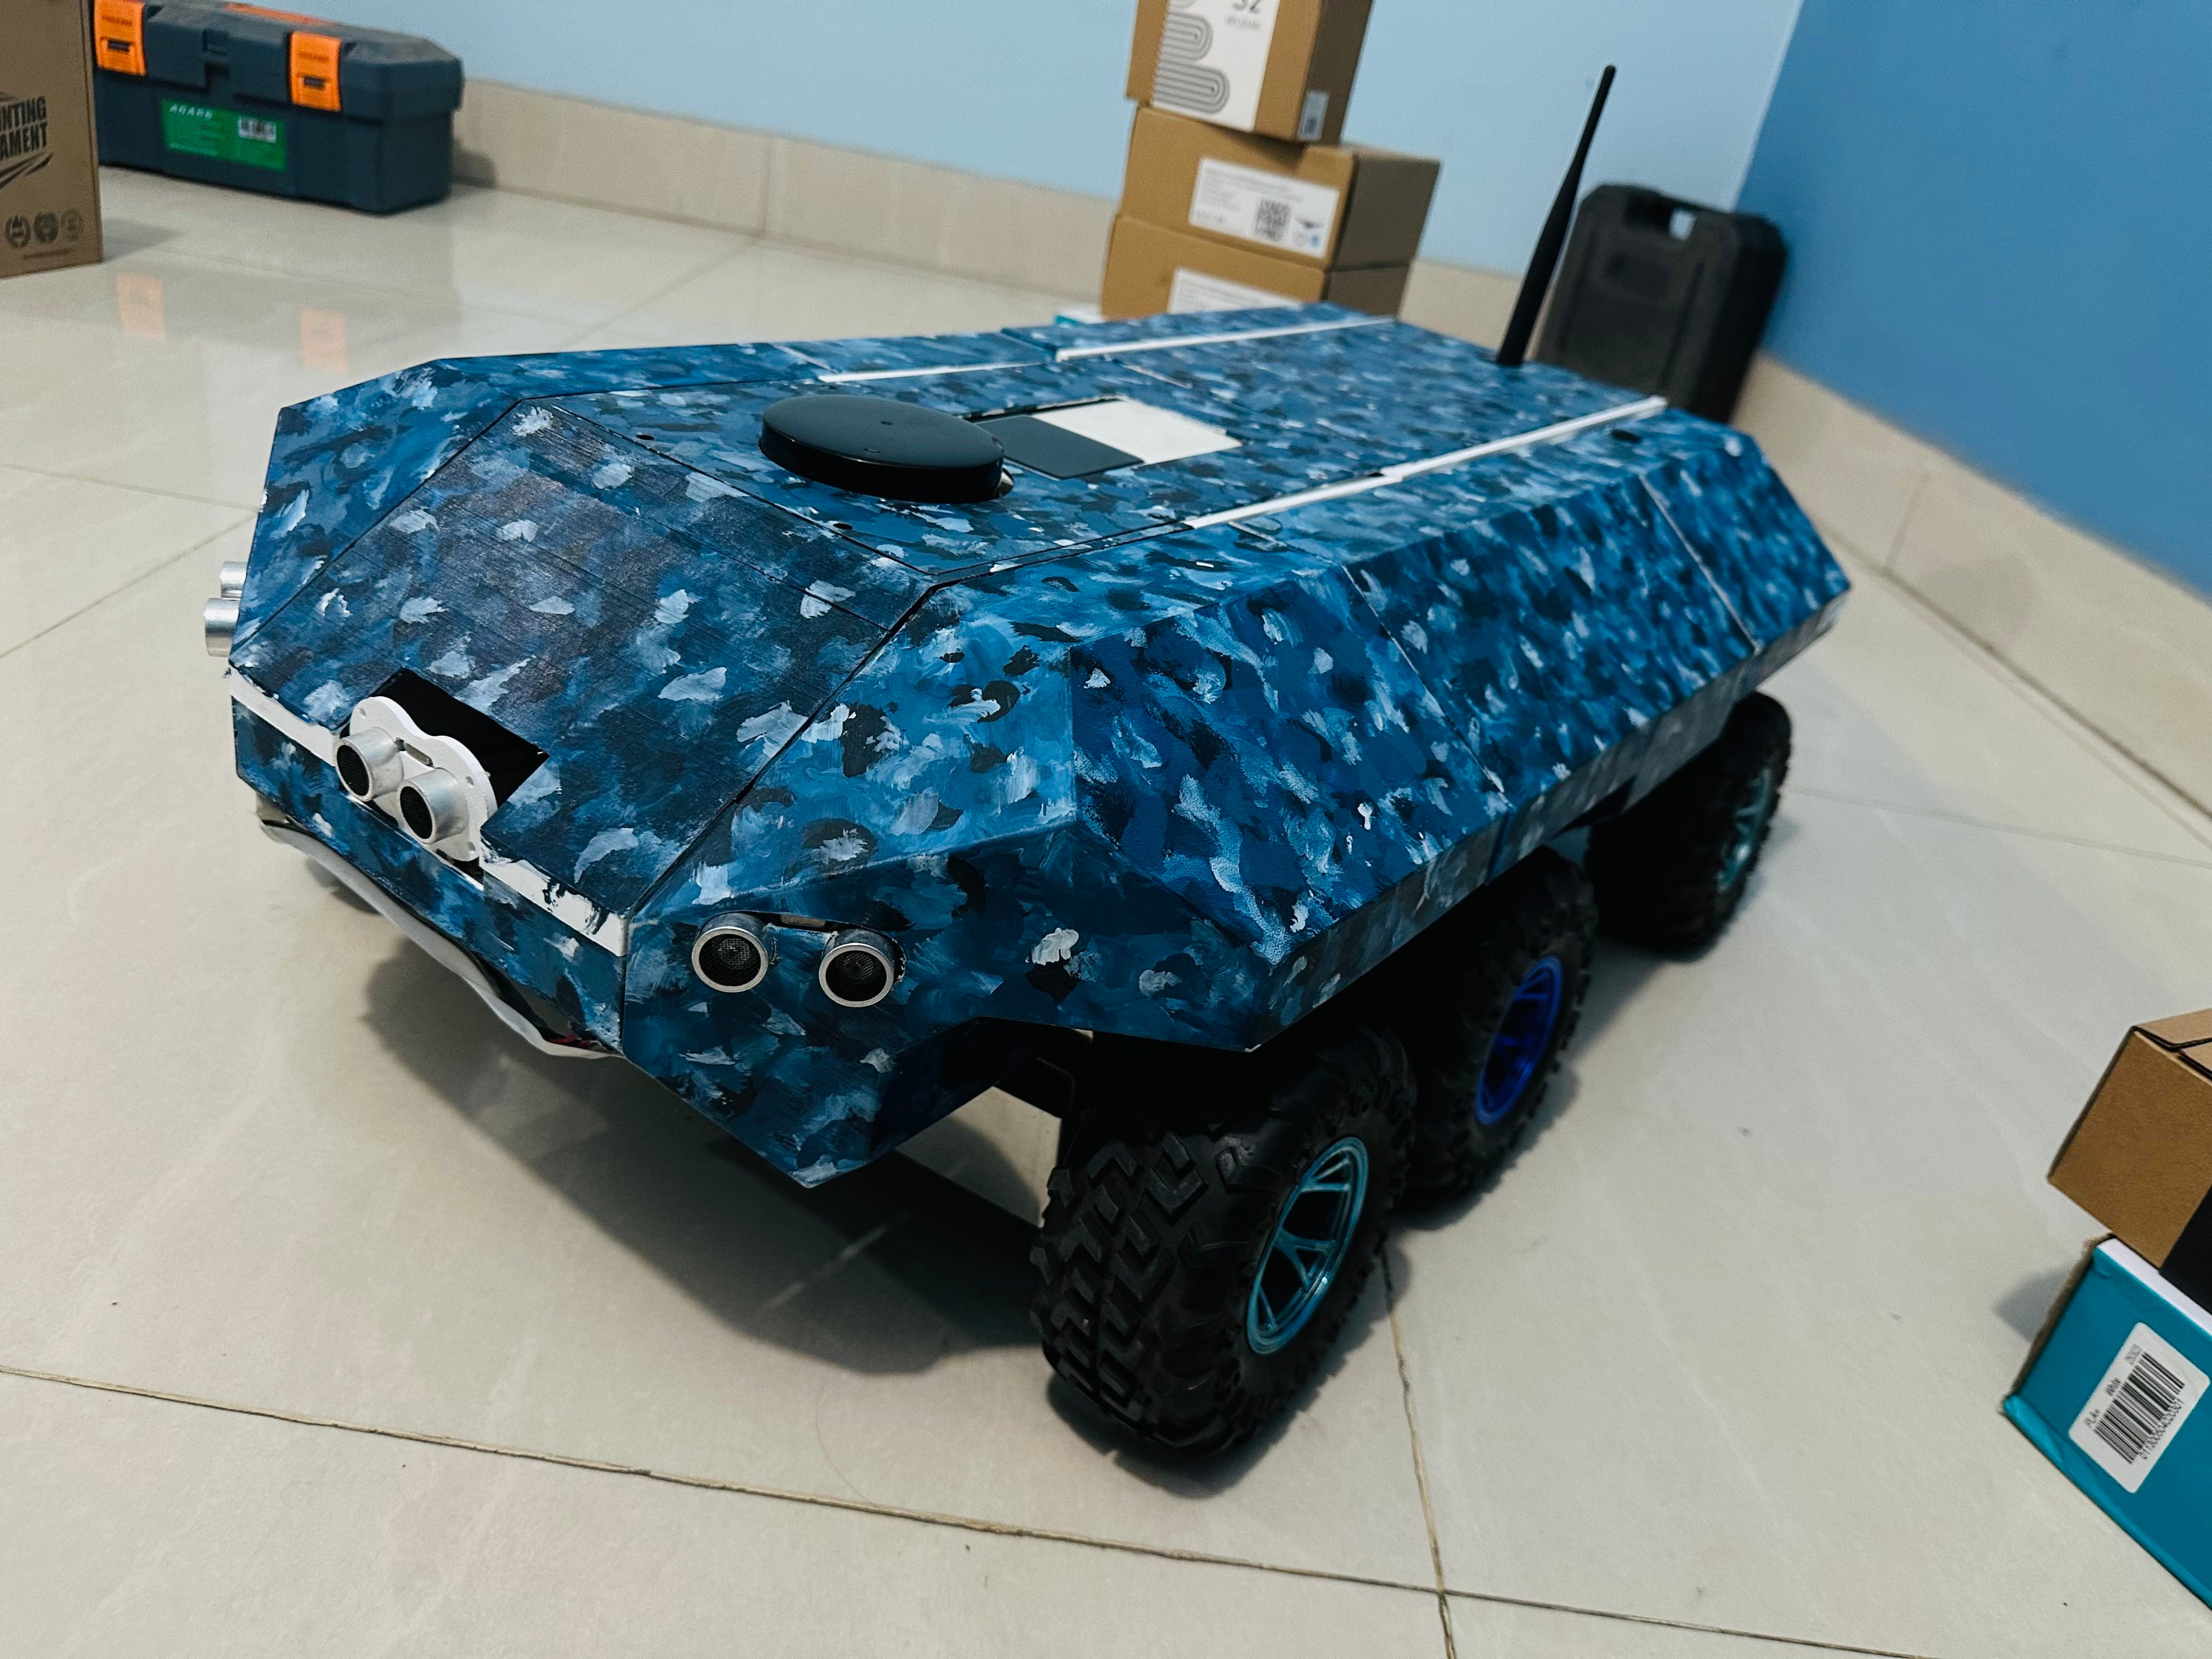
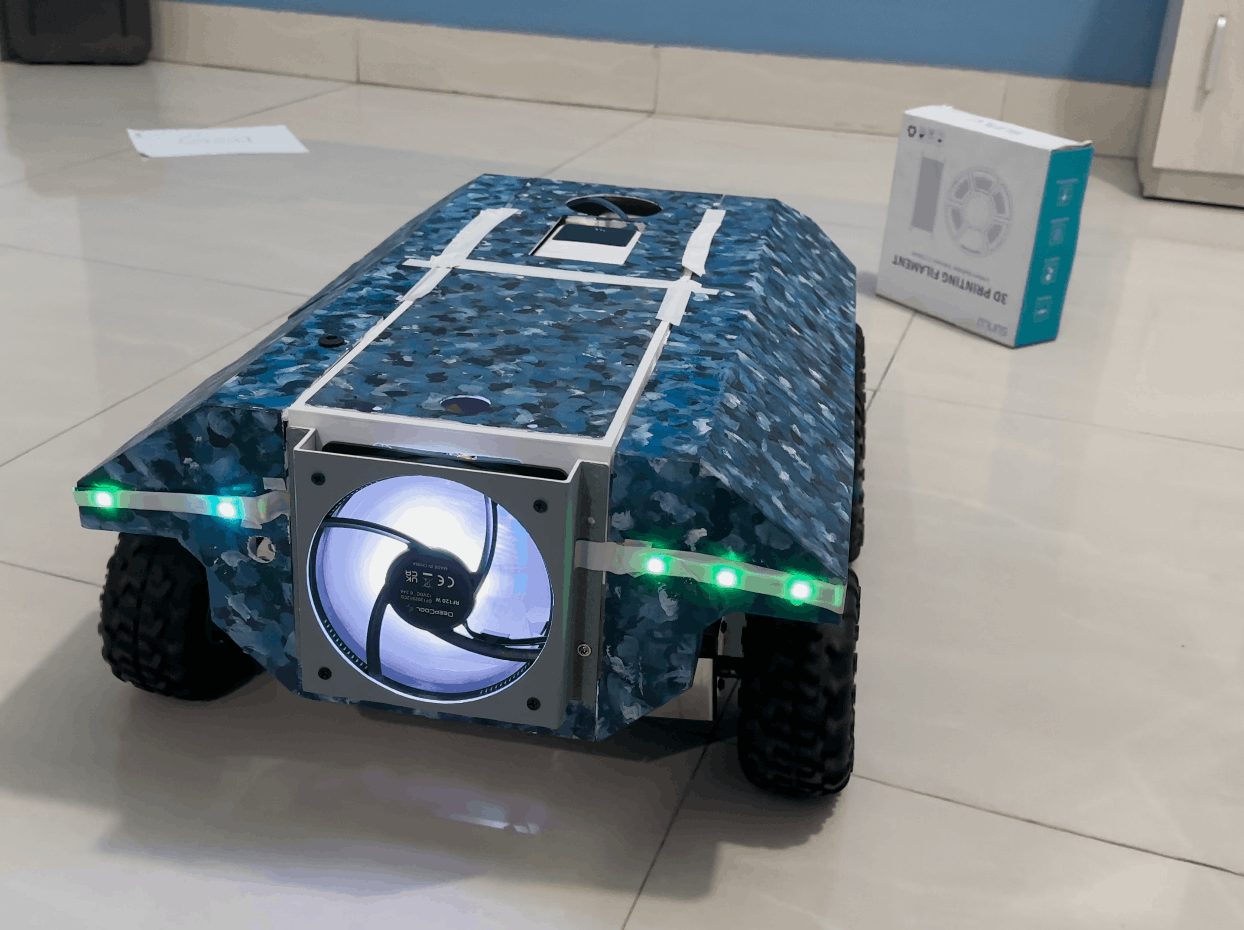
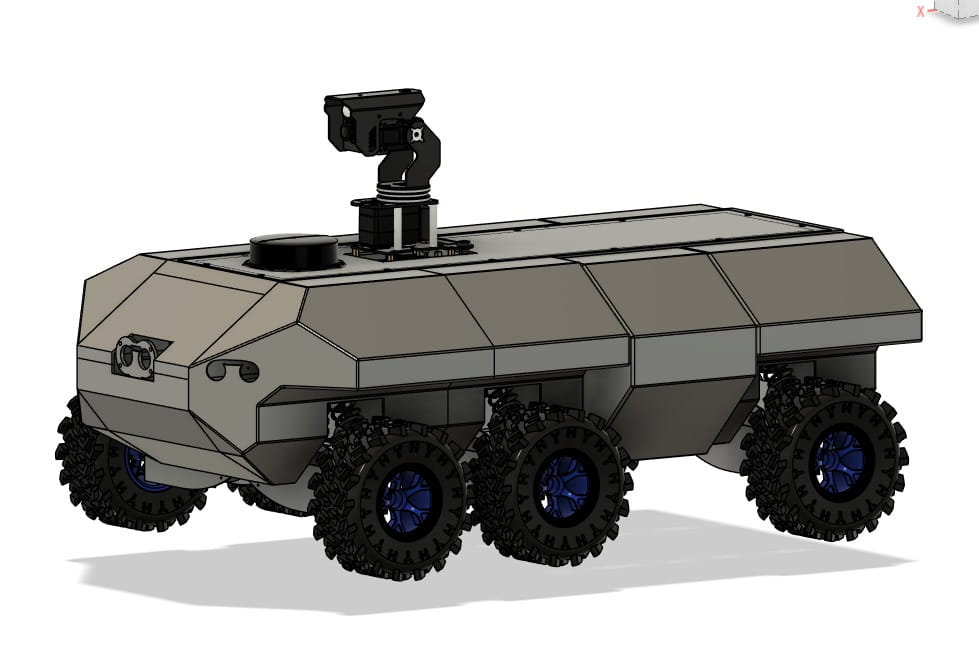
WHEEL TANK SURVEILLANCE ROVER
We designed and implemented a fully autonomous robot for sorting and transporting packages in a large-scale warehouse.
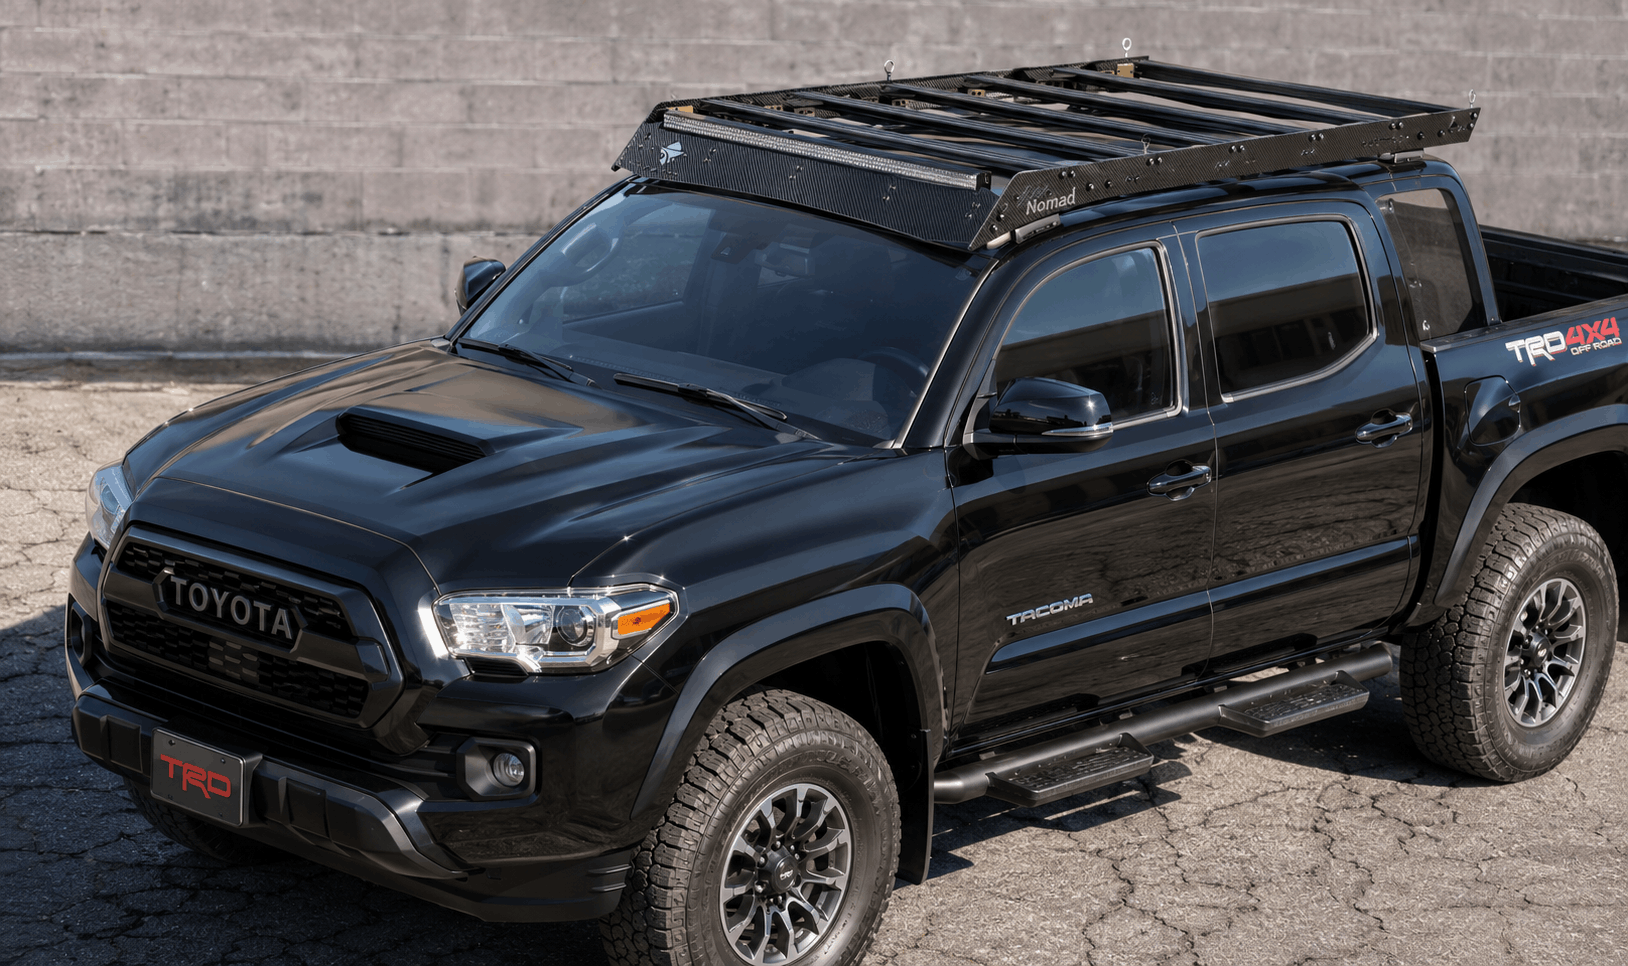
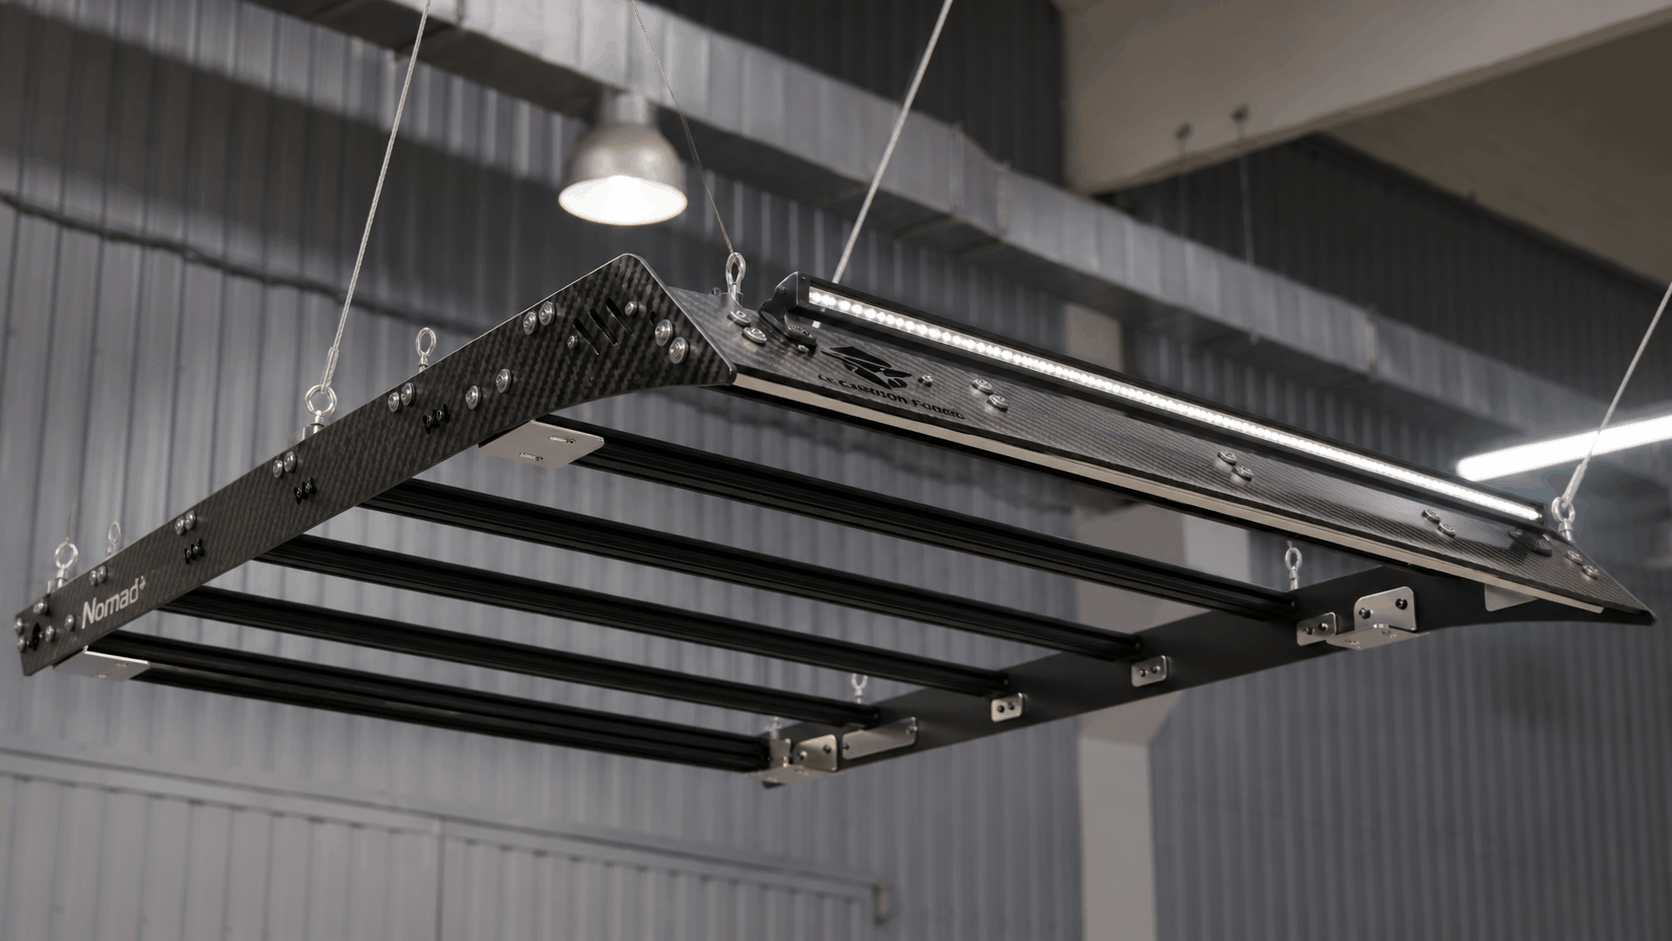
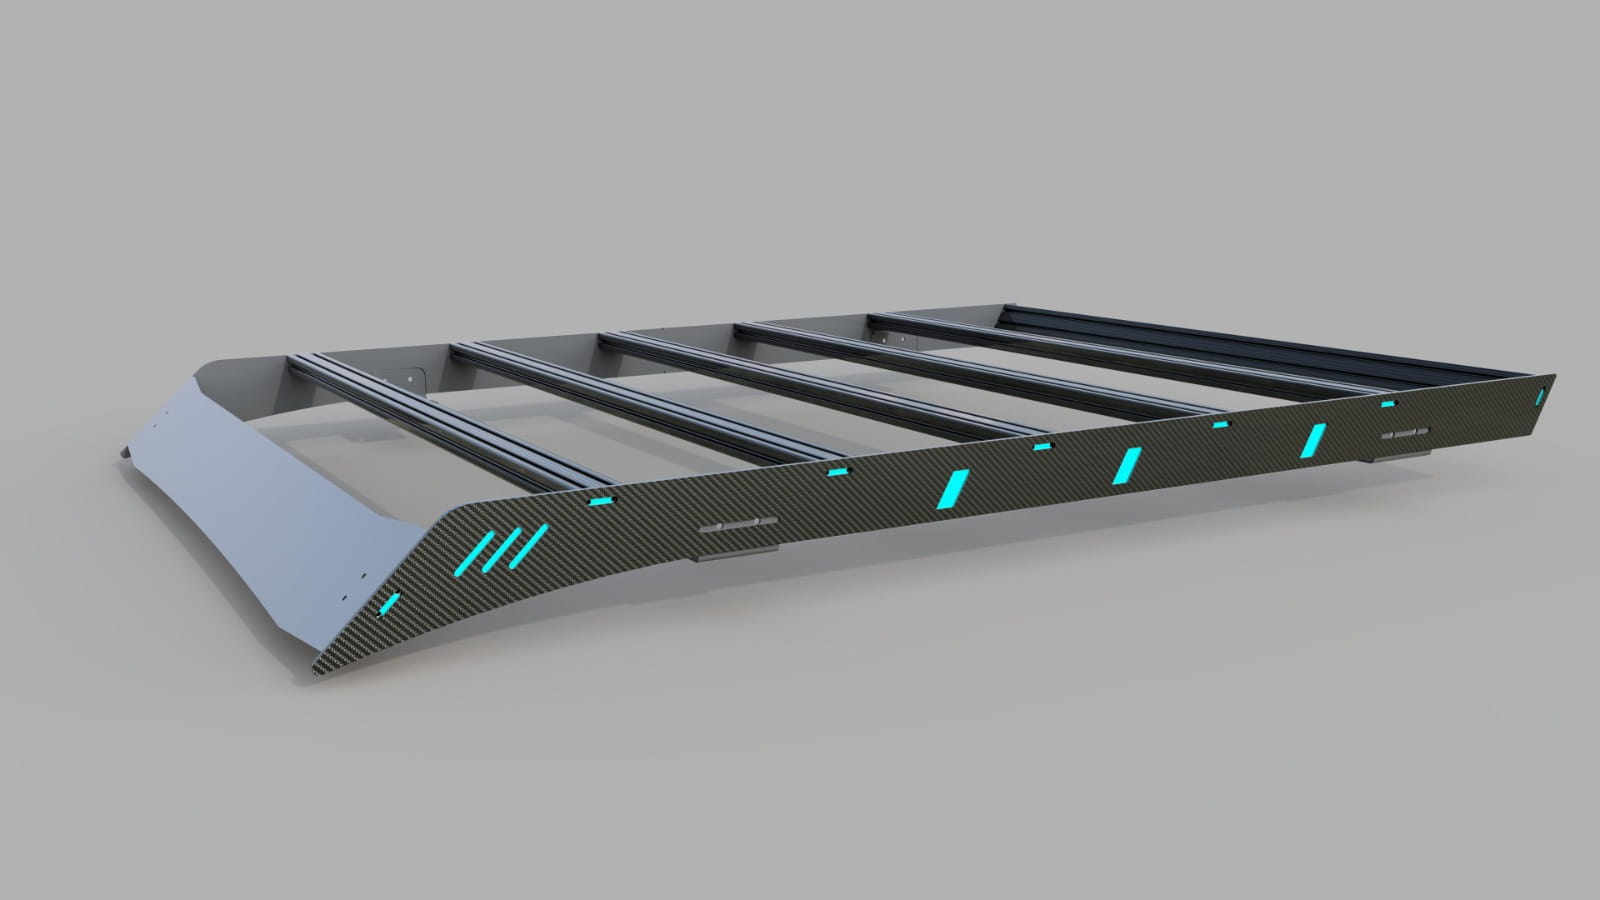
Roof Rack
Fabricated a custom roof rack with welded mounting brackets for a campervan. This project focuses on creating a durable and secure platform for carrying extra items to make an enjoyable camping experience.
.jpg)
.png)
.png)
MINI PV ROBOT V2
An autonomous robot designed for monitoring crop health, precision planting, and targeted pesticide application.
.jpg)
.png)
.jpg)
COMPACT PV CLEANING ROBOT
Develop a solar panel cleaning robot that is lightweight, modular, and easy to deploy. The robot should be divided into five modules, each weighing only 10kg, for convenient transportation and maintenance.
.jpg)
.jpg)
.jpg)
FIRE E POP ROBOT DOG
Design a quadruped robot capable of navigating tight spaces and extinguishing fires remotely. Fire E Pup should be maneuverable and equipped with a heat-resistant water cannon system and CO2 Extinguishers.
.jpg)
.jpg)
SOLAR PANEL CLEANING ROBOT
Designed a mobile robot with all the requirements given by the client and made a lot of modifications based on my experience with robots. All custom parts were built with design for manufacturing considerations.
.jpg)
.jpg)
.jpg)
EGG GRADING SYSTEM
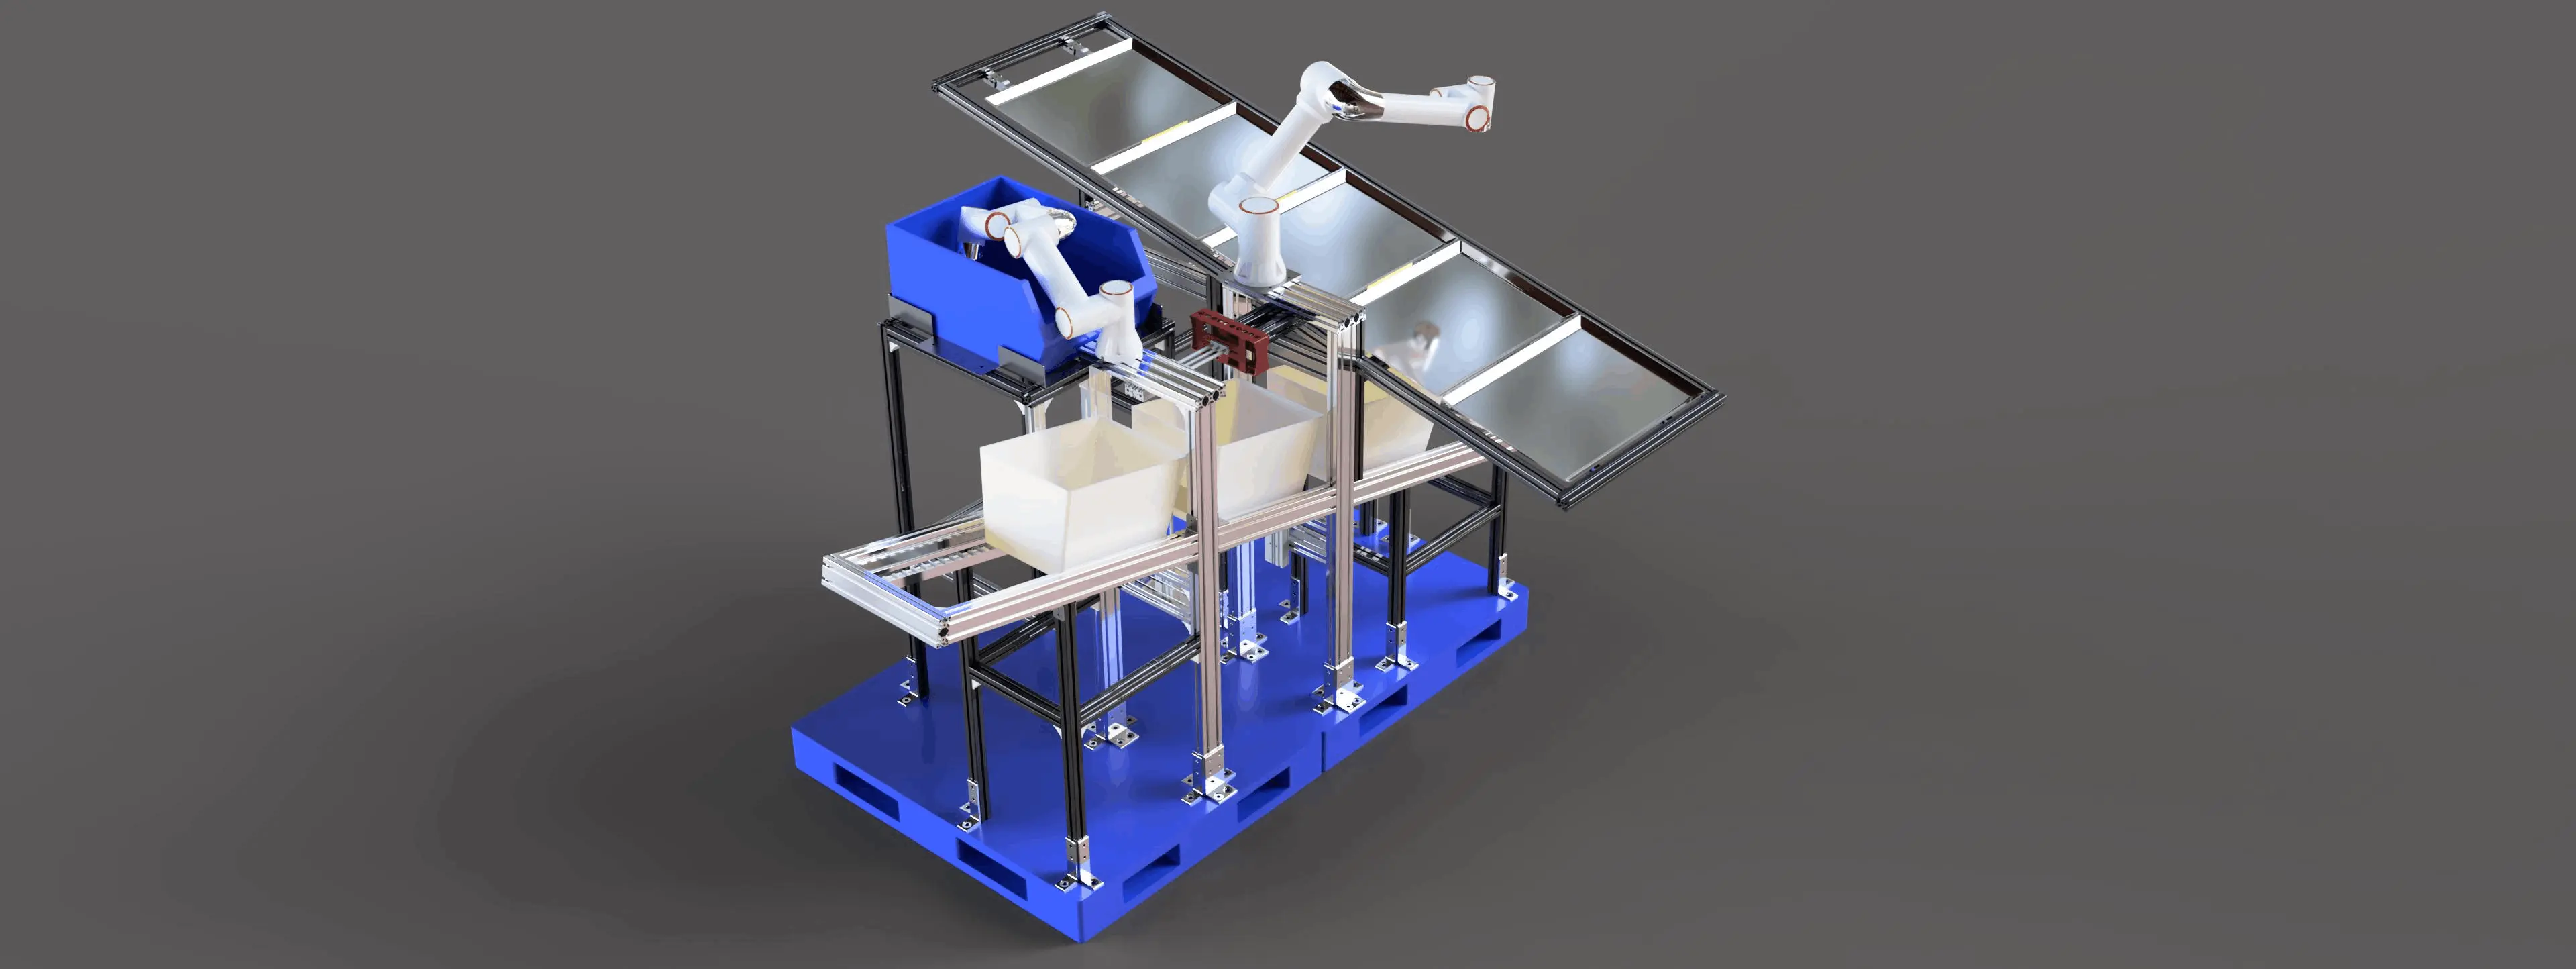
The Automated Egg-grading and palletizing system. This automated system uses pneumatic cylinders and suction cups for gentle, precise pick-and-place operation.
.jpg)
.jpg)
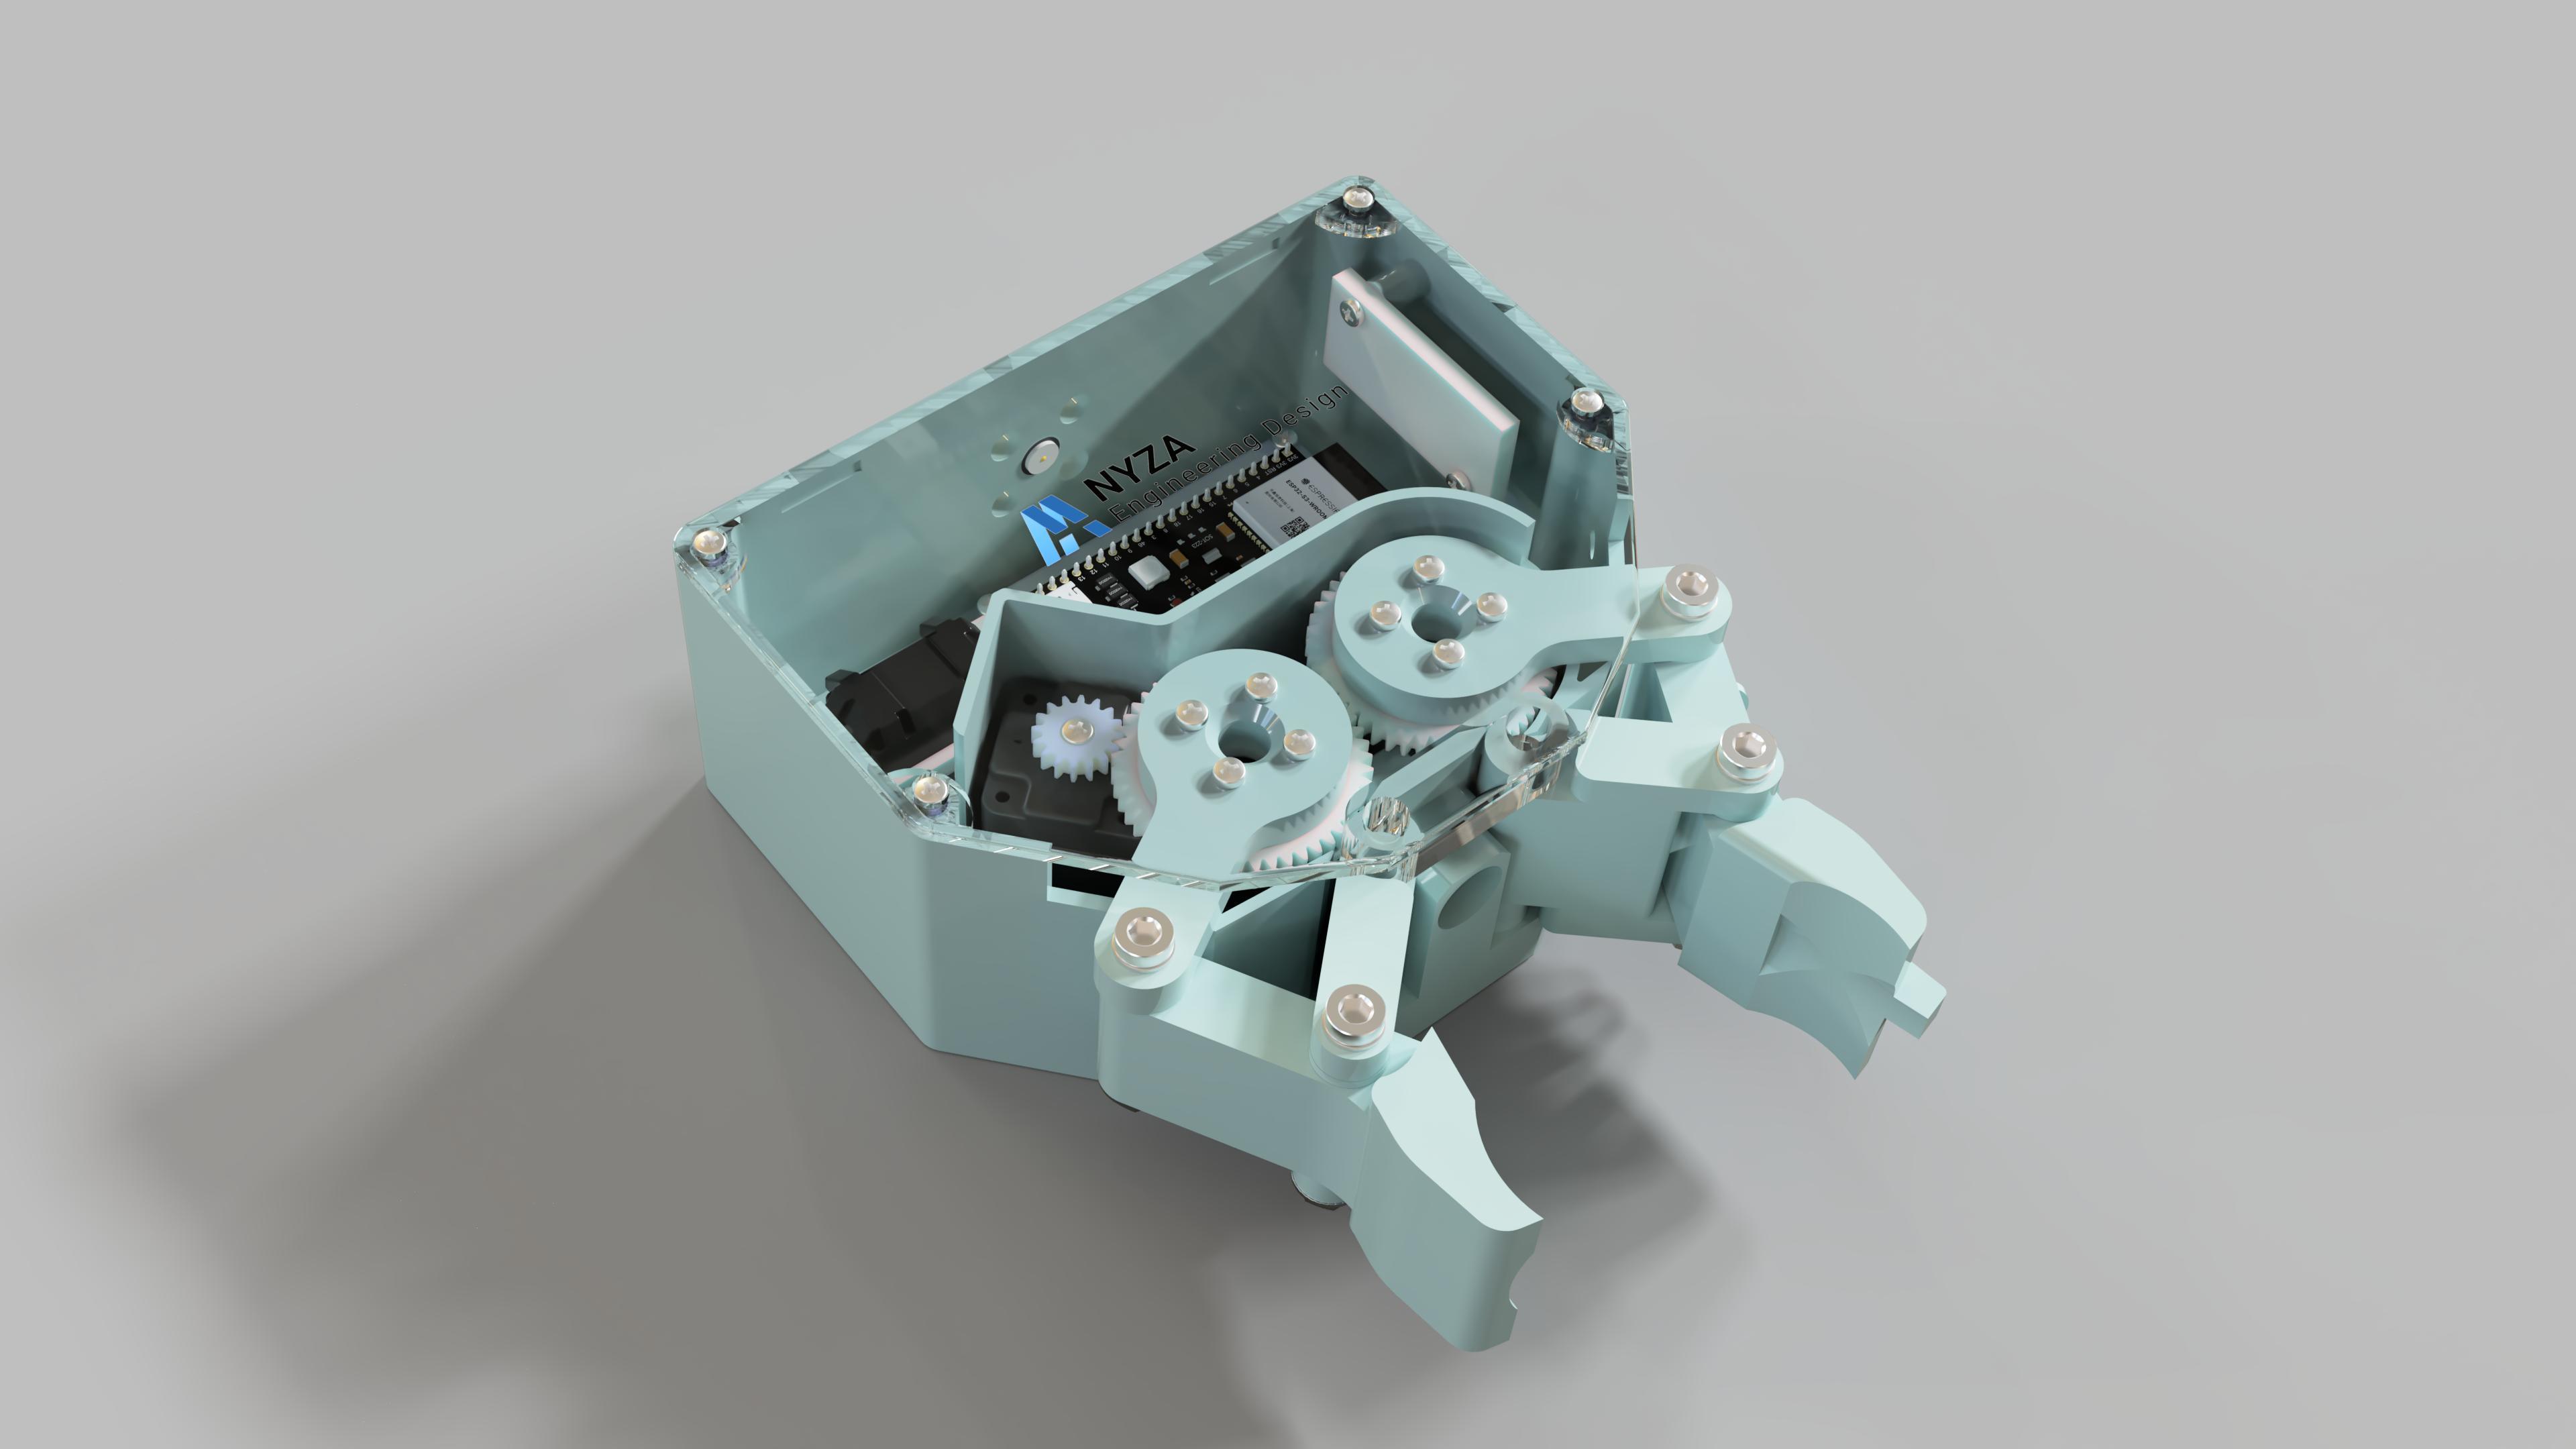
Mars Rover Gripper
Develop a lightweight, 3D-printable robotic gripper for a Mars rover. Design focuses on functionality and durability in the Martian environment, enabling sample collection and manipulation.
.jpg)
.png)
.png)
4 DOF ROBOTIC ARM
Developed a research prototype for a robotic arm featuring dual grippers. The innovative design integrates an extra gripper on an intermediate link, enabling improving cycle time.
.png)
.png)
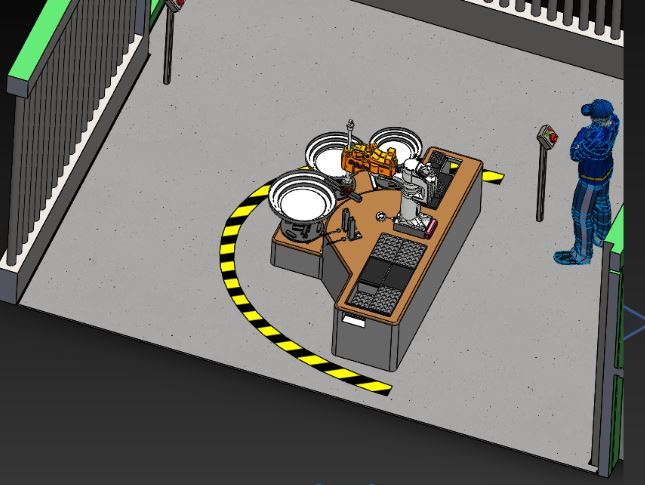
ROBOTIC CELL LAYOUT
This project proposes an automated assembly solution using a SCARA robot and several feeders within the robot’s reach to assemble a flashlight efficiently.
.jpg)
.jpg)
.jpg)
Autonomous Forklift
This project outlines the design and development of a semi-autonomous forklift for precise orientation and stacking of Euro pallets. The system is utilized to automate pallet handling tasks, improving efficiency and reducing potential damage.
.jpg)
.jpg)
.jpg)
Tire Mount
Designed and built a custom tire mount for a camper van using welding. This space-saving solution optimizes storage by securely mounting a spare tire within the van's interior.
.jpg)
.jpg)
.jpg)
CNC Migration