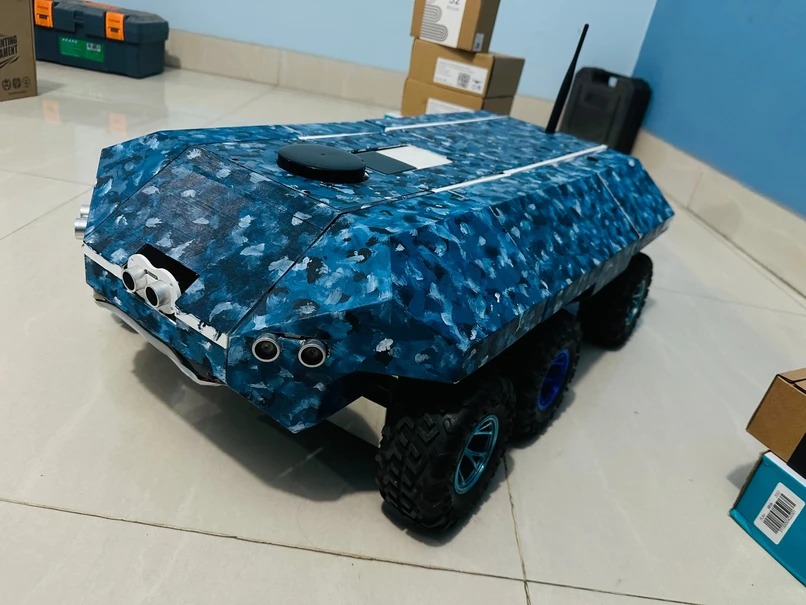
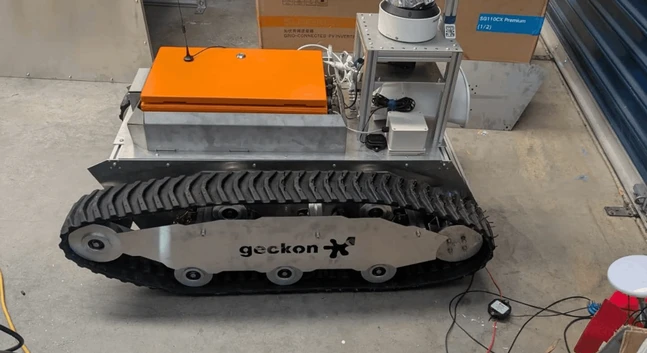
WHEEL TANK SURVEILLANCE ROVER
We designed and implemented a fully autonomous robot for sorting and transporting packages in a large-scale warehouse.
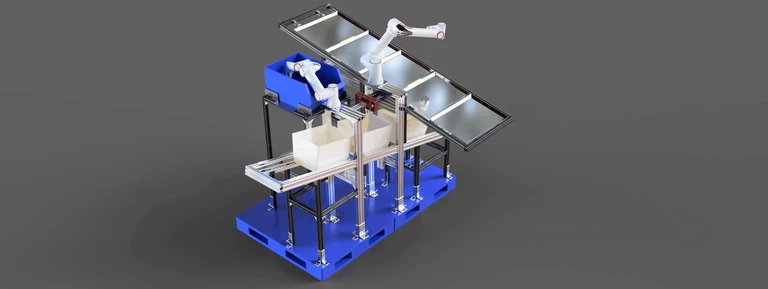
BLUE SKY ROBOTIC
A compact and precise robotic arm for assisting surgeons in delicate procedures, with a focus on sterile environments.
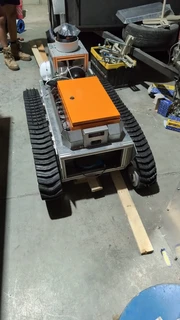
SURVEILLANCE ROBOT
A smart, self-flying drone capable of navigating complex urban environments to deliver packages safely and efficiently.
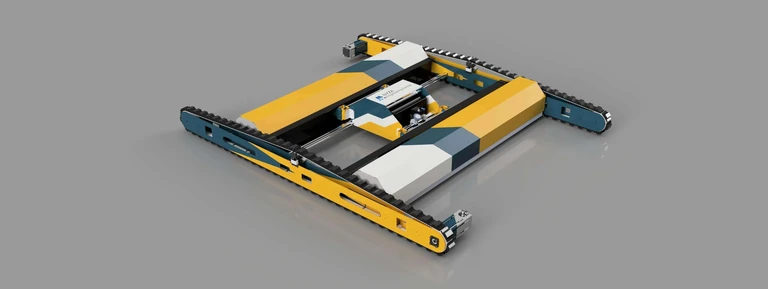
MINI PV ROBOT V2
An autonomous robot designed for monitoring crop health, precision planting, and targeted pesticide application.
.jpeg)
.jpeg)
.jpeg)
WIND SHOCK PROJECT
A rugged, remote-operated underwater vehicle for deep-sea exploration, equipped with high-resolution cameras and manipulators.
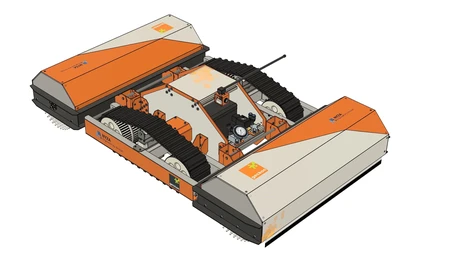
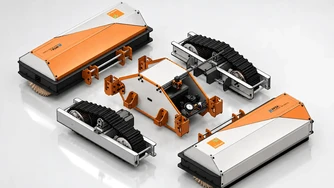
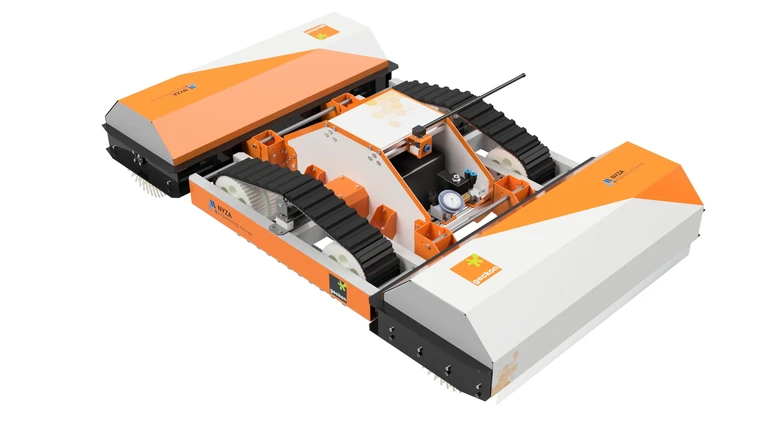
COMPACT PV CLEANING ROBOT
Develop a solar panel cleaning robot that is lightweight, modular, and easy to deploy. The robot should be divided into five modules, each weighing only 10kg, for convenient transportation and maintenance.
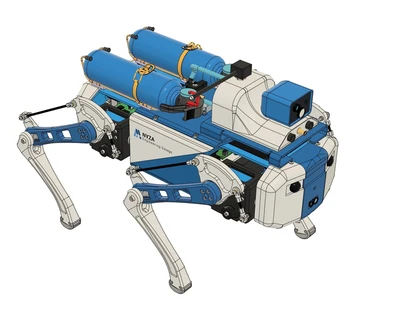
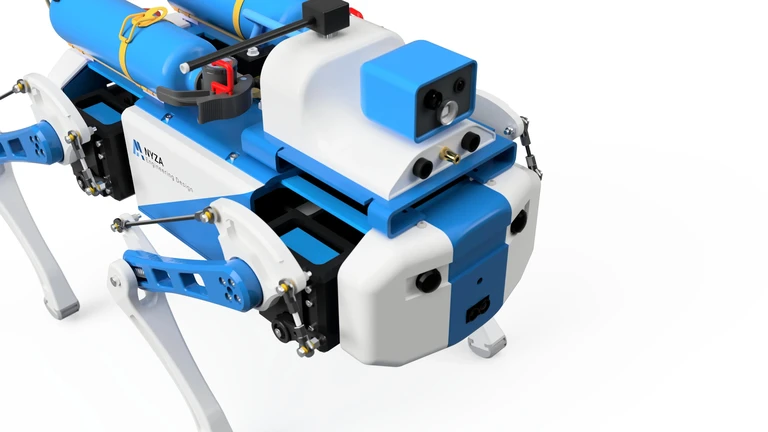
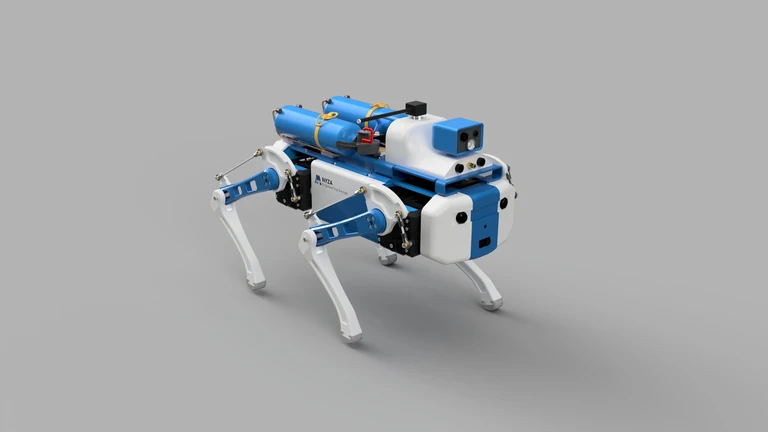
FIRE E POP ROBOT DOG
Design a quadruped robot capable of navigating tight spaces and extinguishing fires remotely. Fire E Pup should be maneuverable and equipped with a heat-resistant water cannon system and CO2 Extinguishers.
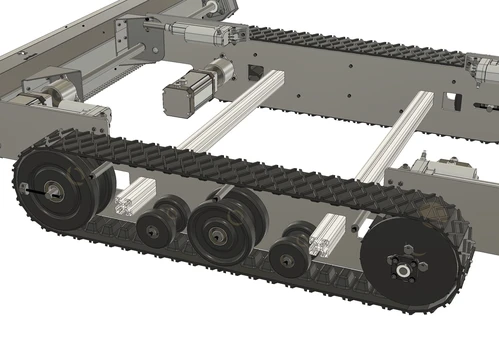
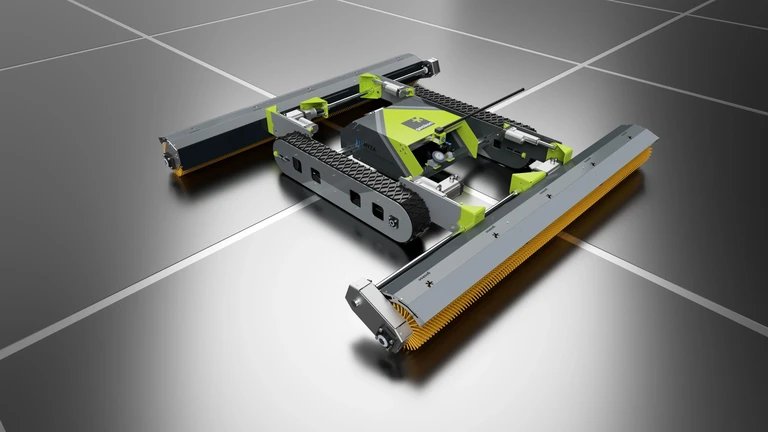
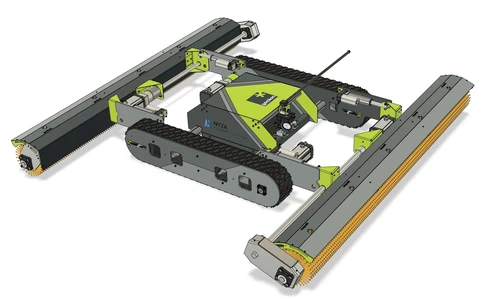
SOLAR PANEL CLEANING ROBOT
Designed a mobile robot with all the requirements given by the client and made a lot of modifications based on my experience with robots. All custom parts were built with design for manufacturing considerations.
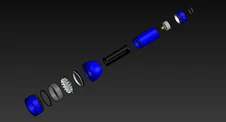
ROBOTIC CELL LAYOUT
This project proposes an automated assembly solution using a SCARA robot and several feeders within the robot’s reach to assemble a flashlight efficiently.
EGG GRADING SYSTEM
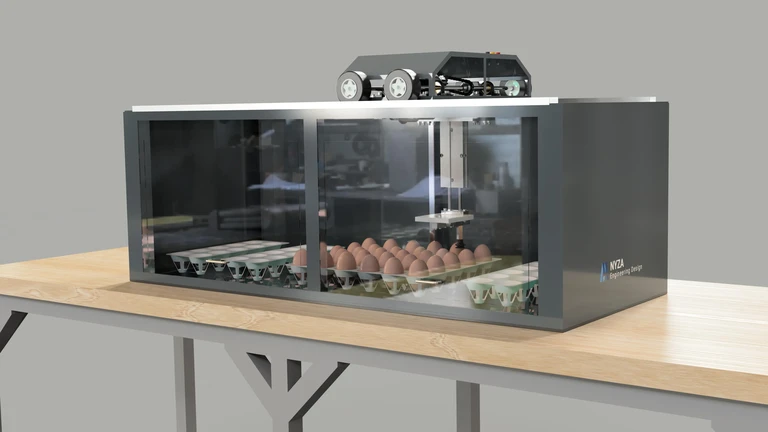
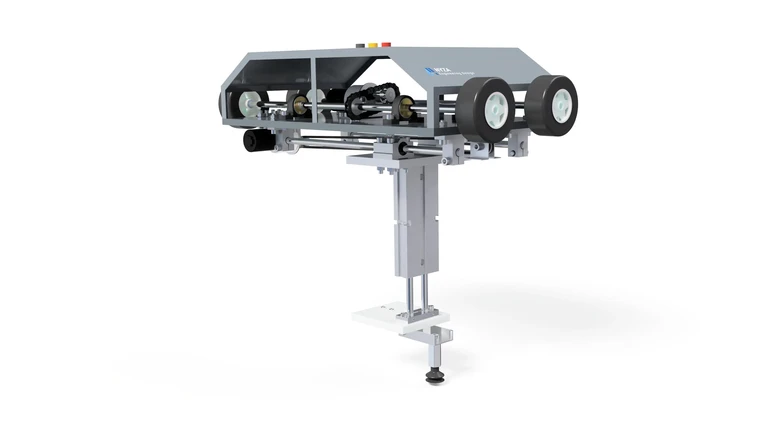
The Automated Egg-grading and palletizing system. This automated system uses pneumatic cylinders and suction cups for gentle, precise pick-and-place operation.
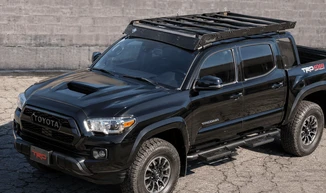
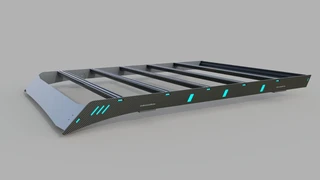
Electric SUV Actuated Roof Rack
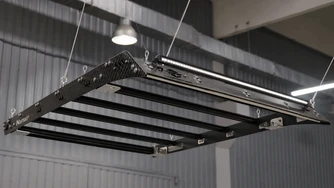
Motorized sliding structural roof rack engineered for aerodynamic performance, featuring integrated limit switches and detailed FEA dynamic load ratings.
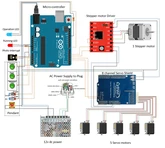
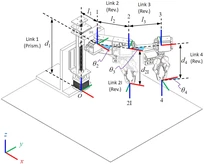
4 DOF ROBOTIC ARM
Developed a research prototype for a robotic arm featuring dual grippers. The innovative design integrates an extra gripper on an intermediate link, enabling improving cycle time.